Resources

Search

By Topic:

Topics box filter
  • Cognitive Intelligence
  • Data-Driven AI Models for Physical Robot Interaction
  • Athletic Intelligence
  • Advanced Learning for Control
  • Company News
  • Ethics & Impact
  • Dexterous Manipulation
  • Navigation in Challenging Environments
  • Trends in Robotics
  • Organic Design
  • Employee Spotlight

By Type:

Type checkbox filter - Resources
  • Paper
  • Blog
  • Video
  • Workshop

CoRL 2026 Publication and Workshop Round Up

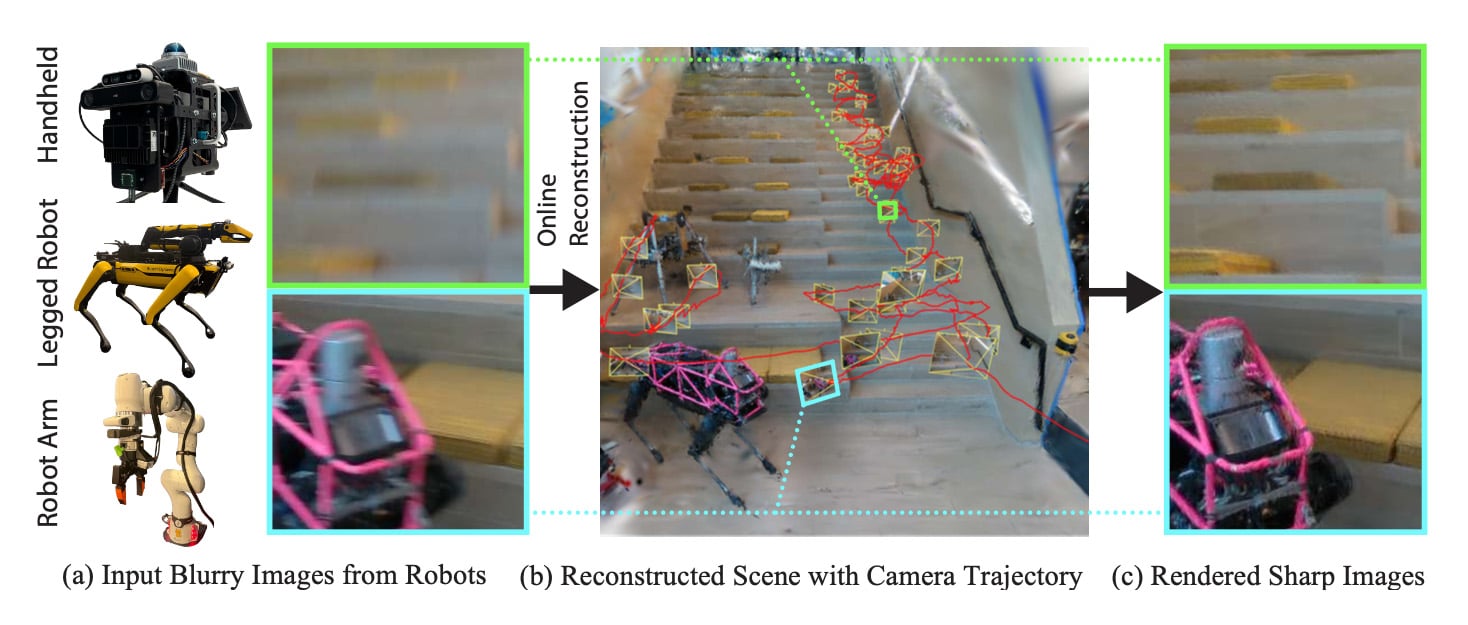
Research teams at the RAI Institute had several papers and workshops accepted for CoRL 2026, covering topics such as handheld data collection, loco-manipulation, robot mapping...
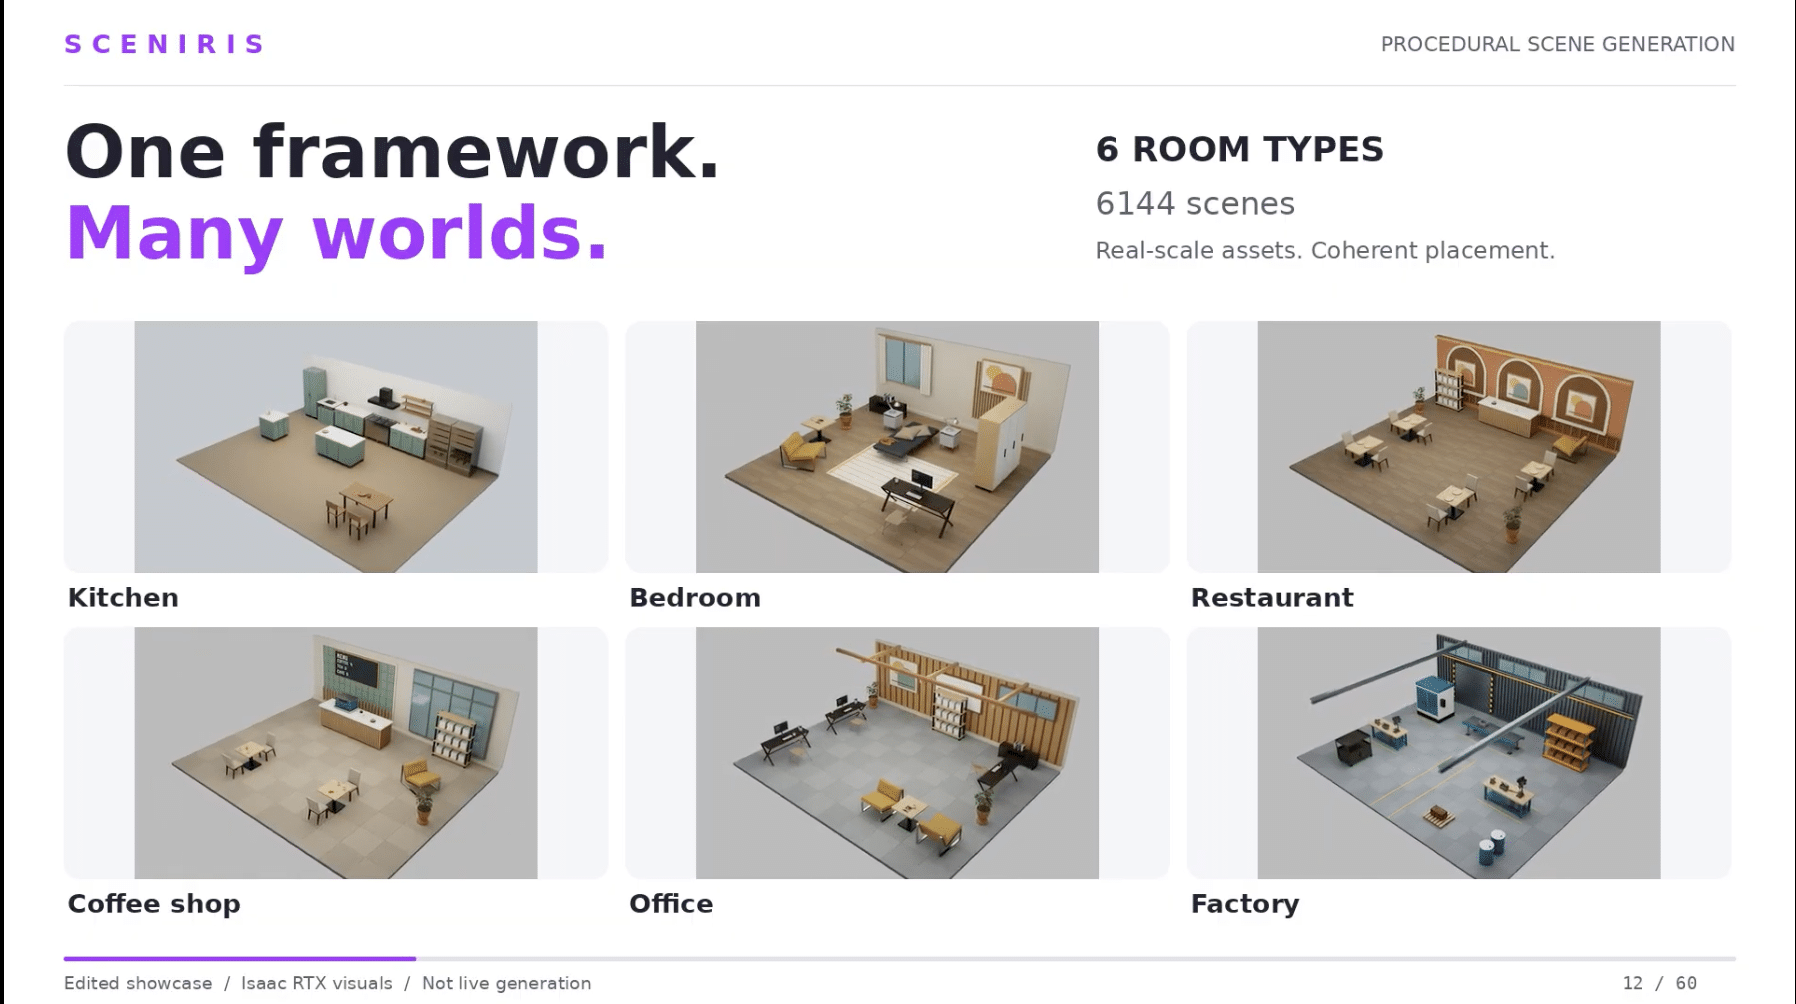
Sceniris: A Fast Procedural Scene Generation Framework

We introduce Sceniris, a highly efficient procedural scene generation framework for rapidly generating large-scale, collision-free scene variations.

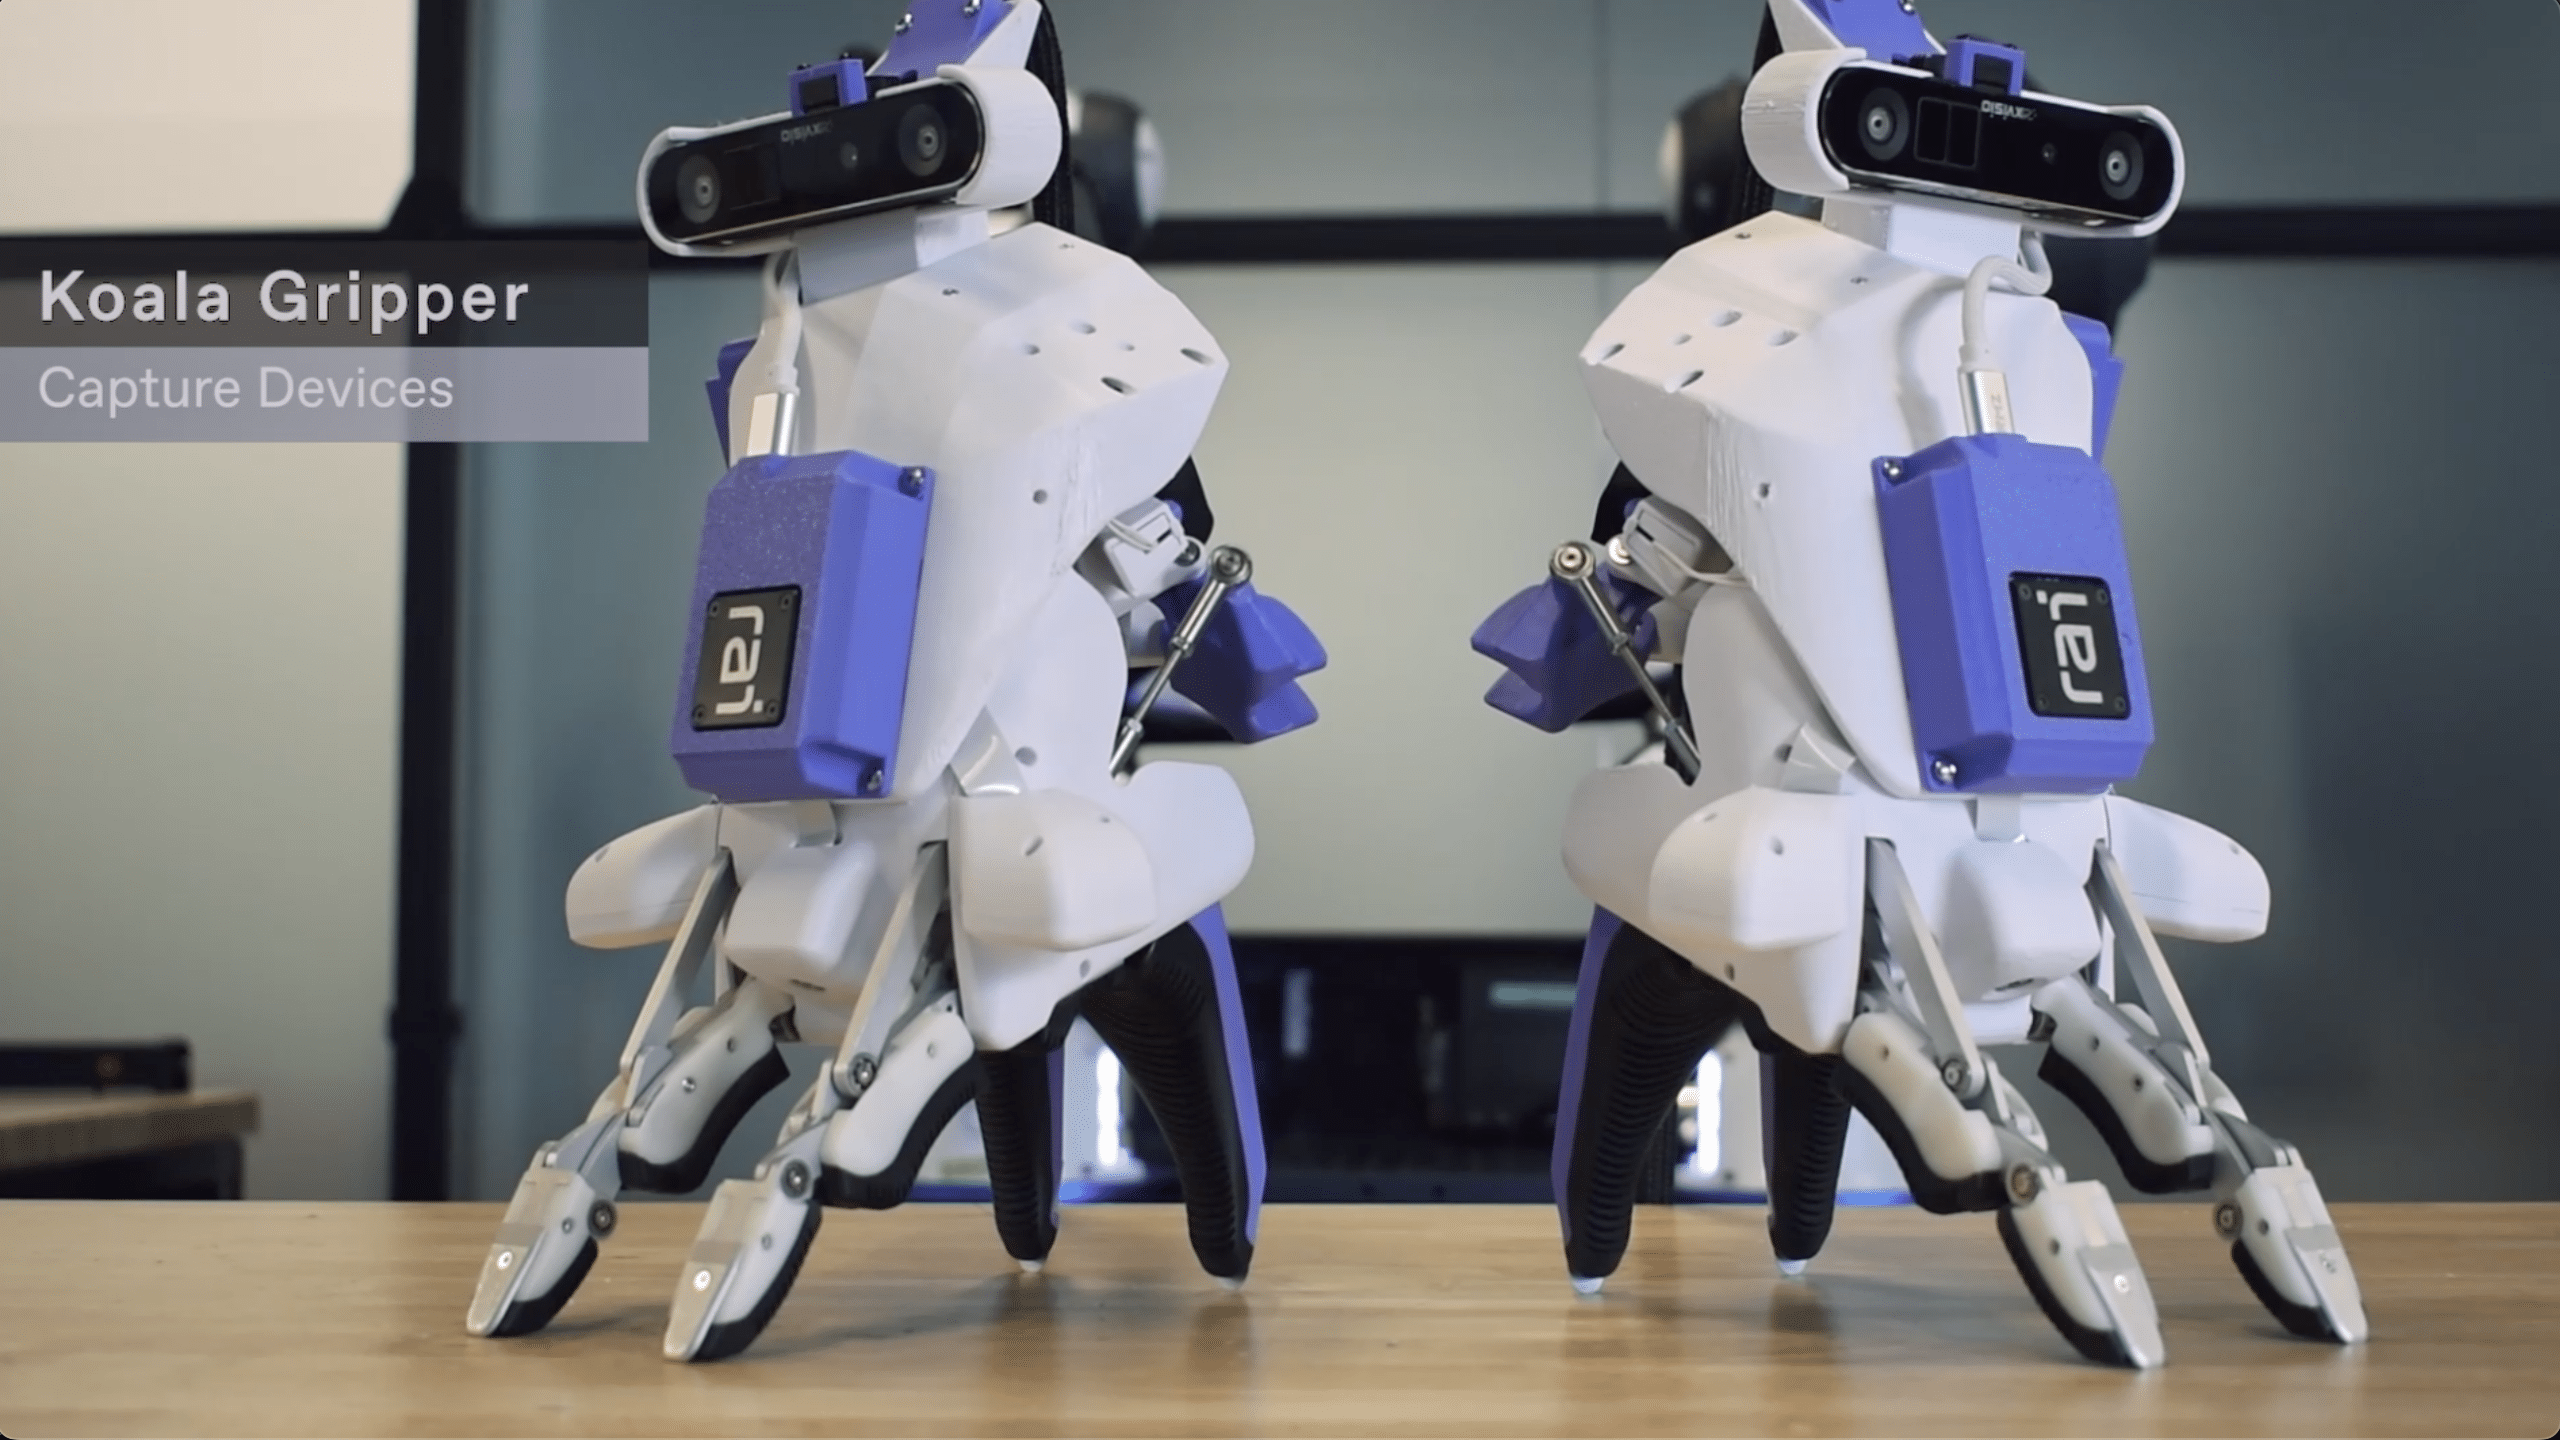
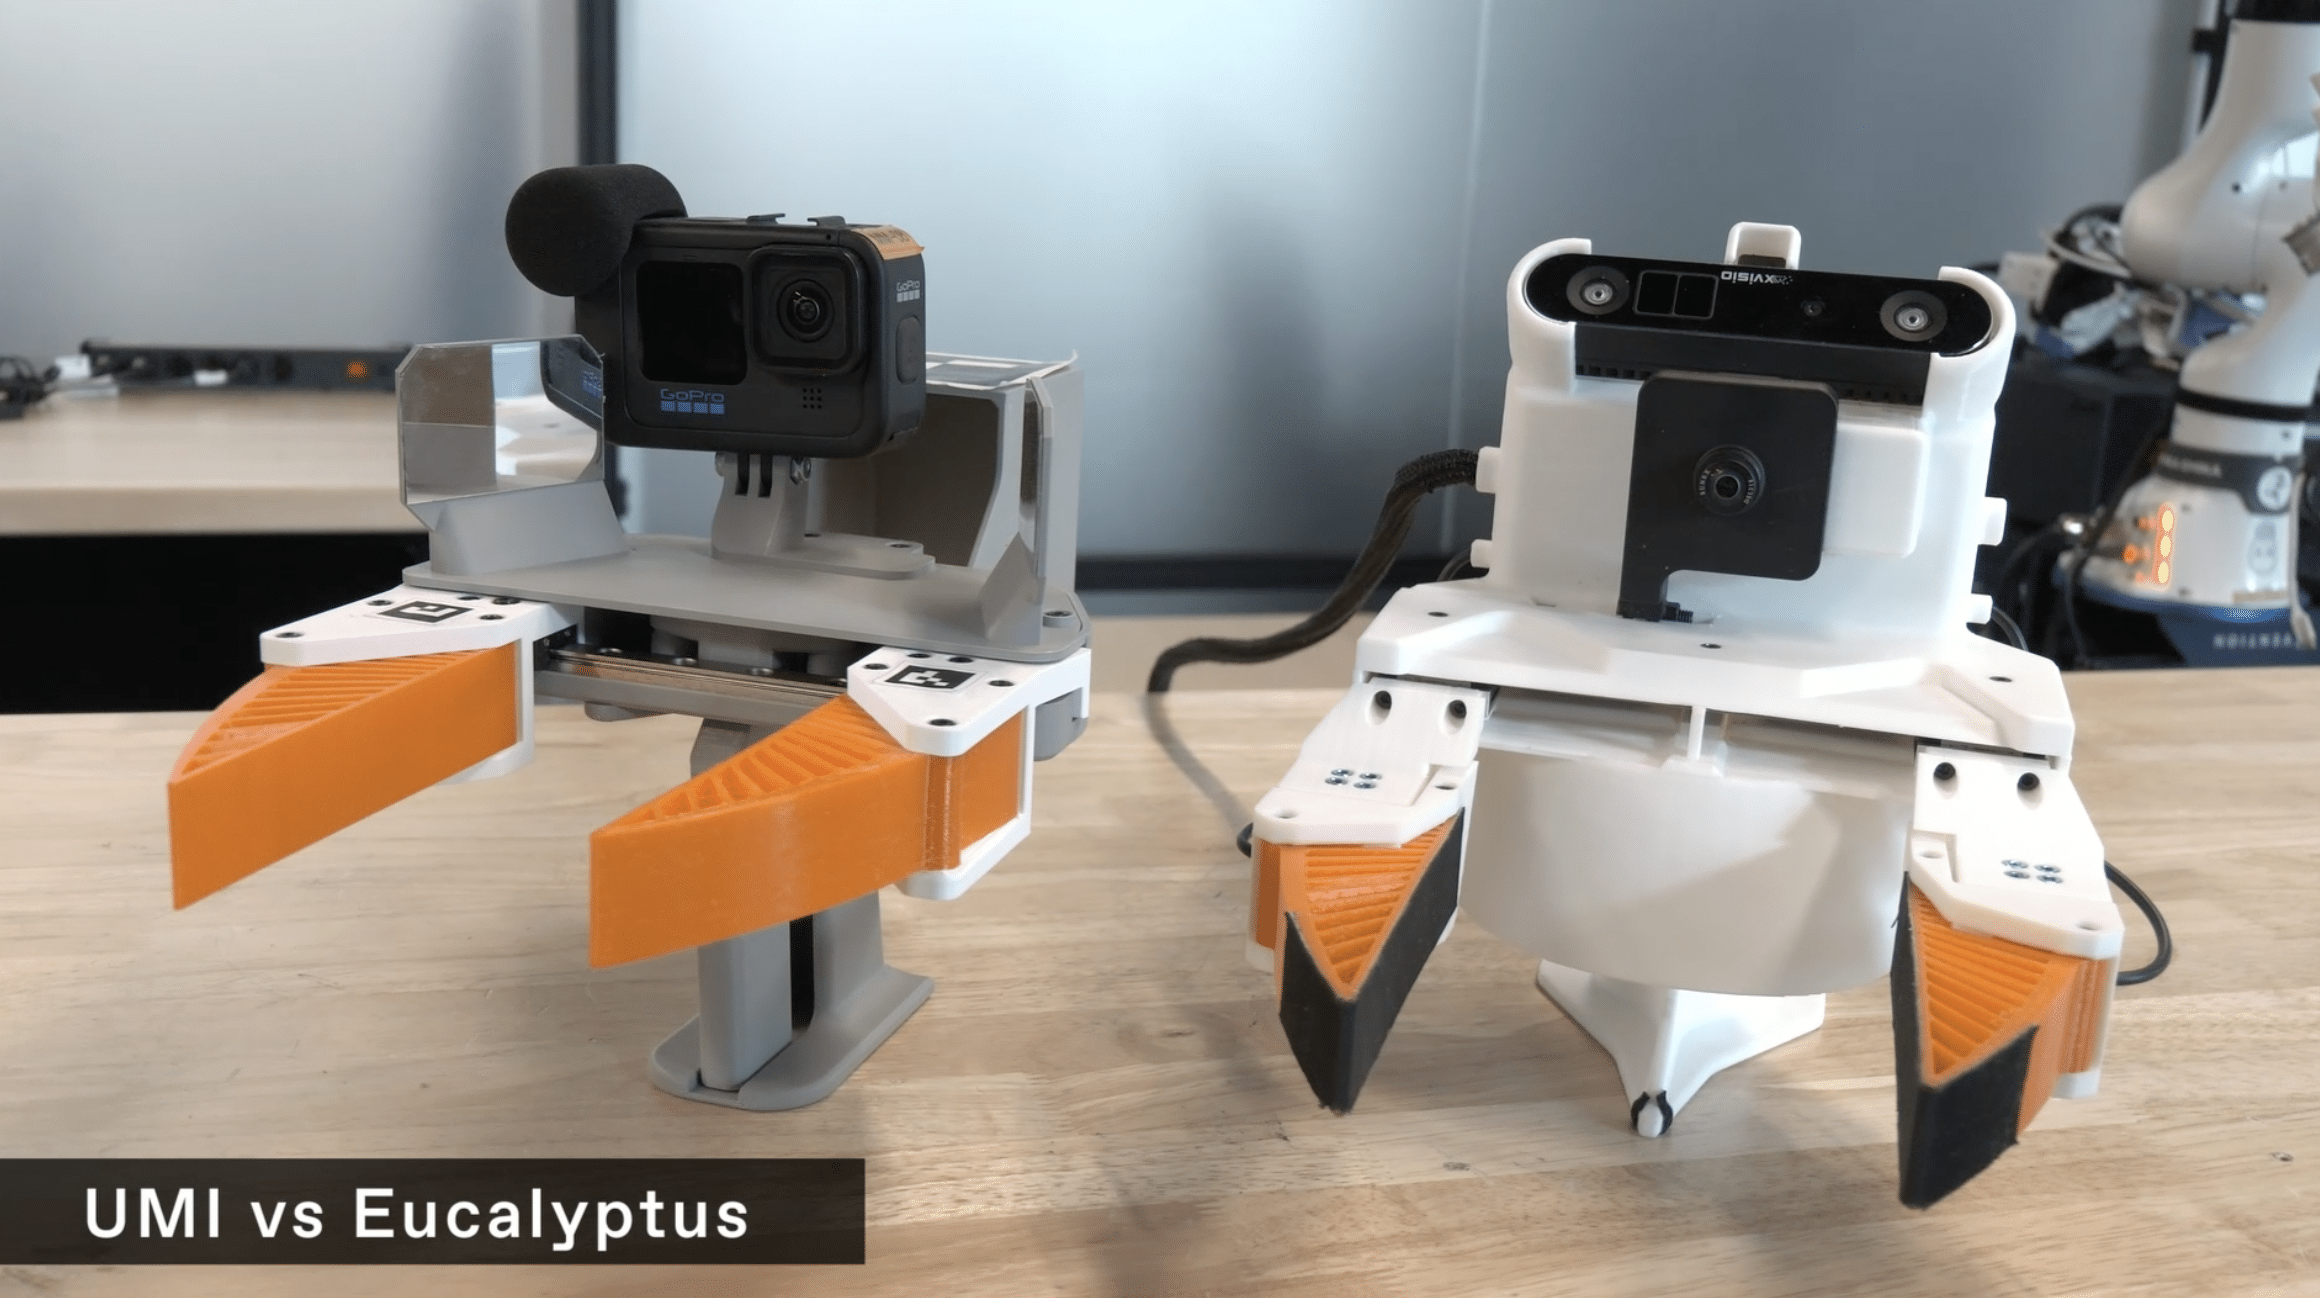
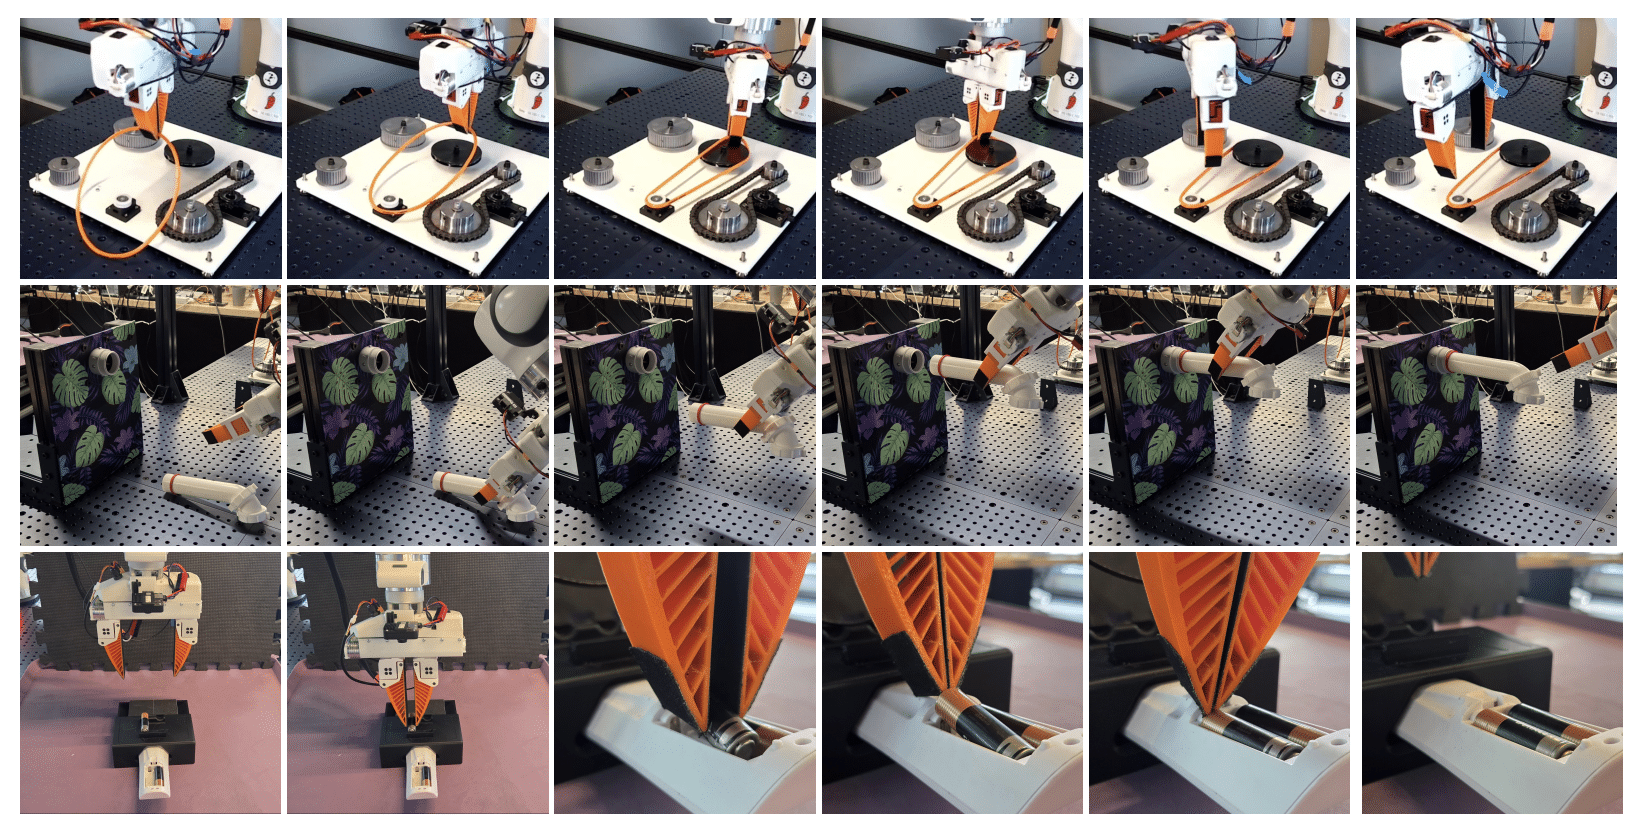
Eucalyptus: A High-Fidelity Multimodal UMI

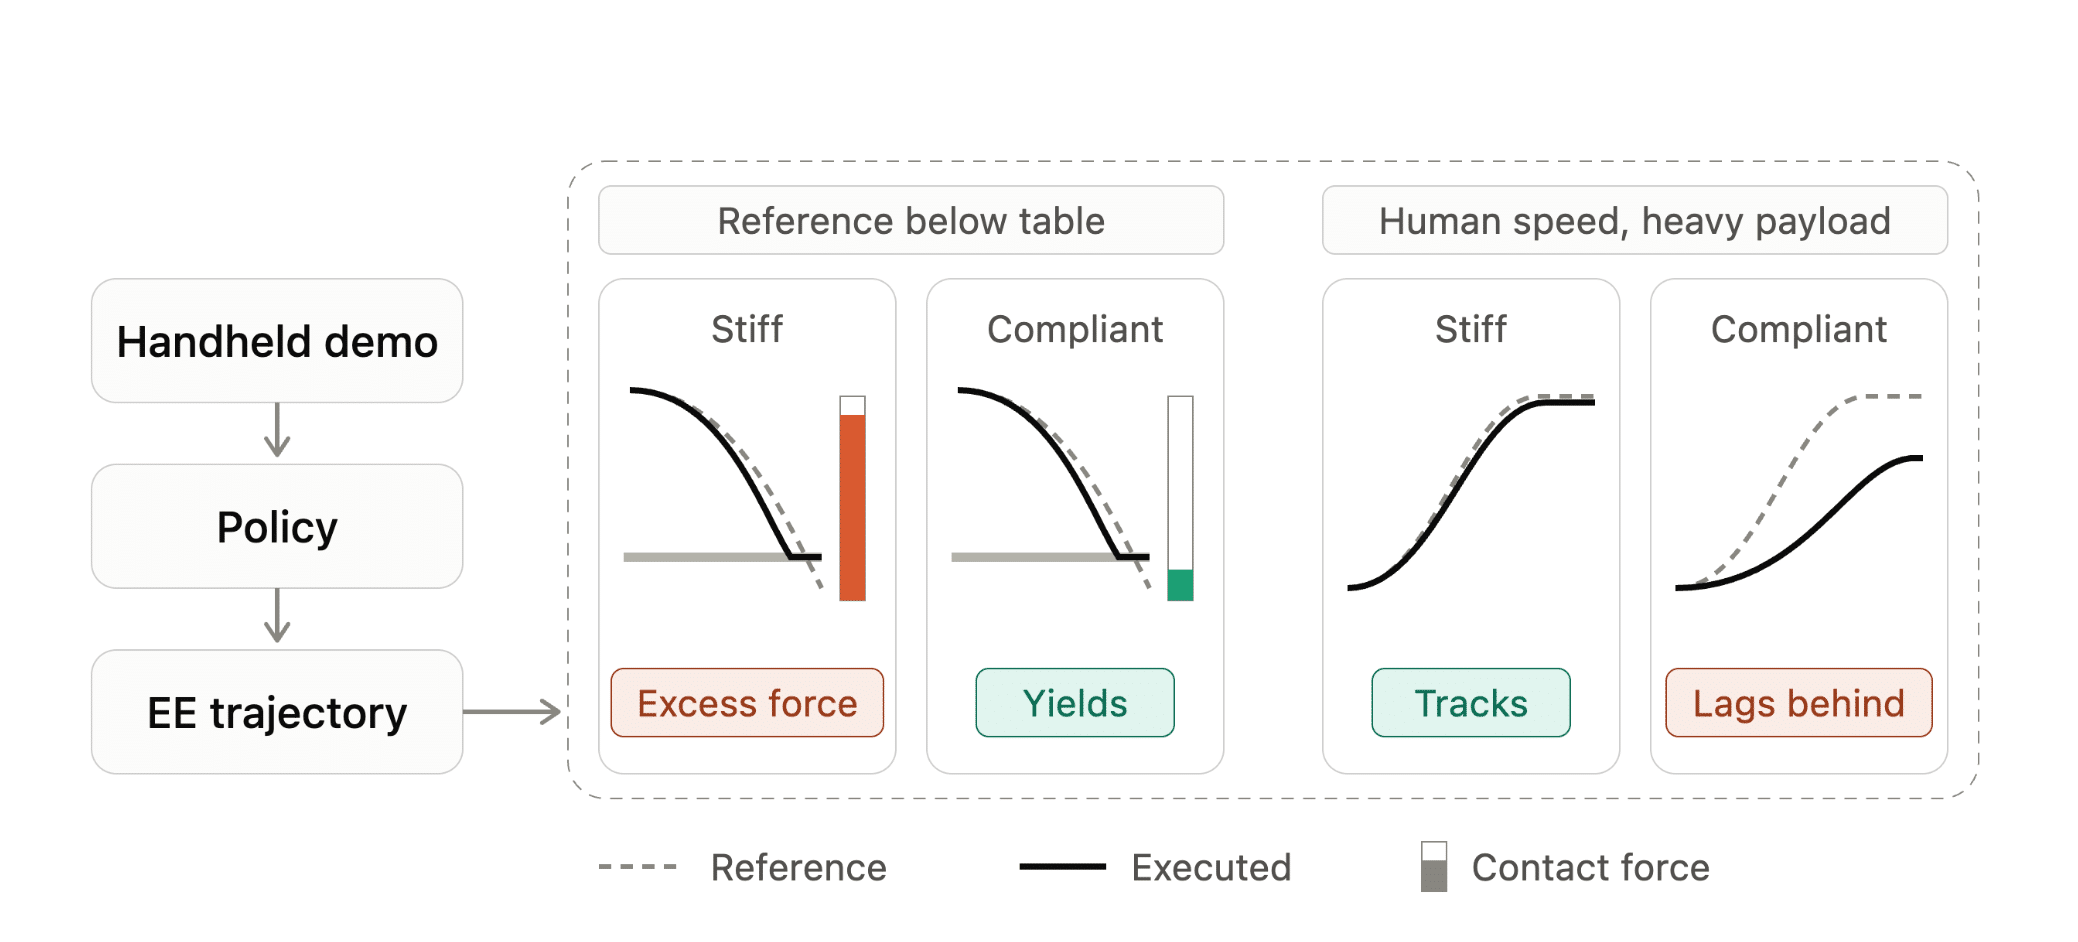
We present Eucalyptus, an extension of UMI designed for sustained, force-aware data collection. Eucalyptus combines a robustified and ergonomics-oriented mechanical design with a high-fidelity multimodal...

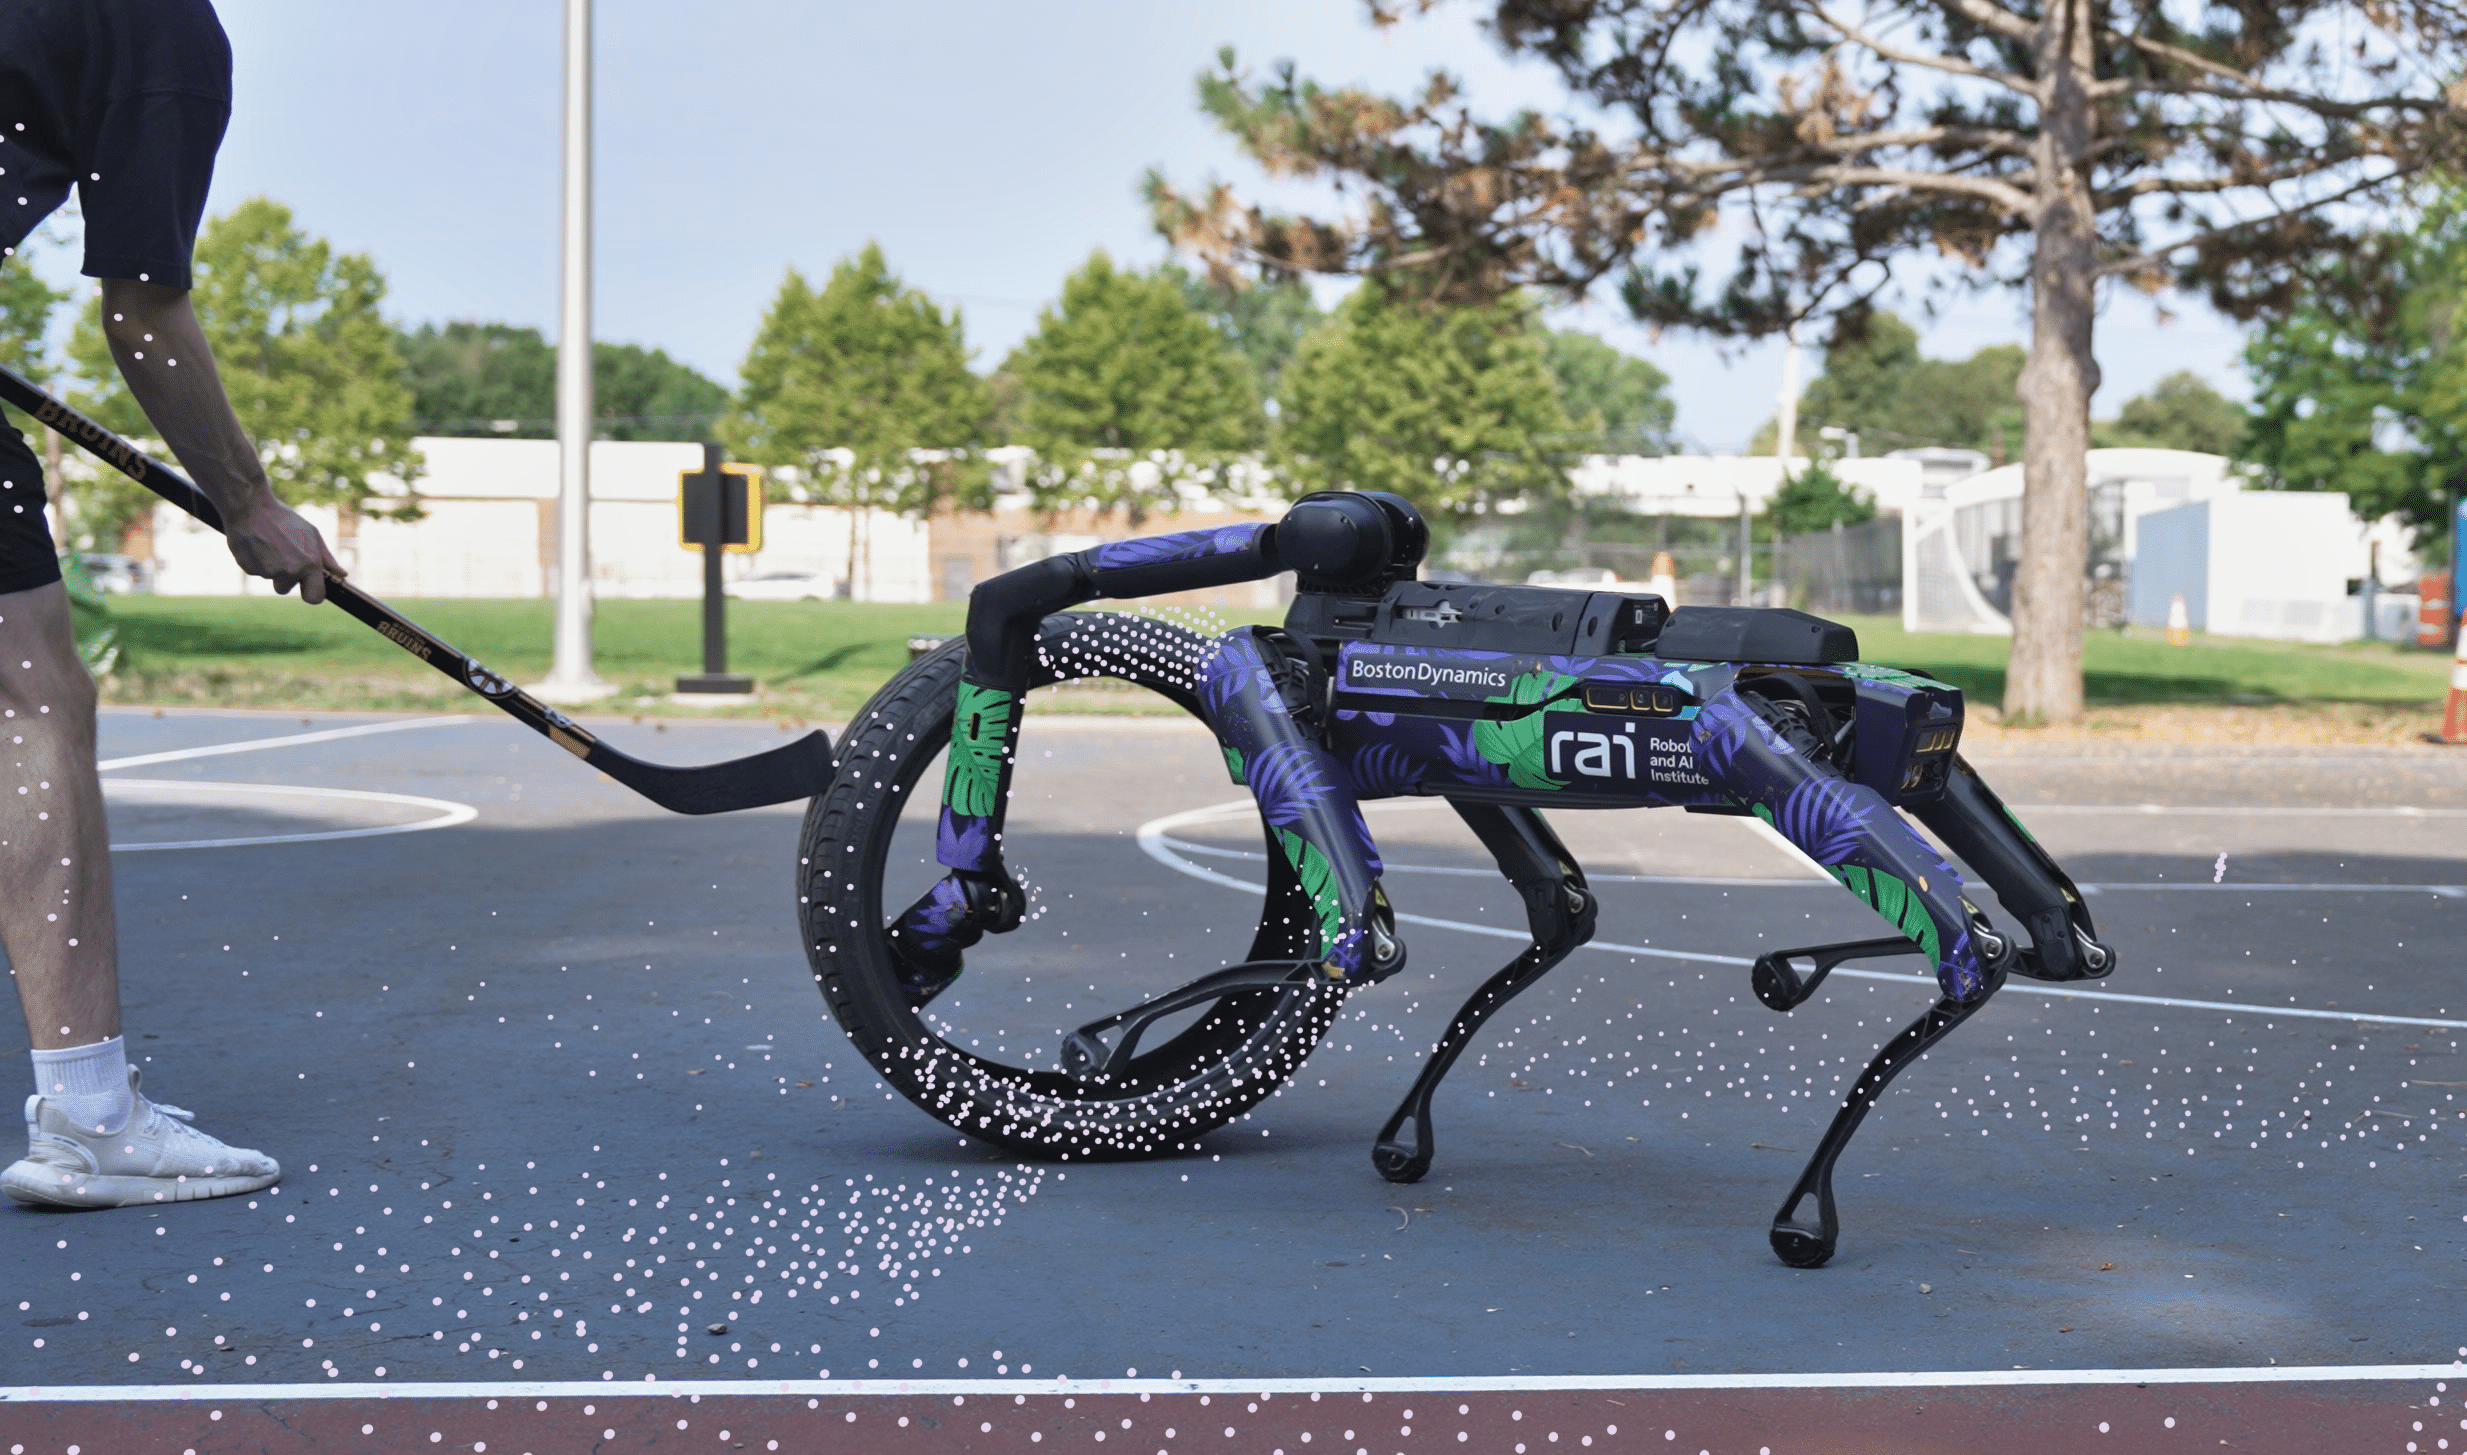
Perceptive Dynamic Manipulation with Spot

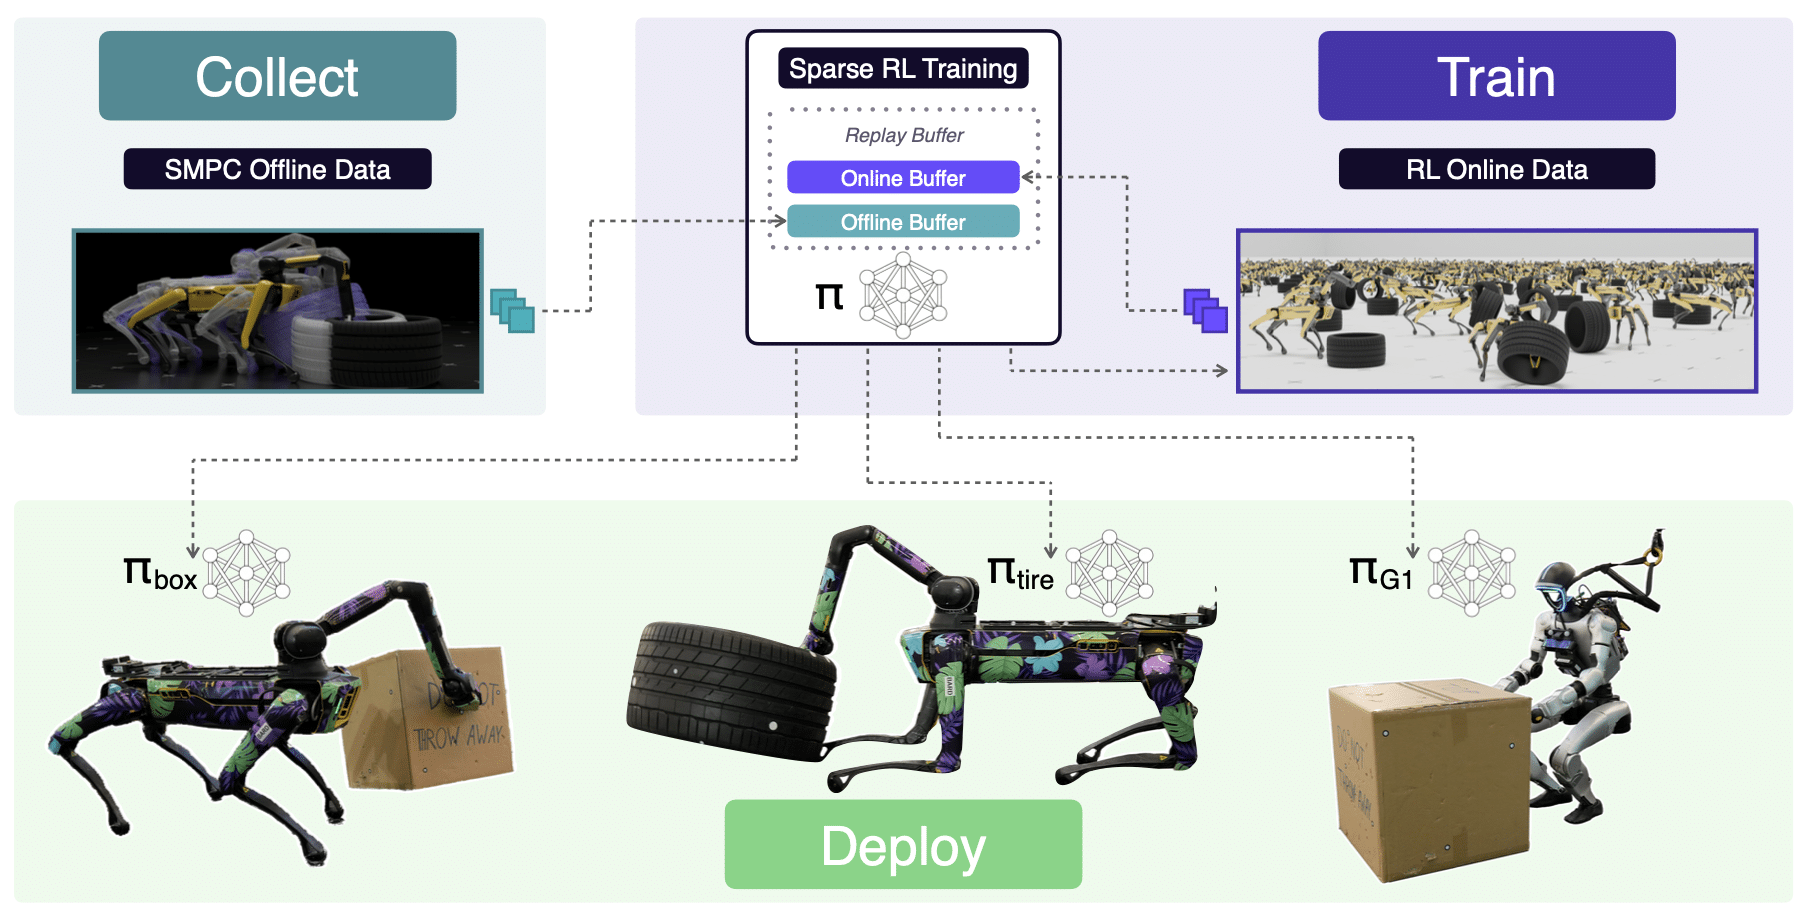
By replacing external motion capture with onboard depth-camera perception and local policy evaluation, we can achieved full autonomy and untethered outdoor execution to perceive, locate,...

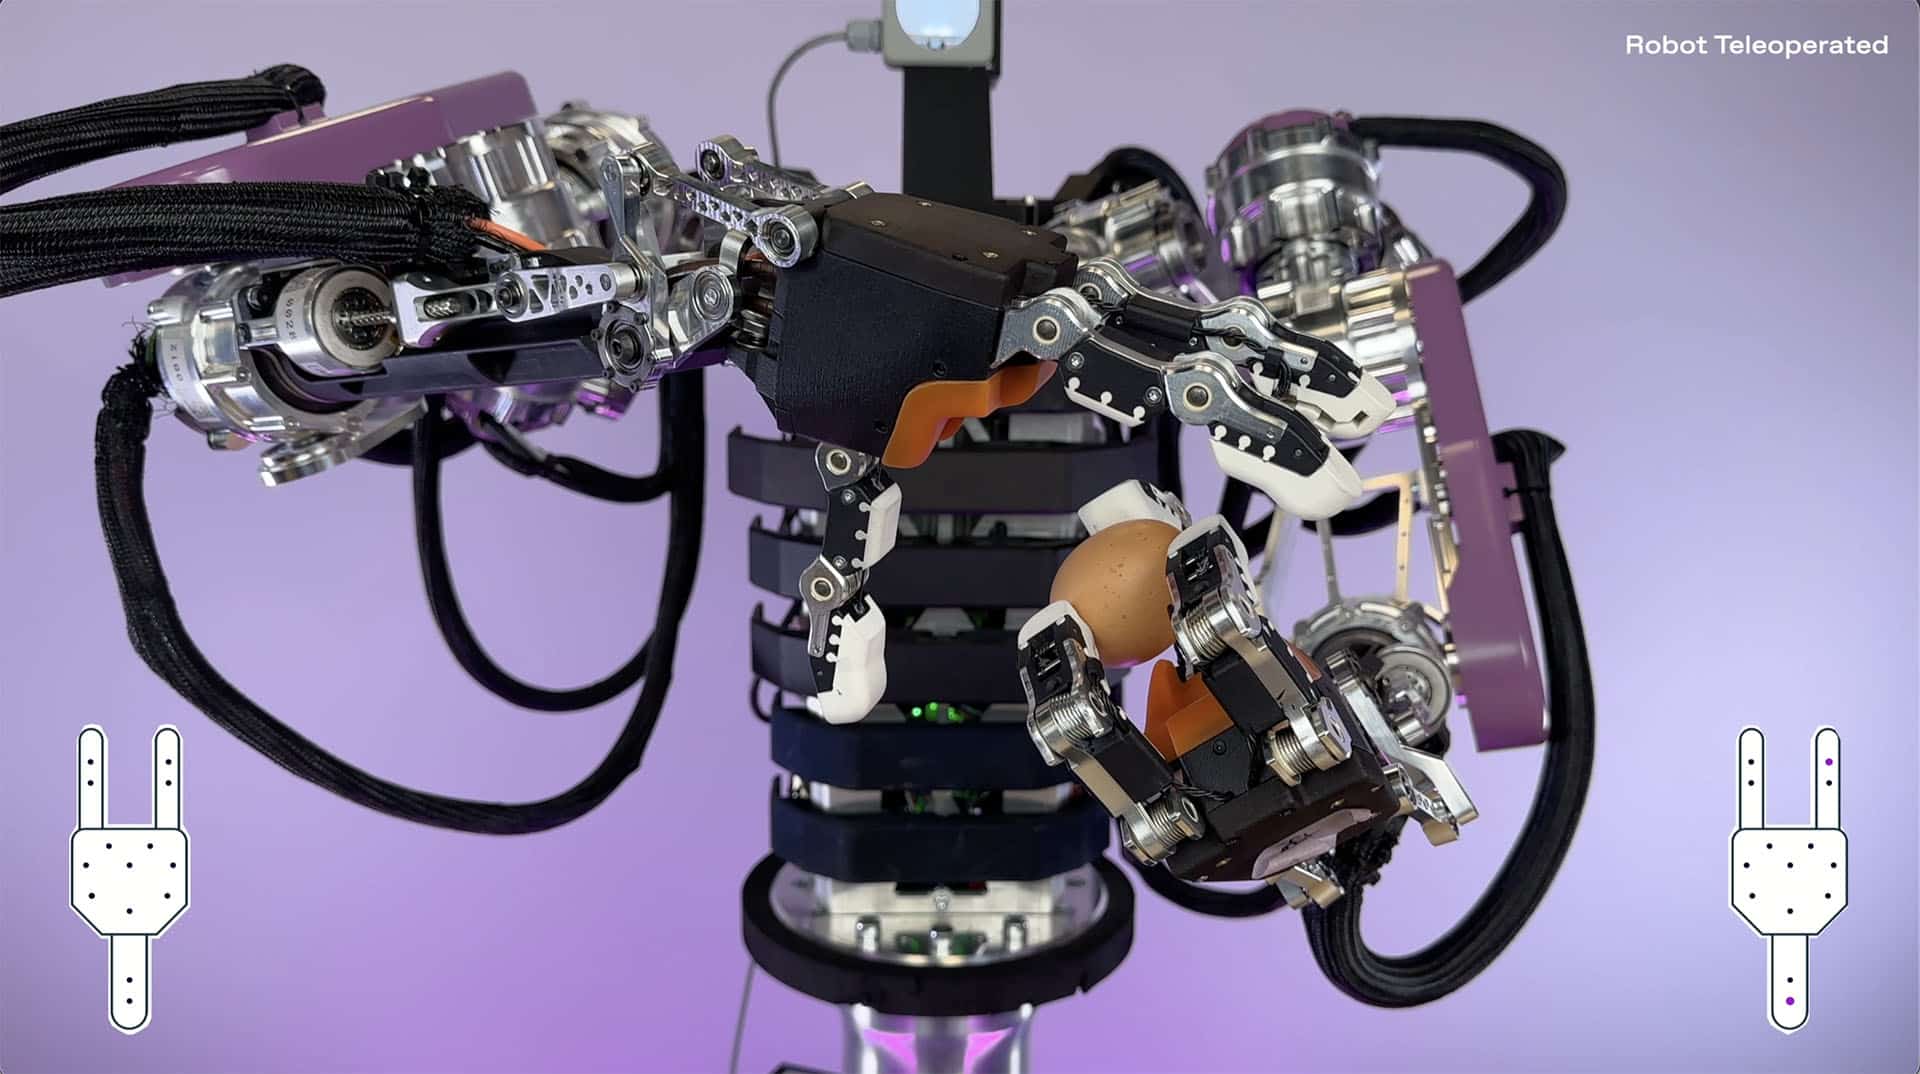
Hardware Spotlight: AthenaZero Tactile Sensing

To perform tasks that require forceful manipulation and delicacy with a single robot design requires not only a powerful robot but also smart control. Providing...