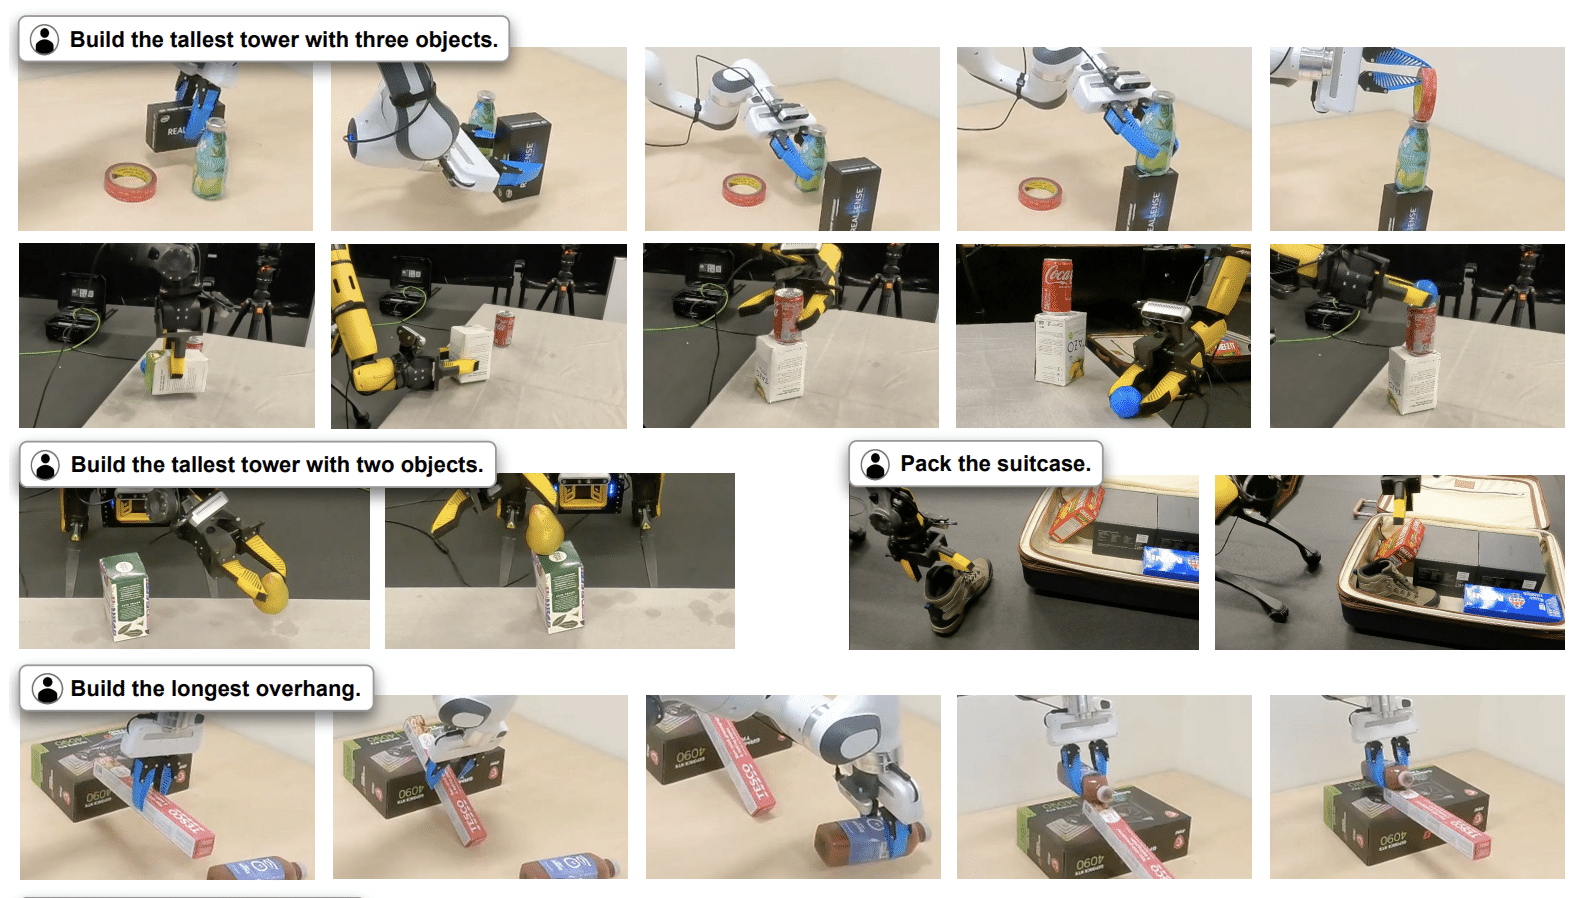
We introduce Simify, a training-free, test-time framework that performs explicit spatial reasoning via massively parallel physics simulation.
Resources
By Topic:
By Type:
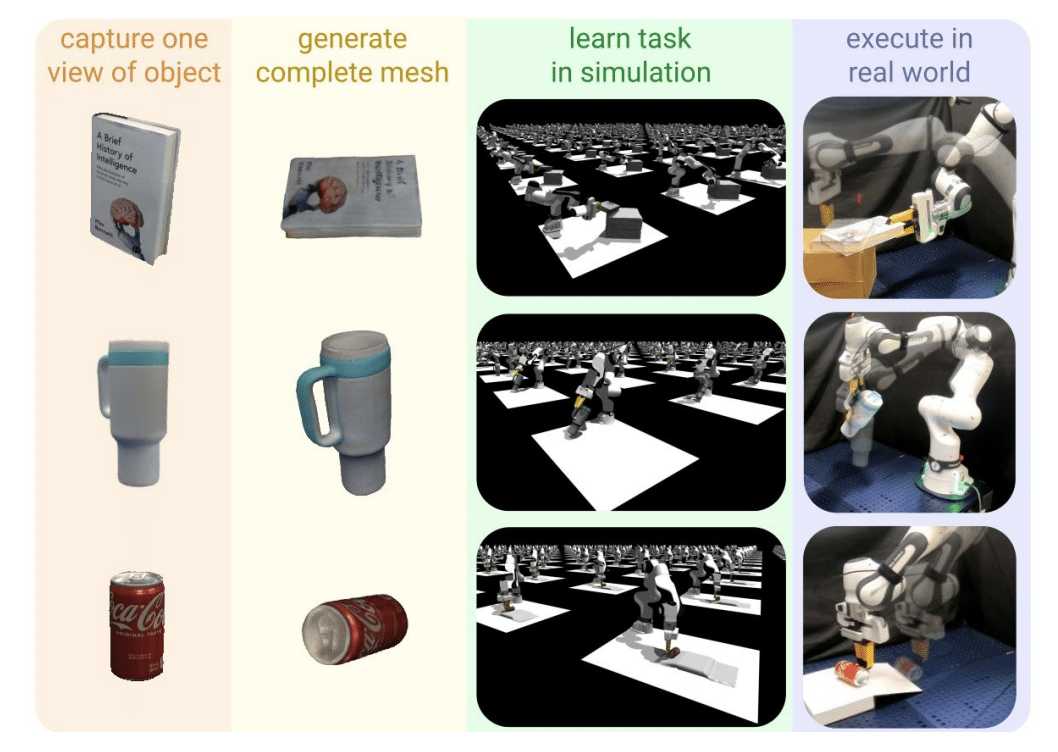
ZeroBot: Learning from Scratch in Minutes with Generative Real2Sim
We present ZeroBot, a real2sim framework for learning a robot manipulation task from scratch in minutes under challenging conditions: zero human demonstrations, zero policy pre-training,...
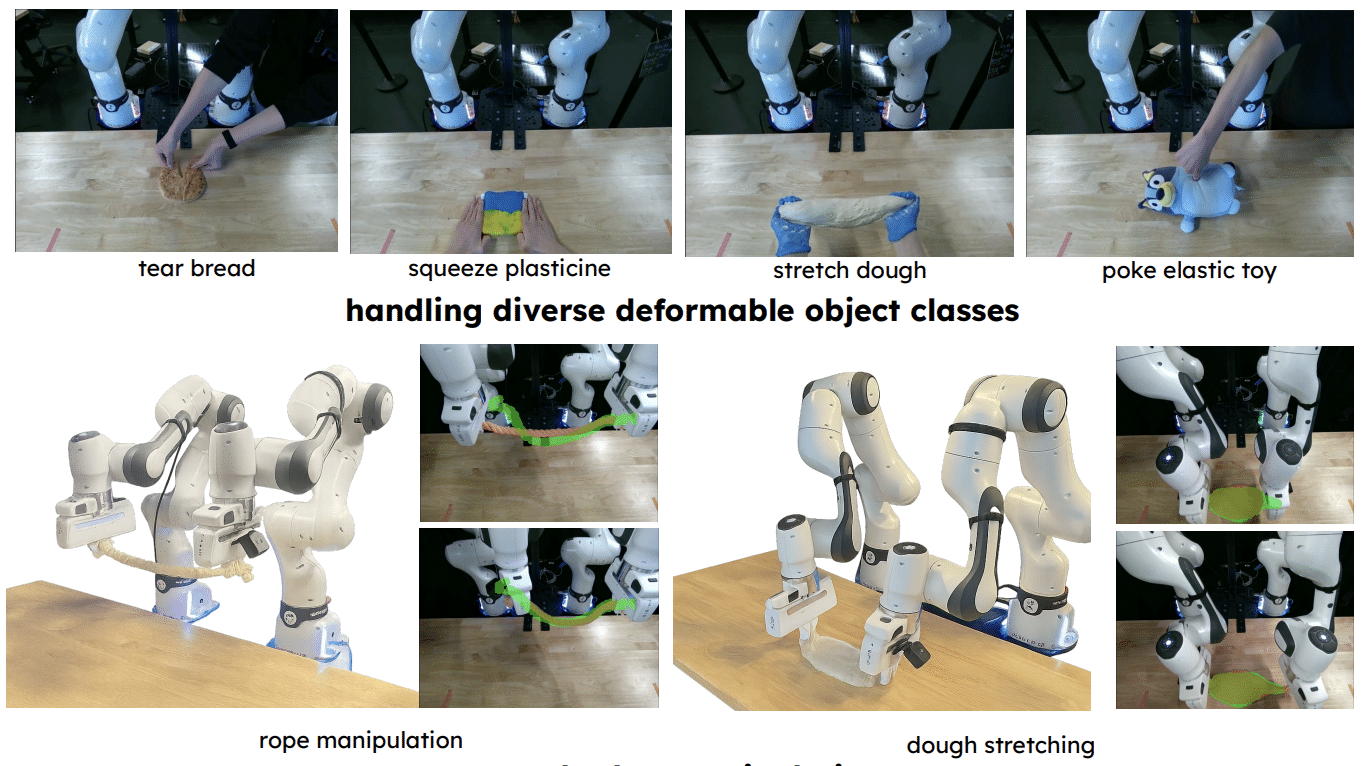
EMPM: Embodied MPM for Modeling and Simulation ofDeformable Objects
We introduce embodied MPM (EMPM), a deformable object modeling and simulation framework built on a differentiable Material Point Method (MPM) simulator that captures the dynamics...
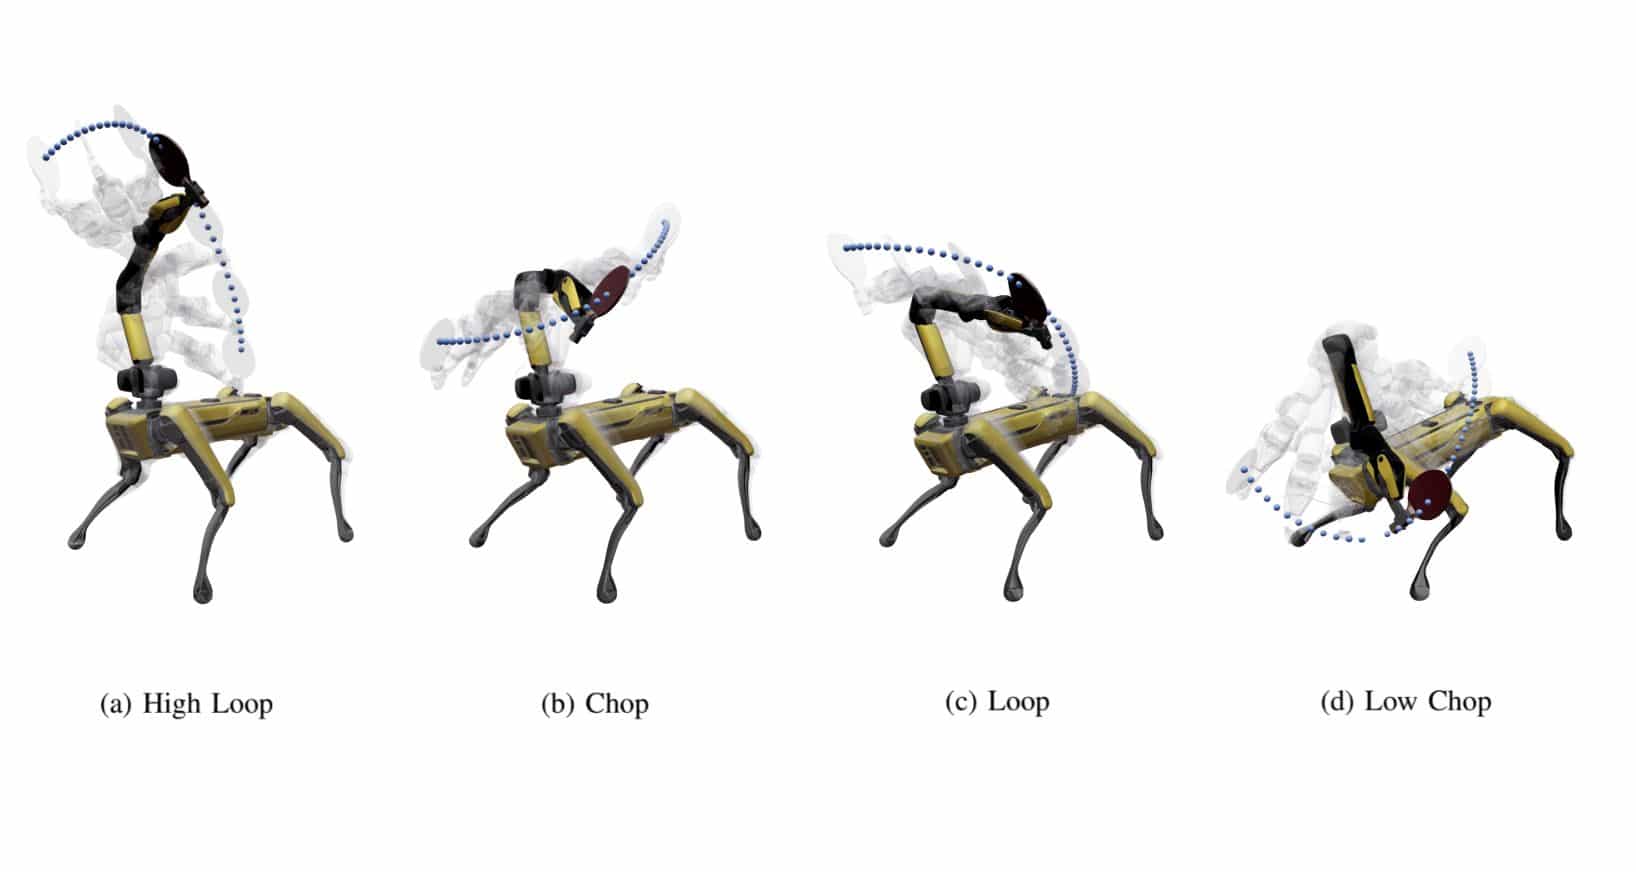
Whole-Body Model Predictive Control for Spin-Aware Quadrupedal Table Tennis
Developing table tennis robots that mirror human speed, accuracy, and ability to predict and respond to the full range of ball spins remains a significant...
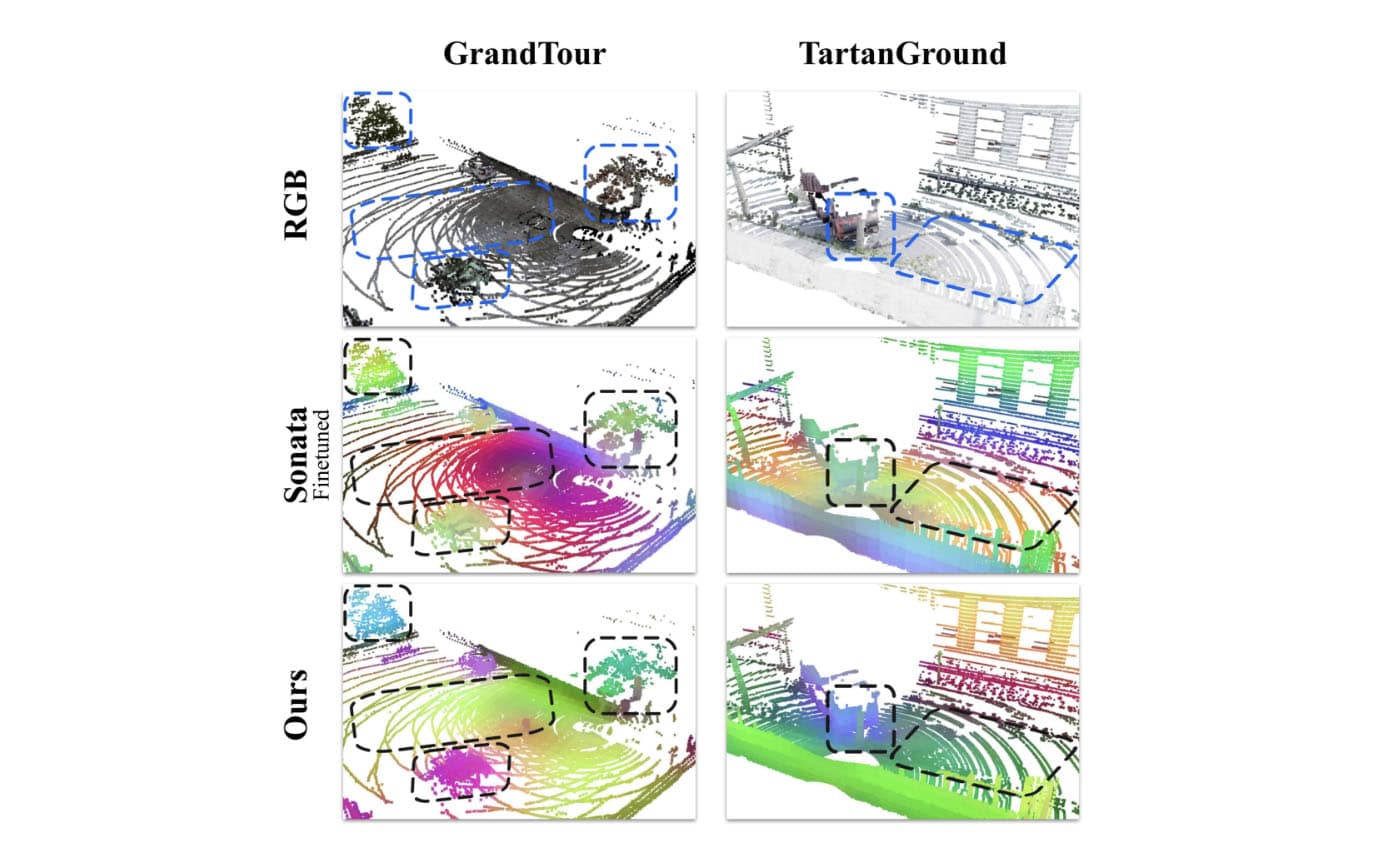
Vernata: Self-Supervised Learning of LiDAR Point Representations
Building upon the Sonata architecture, we introduce Vernata, consisting of three extensions: sparse view augmentation to improve robustness against varying point densities, a memory bank...
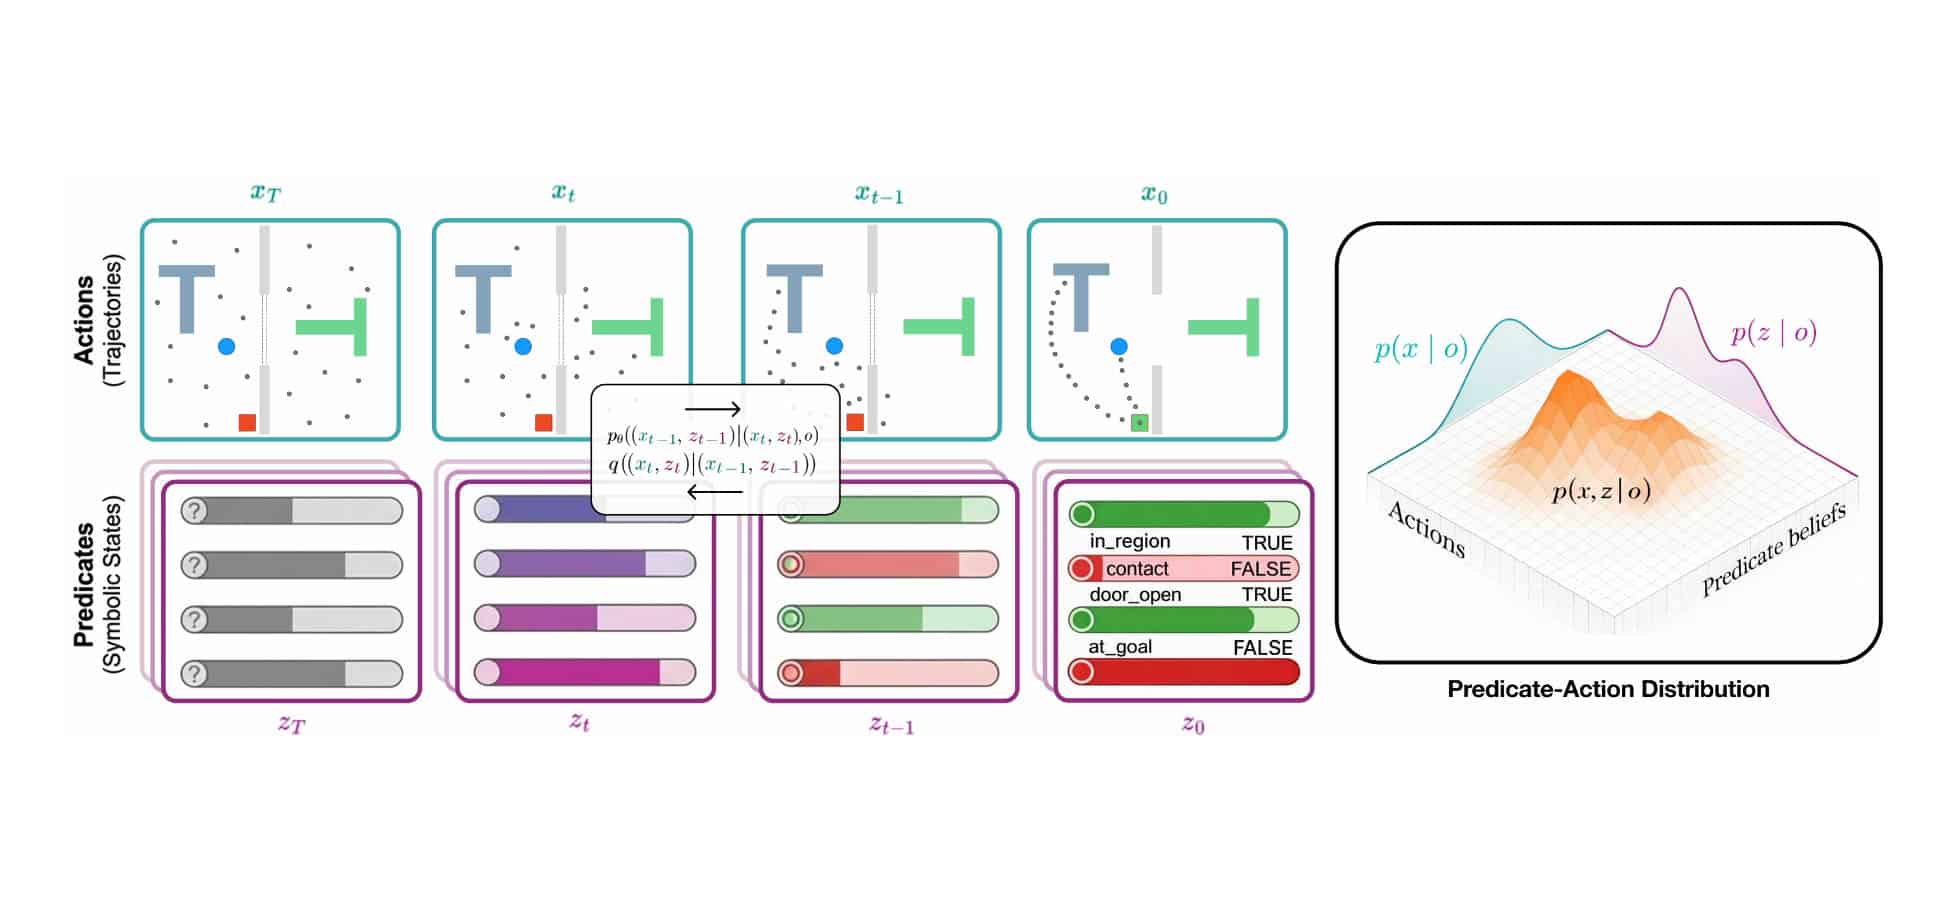
Jointly Learning Predicates and Actions Enables Zero-Shot Skill Composition
We propose that skills should jointly model action trajectories and the symbolic outcomes they induce. To address this gap, we introduce Predicate-Action Skills (PACTS), a...
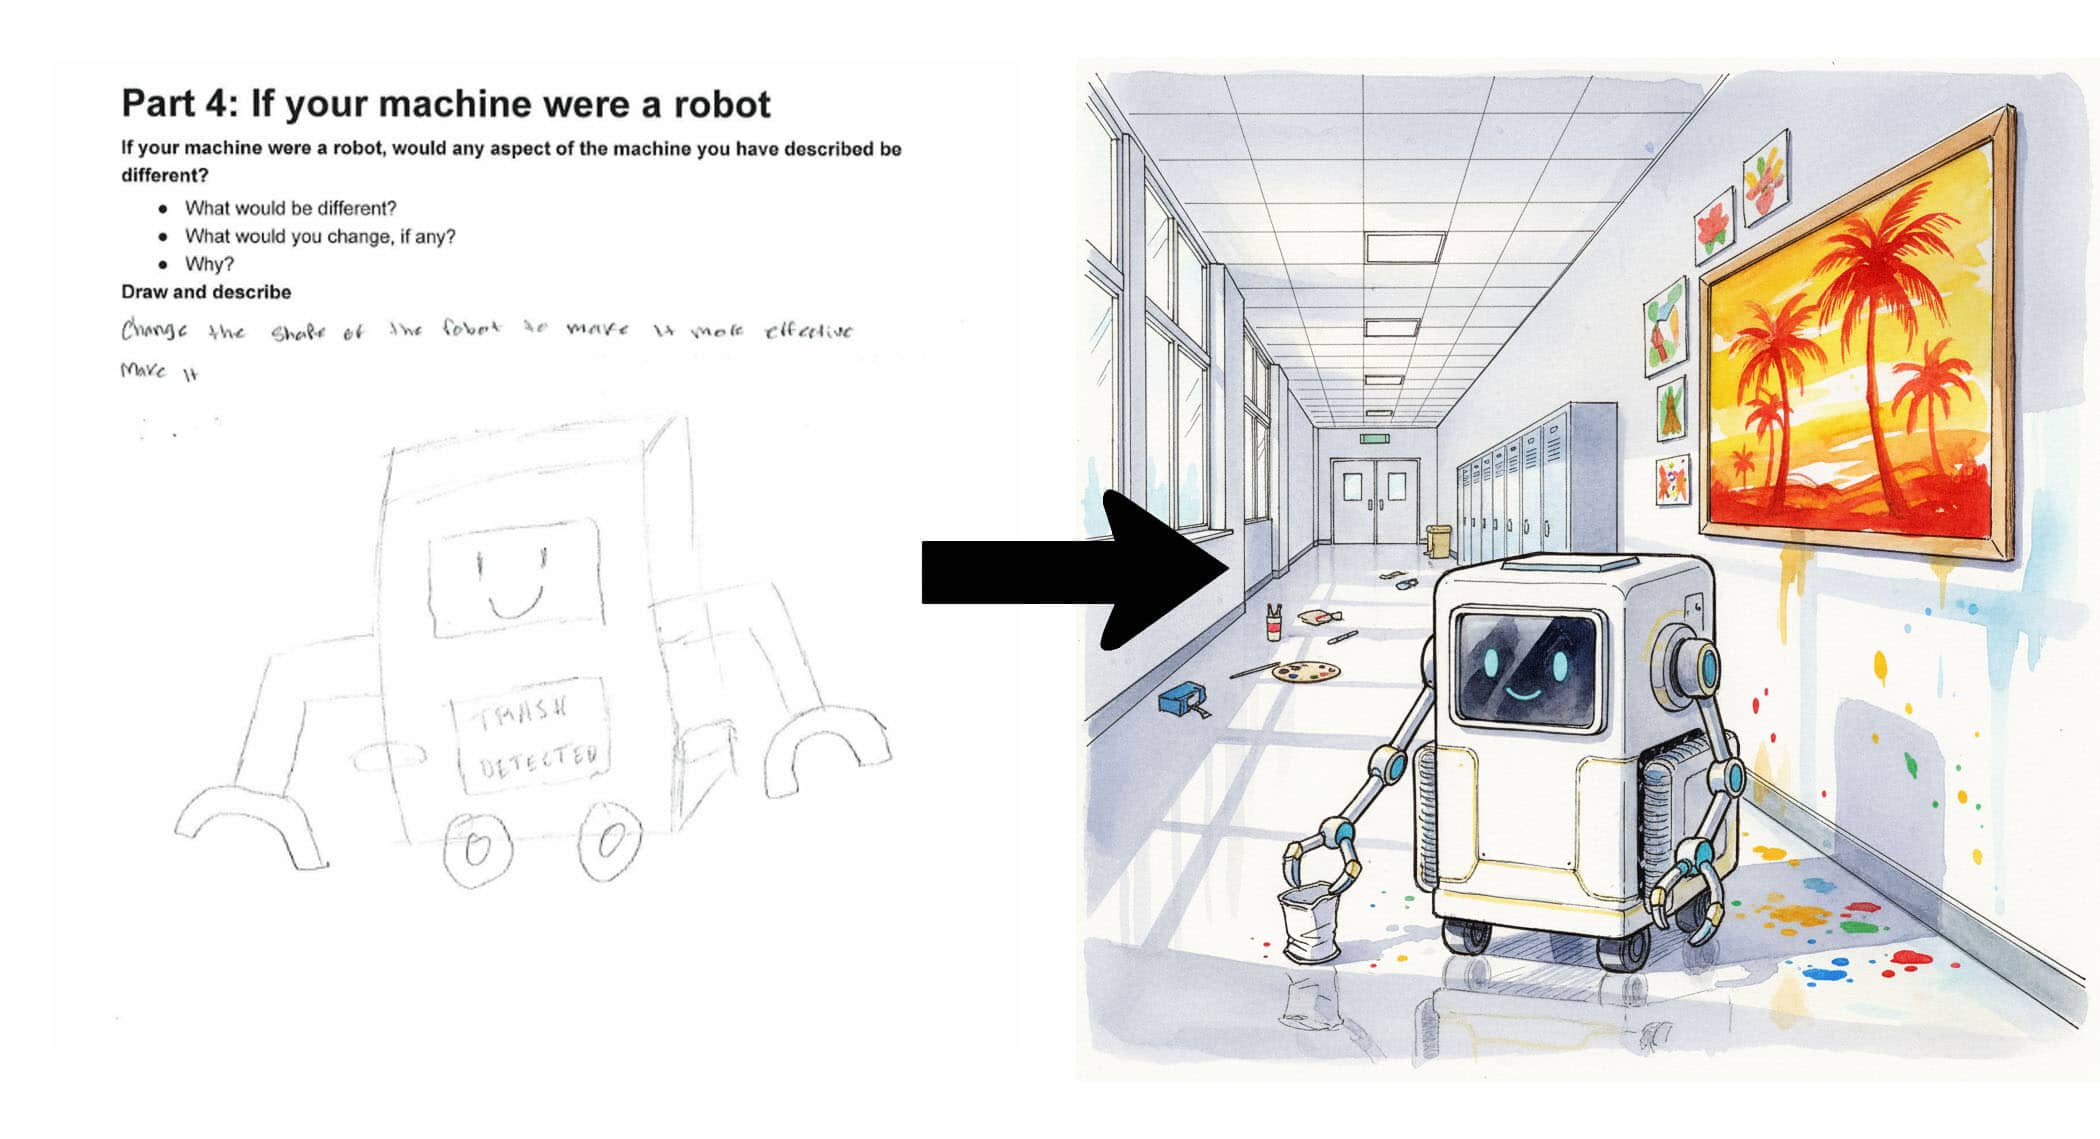
Robots For Everyday Life: Children’s Visions on Roles of Robots
To truly understand how children envision a robot-integrated future, we used personal photo probes and a scaffolded design process to first uncover the values and...
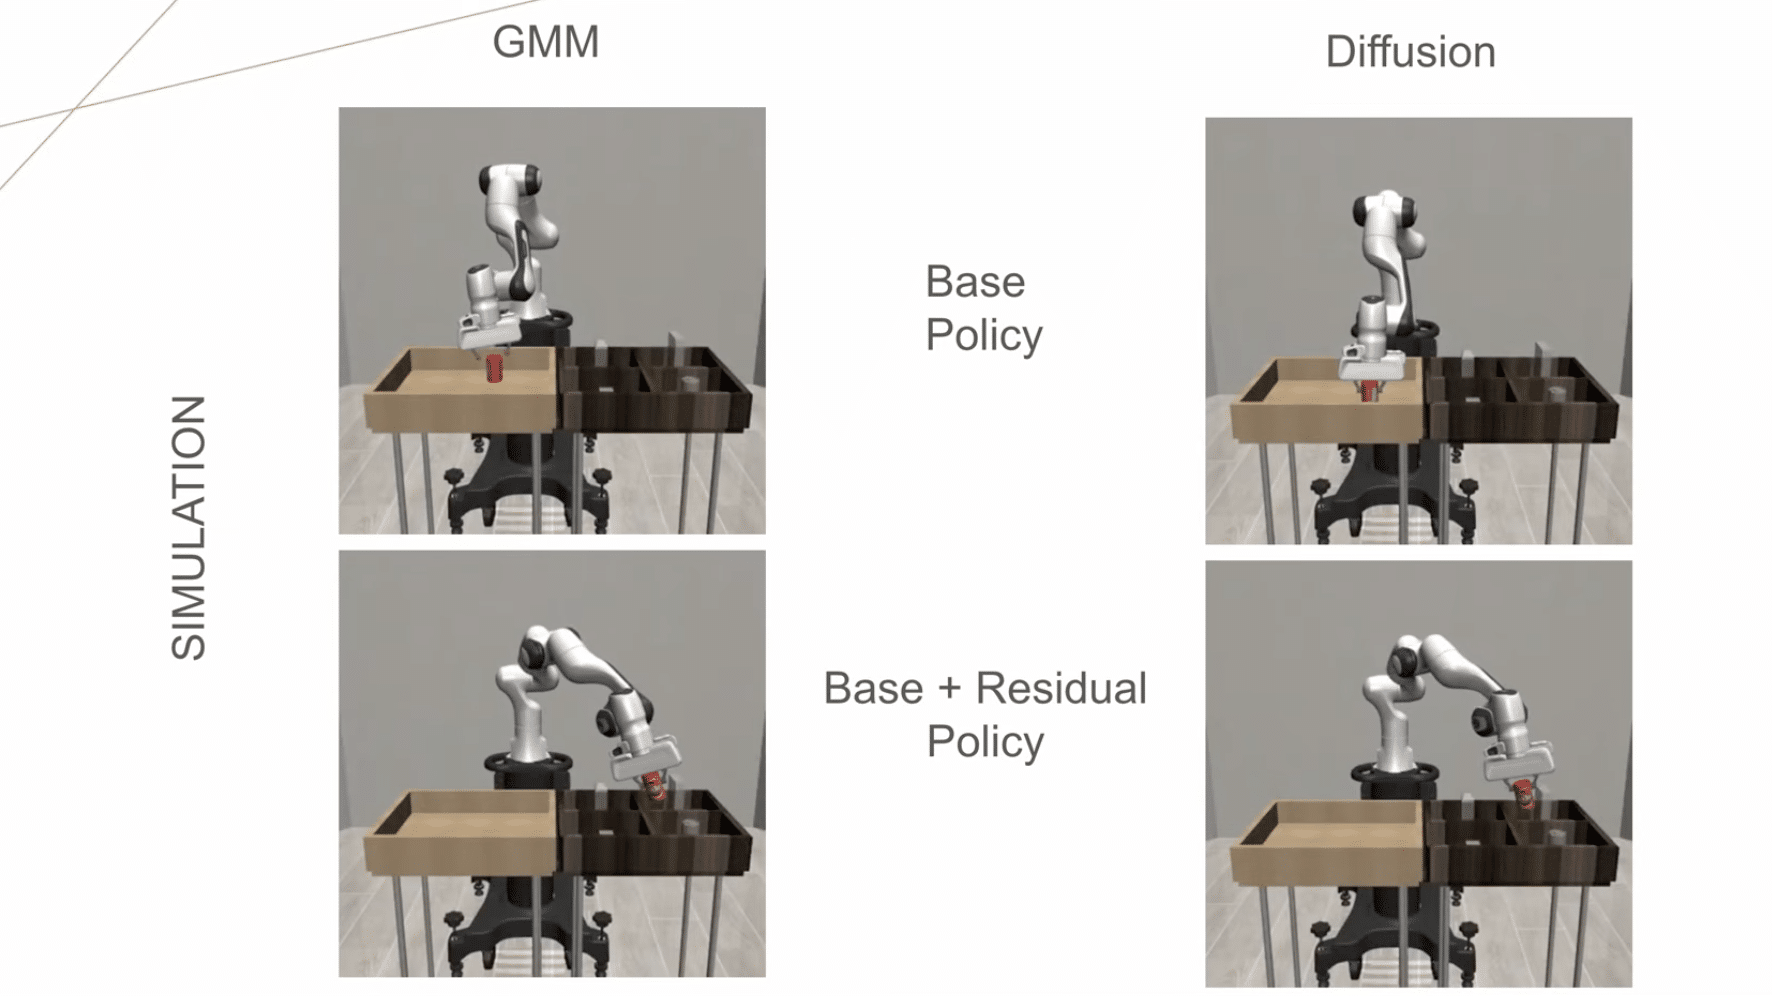
Accelerating Residual Reinforcement Learning with Uncertainty Estimation
We propose two improvements to Residual RL that further enhance its sample efficiency and make it suitable for stochastic base policies. First, we leverage uncertainty...
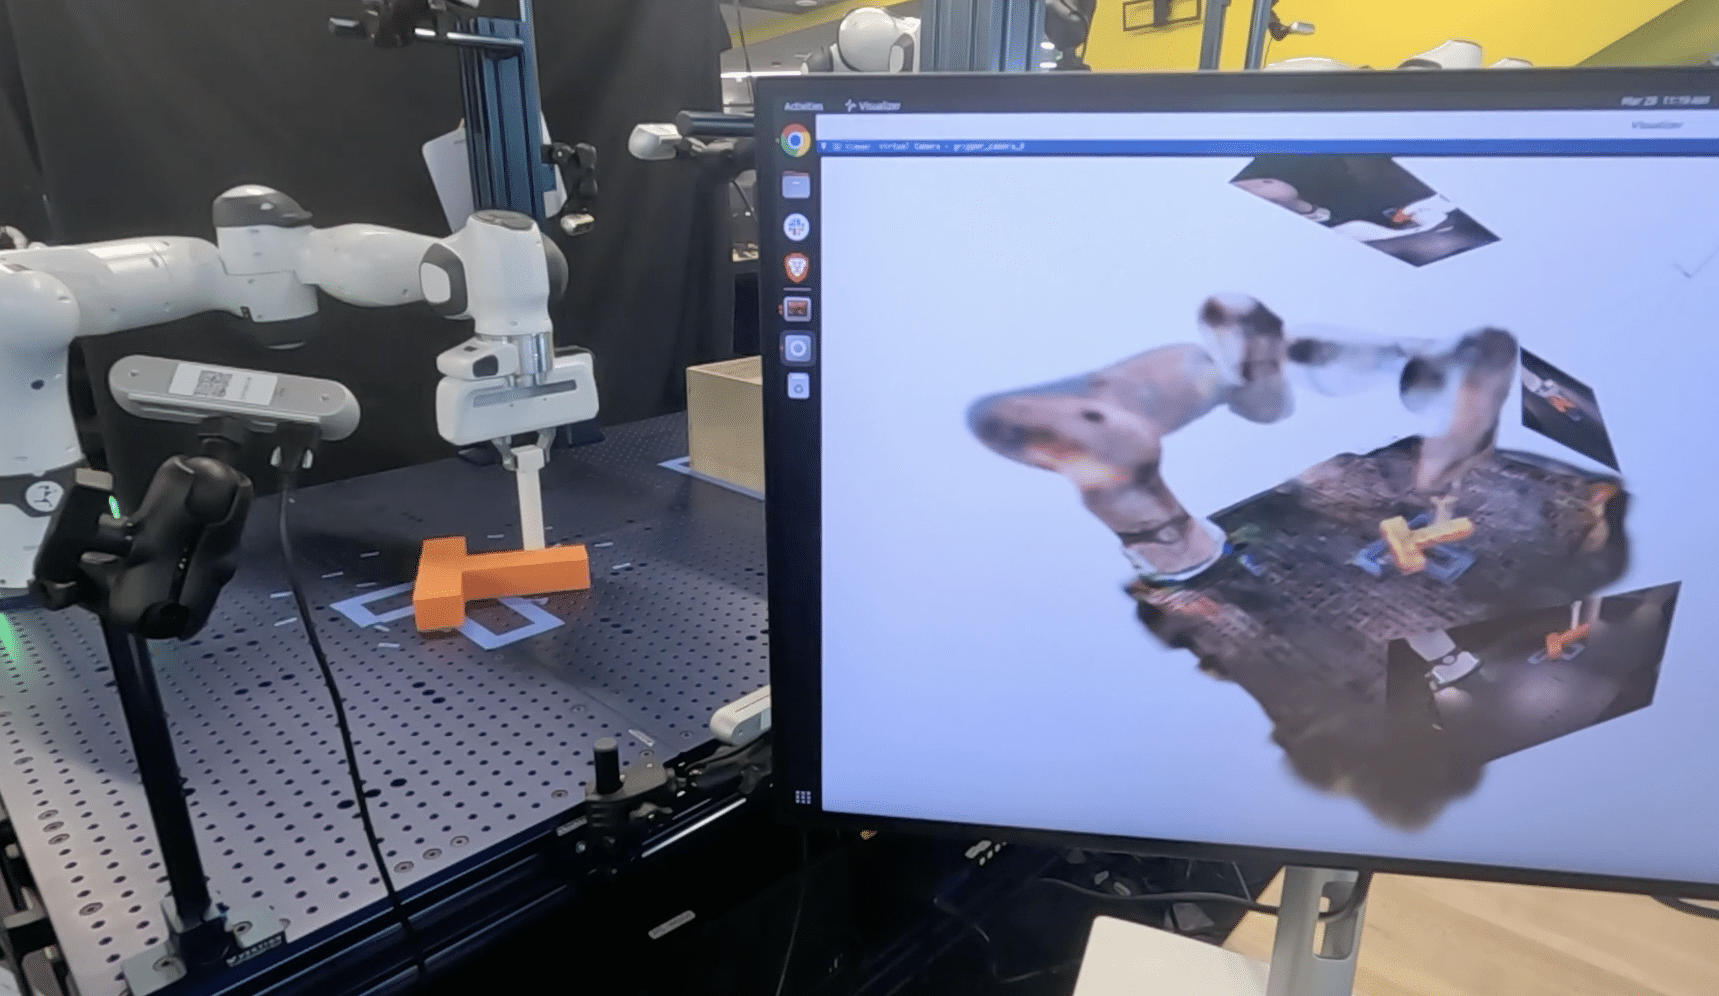
Real-is-Sim: Bridging the Sim-to-Real Gap with a Dynamic Digital Twin
We introduce real-is-sim, a new approach to integrating simulation into behavior cloning pipelines. In contrast to real-only methods, our framework allows policies to seamlessly switch...
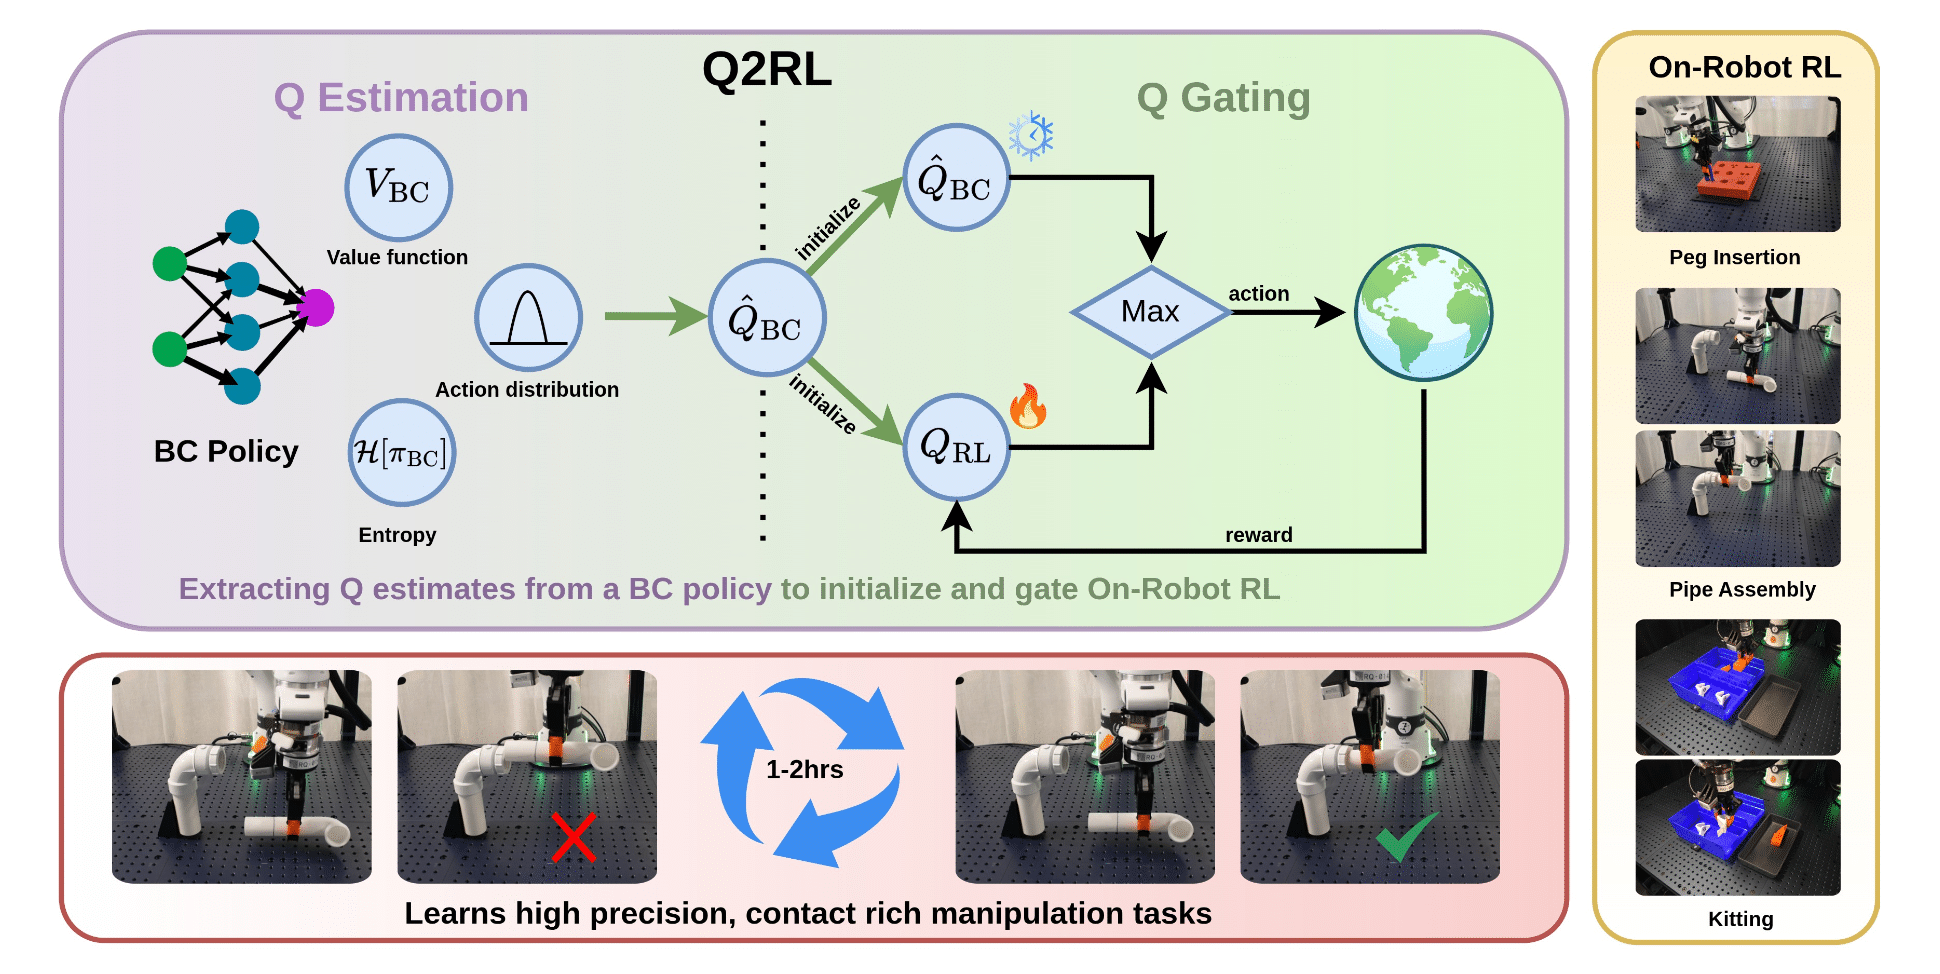
When Life Gives You BC, Make Q-functions: Extracting Q-values from Behavior Cloning for On-Robot Reinforcement Learning
We propose Q2RL, Q-Estimation and Q-Gating from Behavior Cloning for Reinforcement Learning, an algorithm for efficient offline-to-online learning.
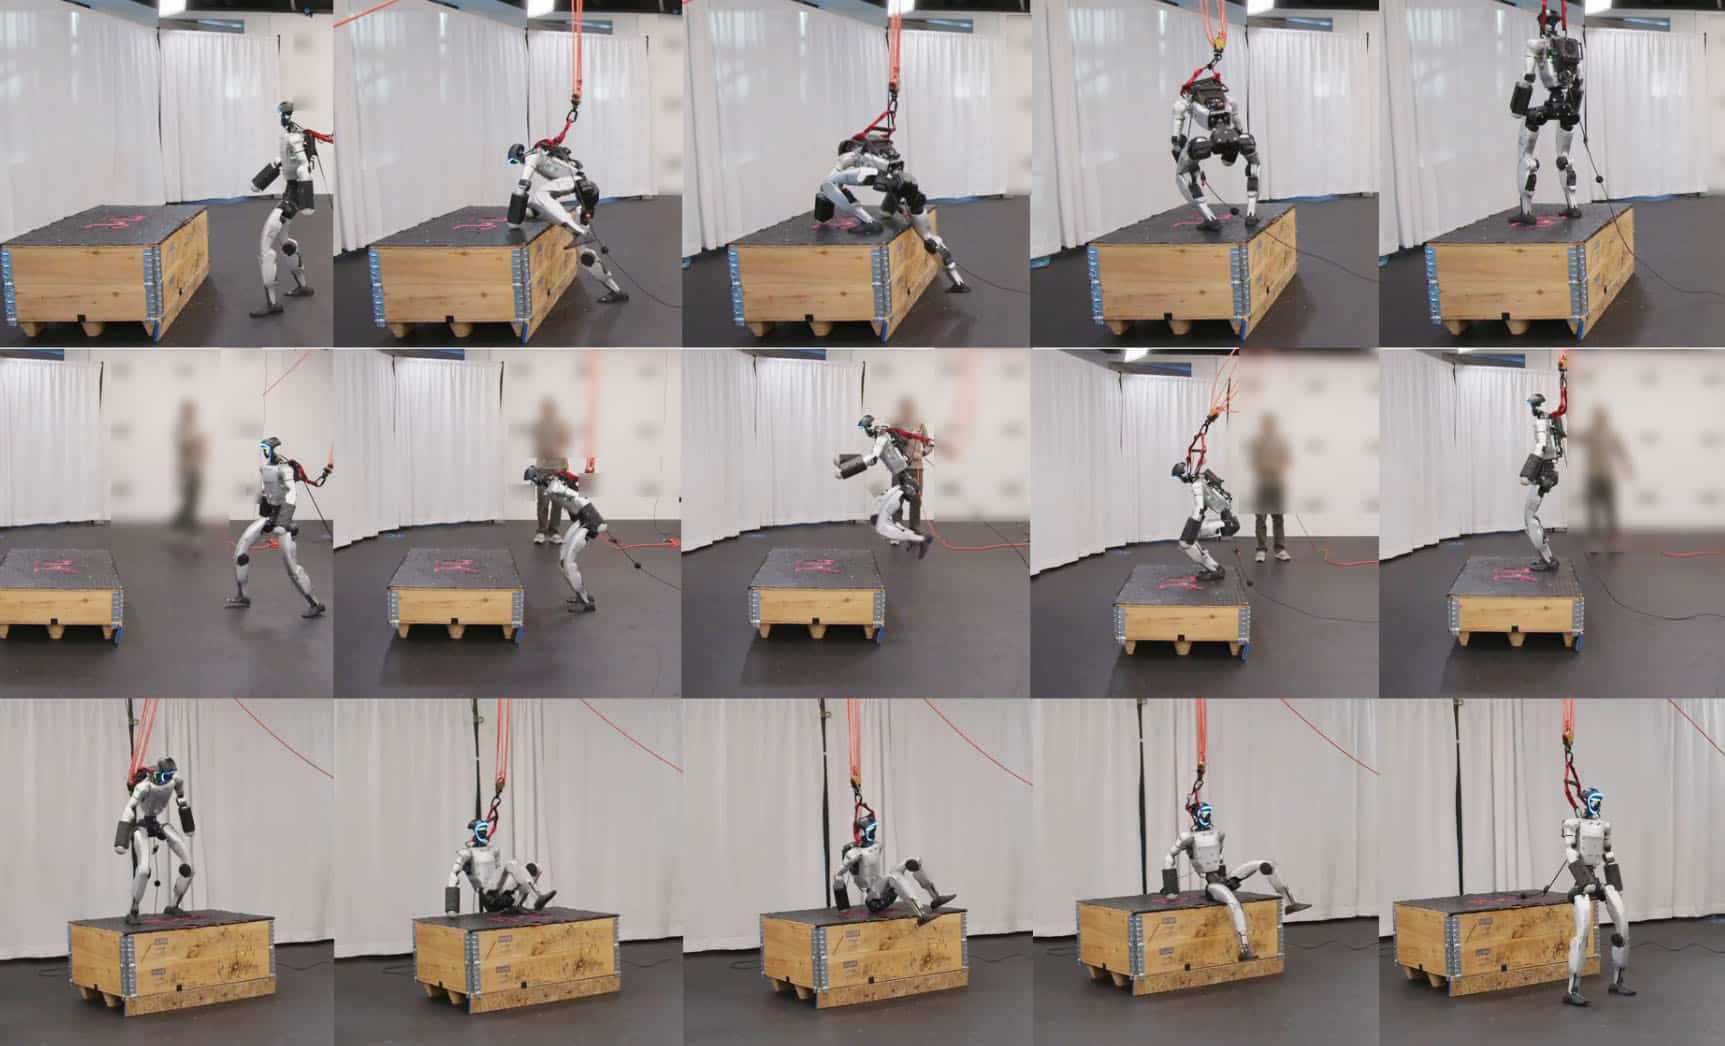
Generalizing from References using a Multi-Task Reference and Goal-Driven RL Framework
We introduce a multi-task RL training paradigm that treats reference motion as a prior for behavioral shaping rather than a deployment-time constraint.
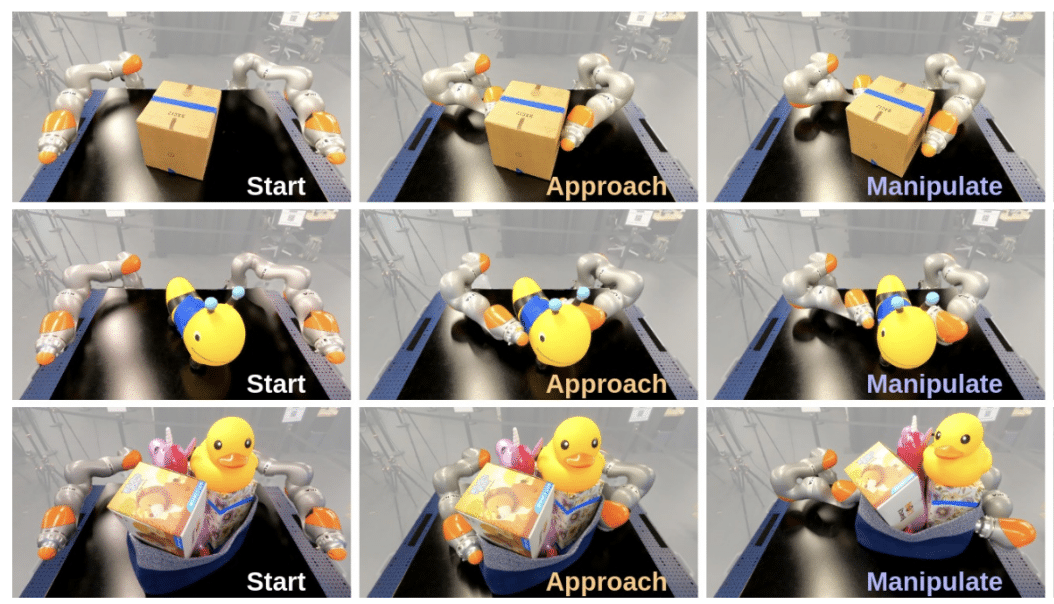
Planning-Guided Diffusion Policy Learning for Contact-Rich Bimanual Object Reorientation
We introduce Planning-Guided Diffusion Policy Learning (LIDE), an approach that effectively learns to solve contact-rich bimanual manipulation tasks by leveraging model-based motion planners to generate...