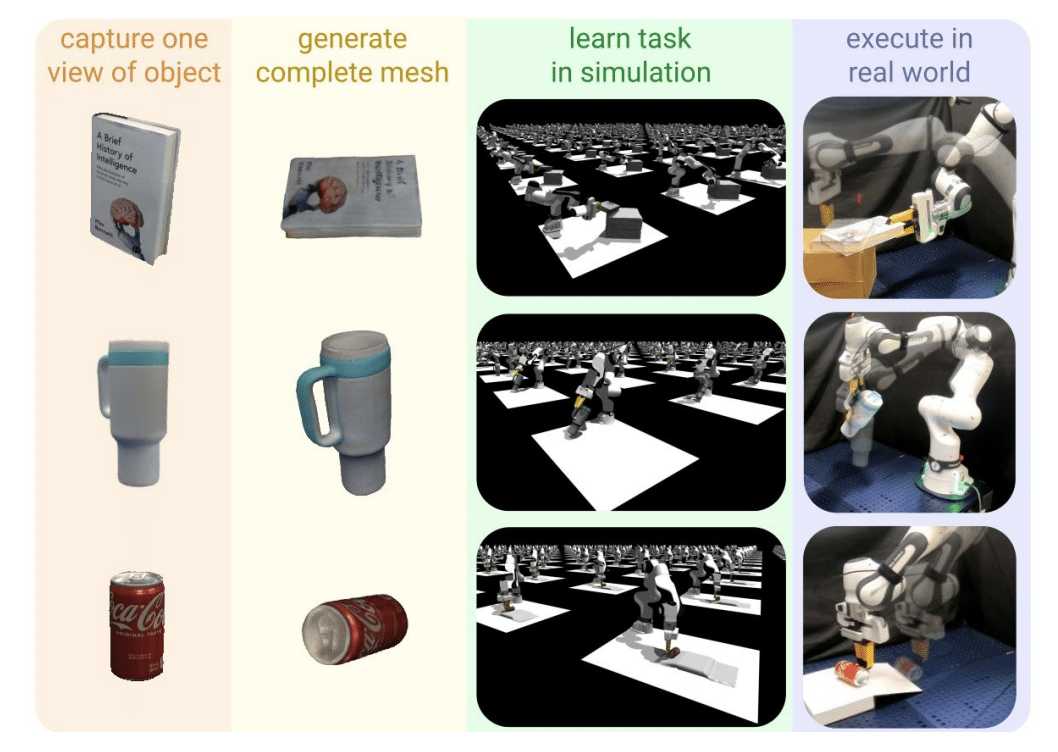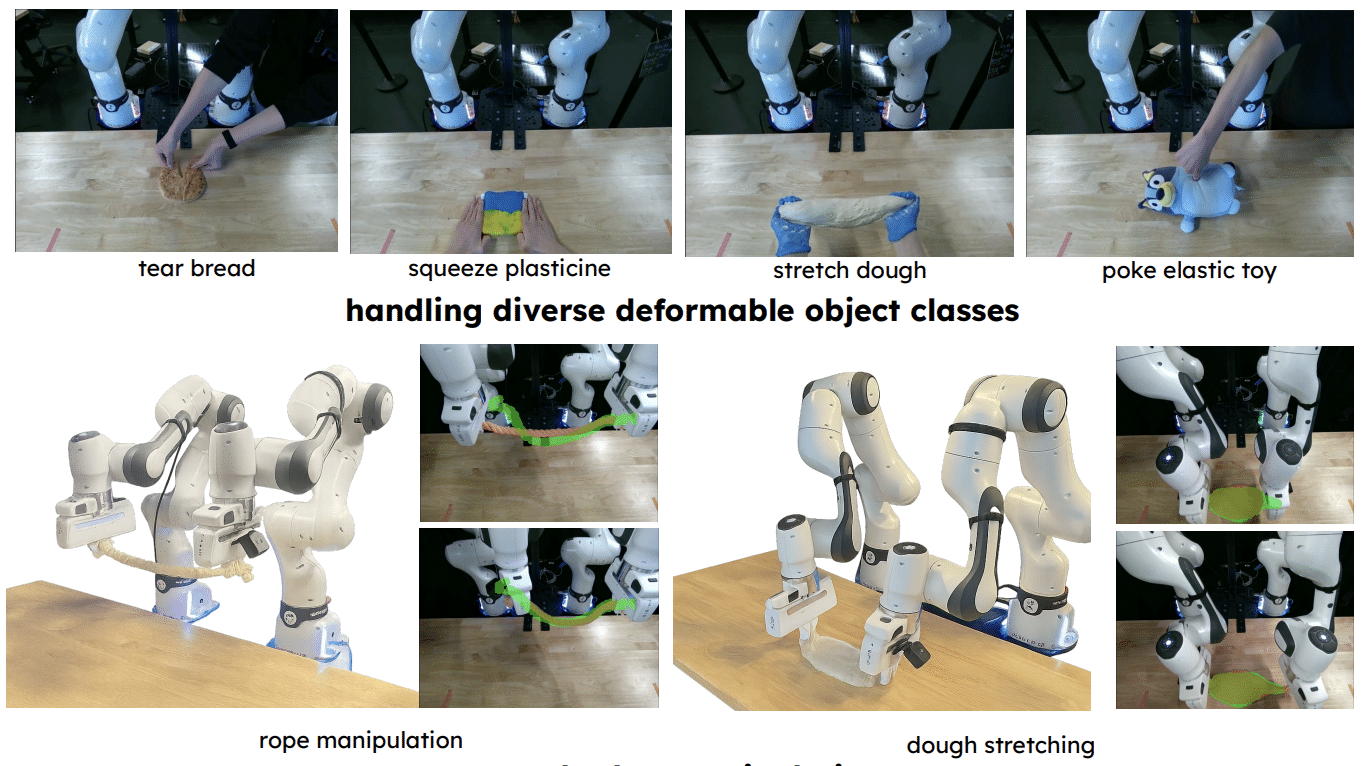
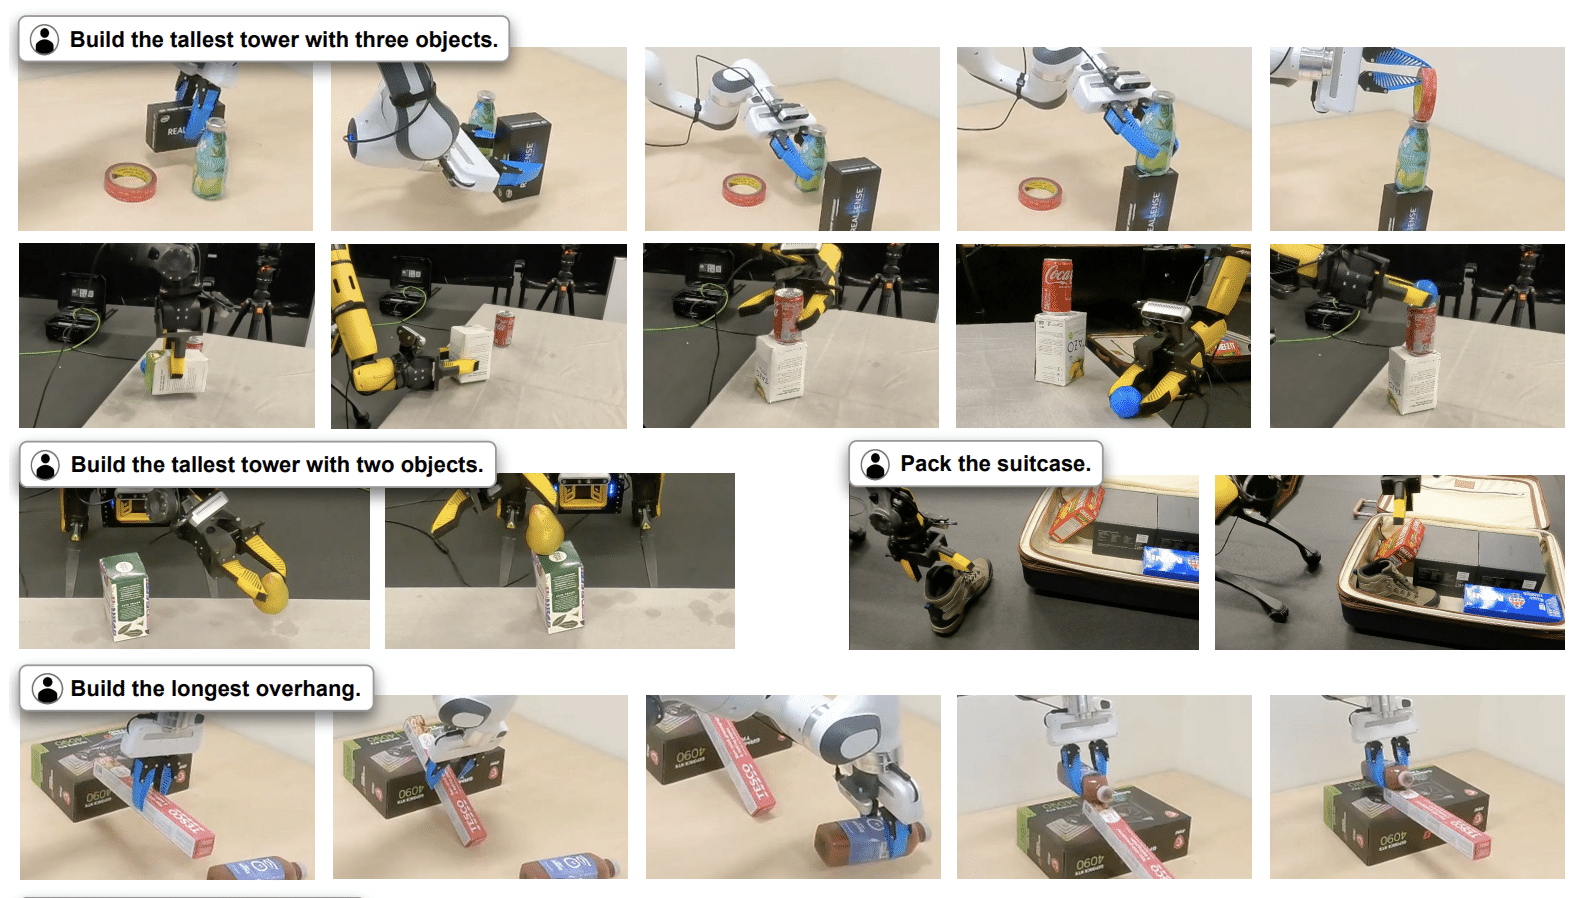
We introduce Simify, a training-free, test-time framework that performs explicit spatial reasoning via massively parallel physics simulation.
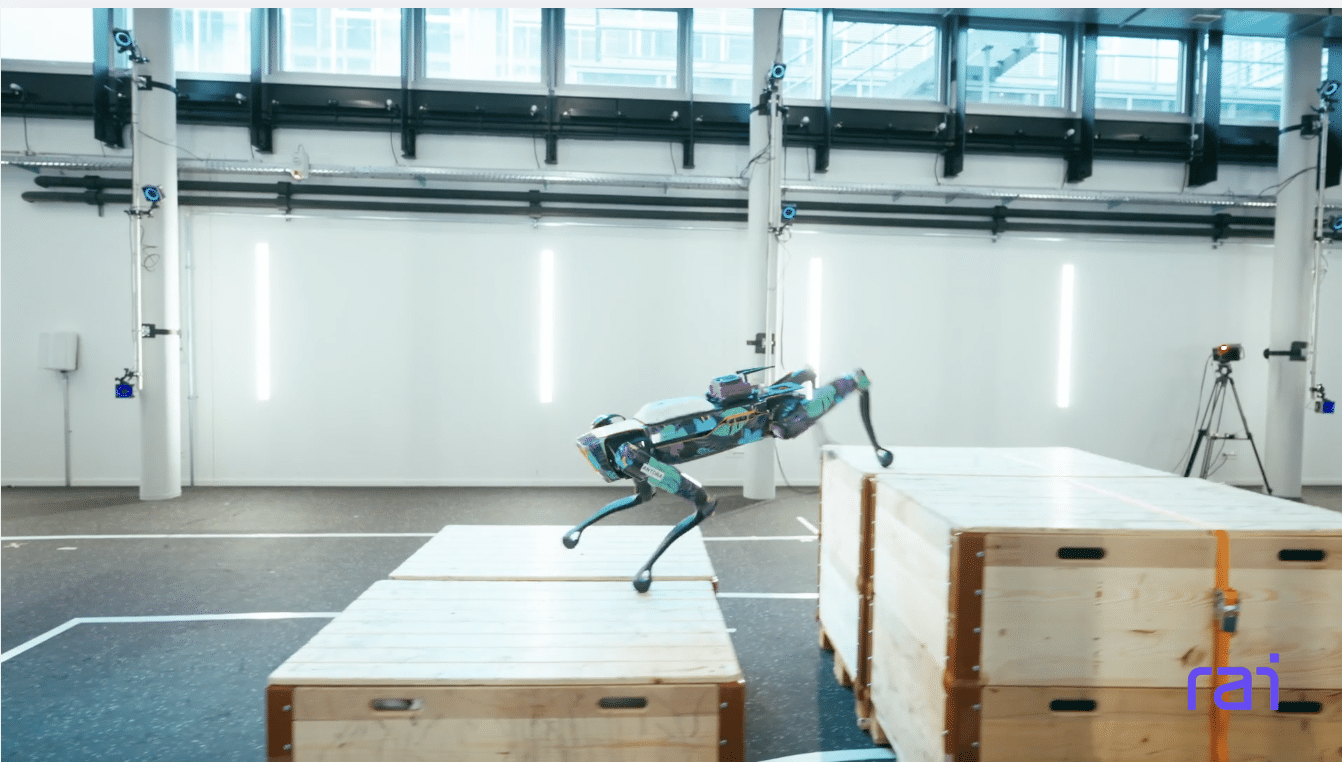
Introducing Exploy: Simplifying RL Policy Deployment in Autonomous Robotics
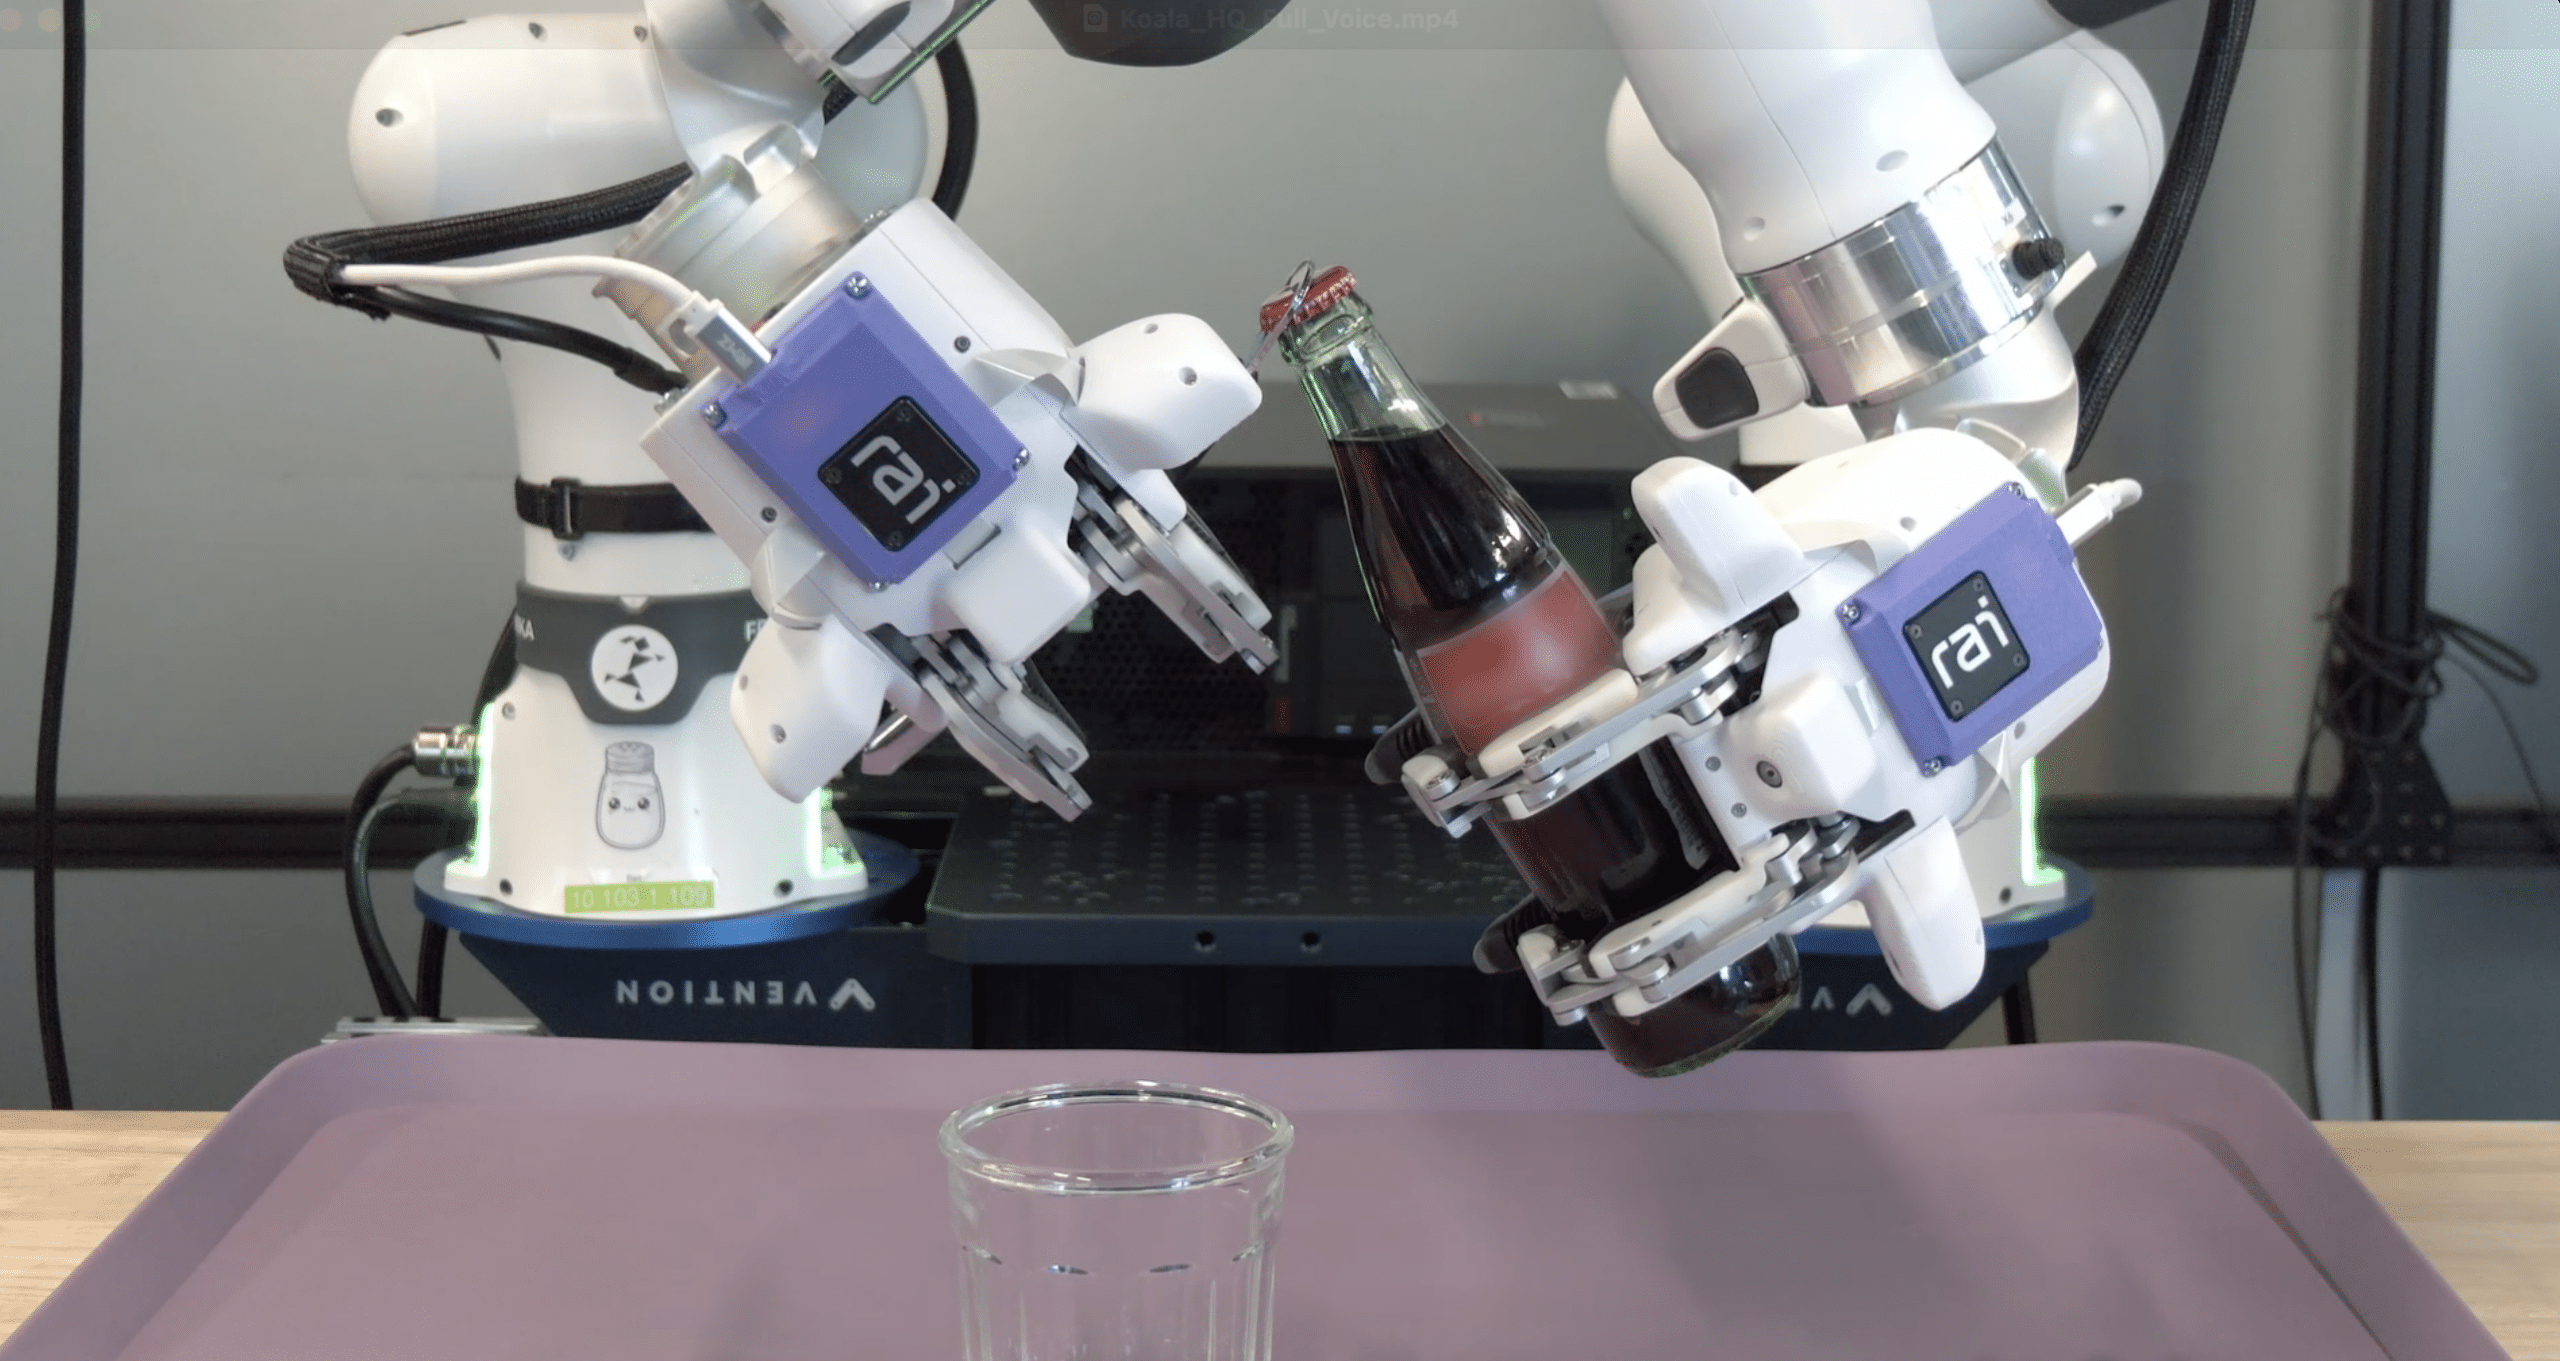
Exploy, an open-source library that packages environment logic and neural network policies into a single, self-contained computational graph, was created for rapid iteration and deployment...