Abstract
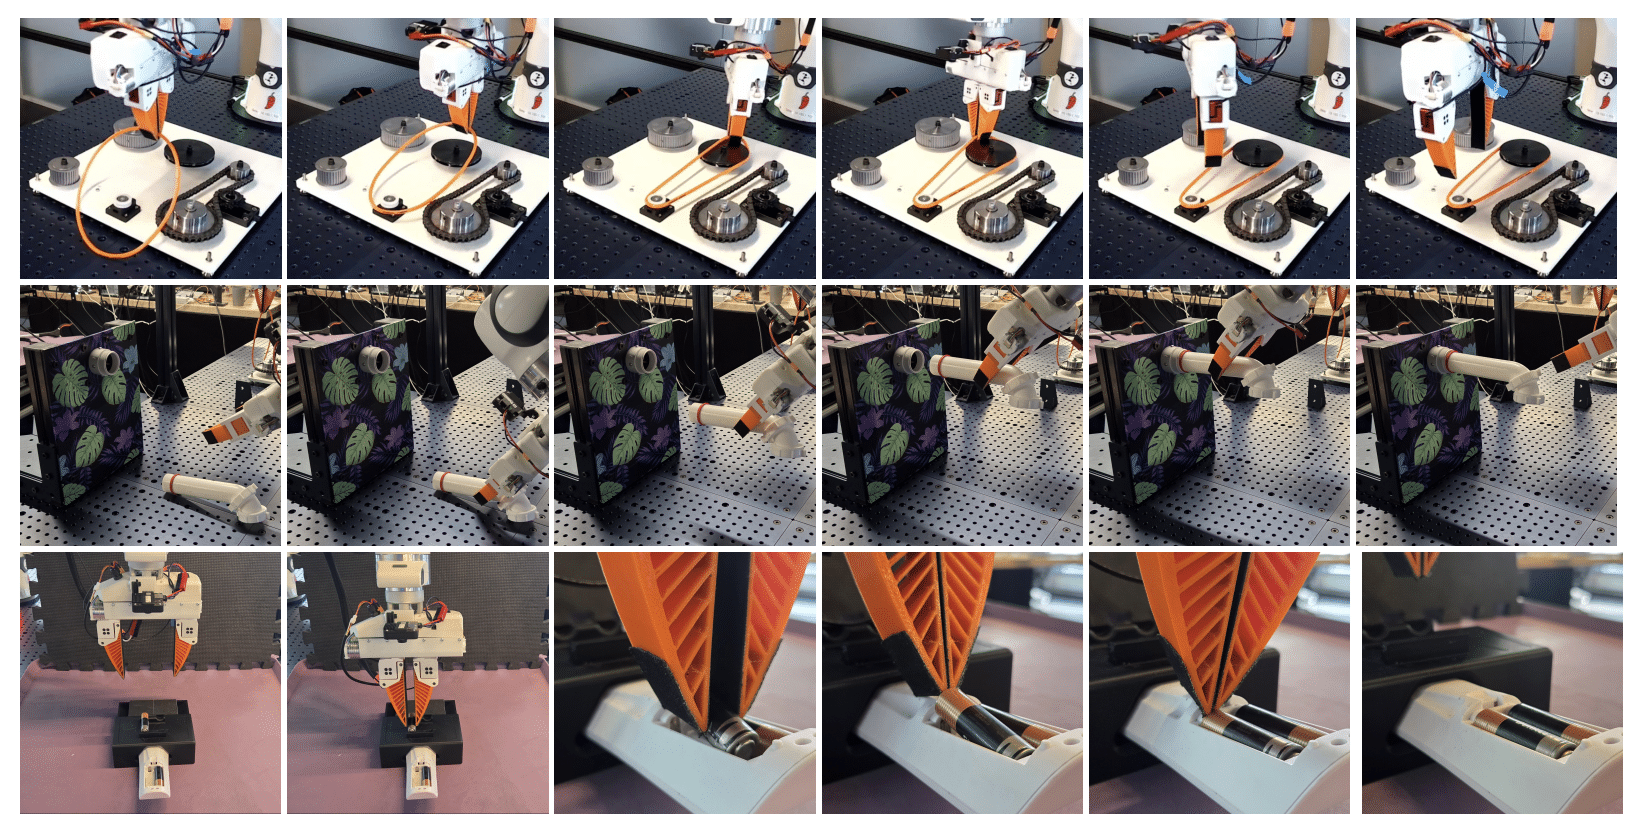
Portable data-collection interfaces enable the acquisition of real-world manipulation demonstrations without requiring a robot during collection. We present Eucalyptus, an extension of UMI designed for sustained, force-aware data collection. Eucalyptus combines a robustified and ergonomics-oriented mechanical design with a high-fidelity multimodal sensing suite comprising RGB vision, gripper width, interaction forces, and 6-DoF pose. The mechanical redesign eliminates measurable backlash, expands the maximum gripper width, improves ergonomics for a wide range of hand sizes, and supports an expanded sensing stack. Together, these changes improve the experience of data collection for the operator and provide richer measurements of the demonstrator’s interaction with the environment. We characterize the system and validate its utility through downstream visuomotor policy learning of several contact-rich tasks.