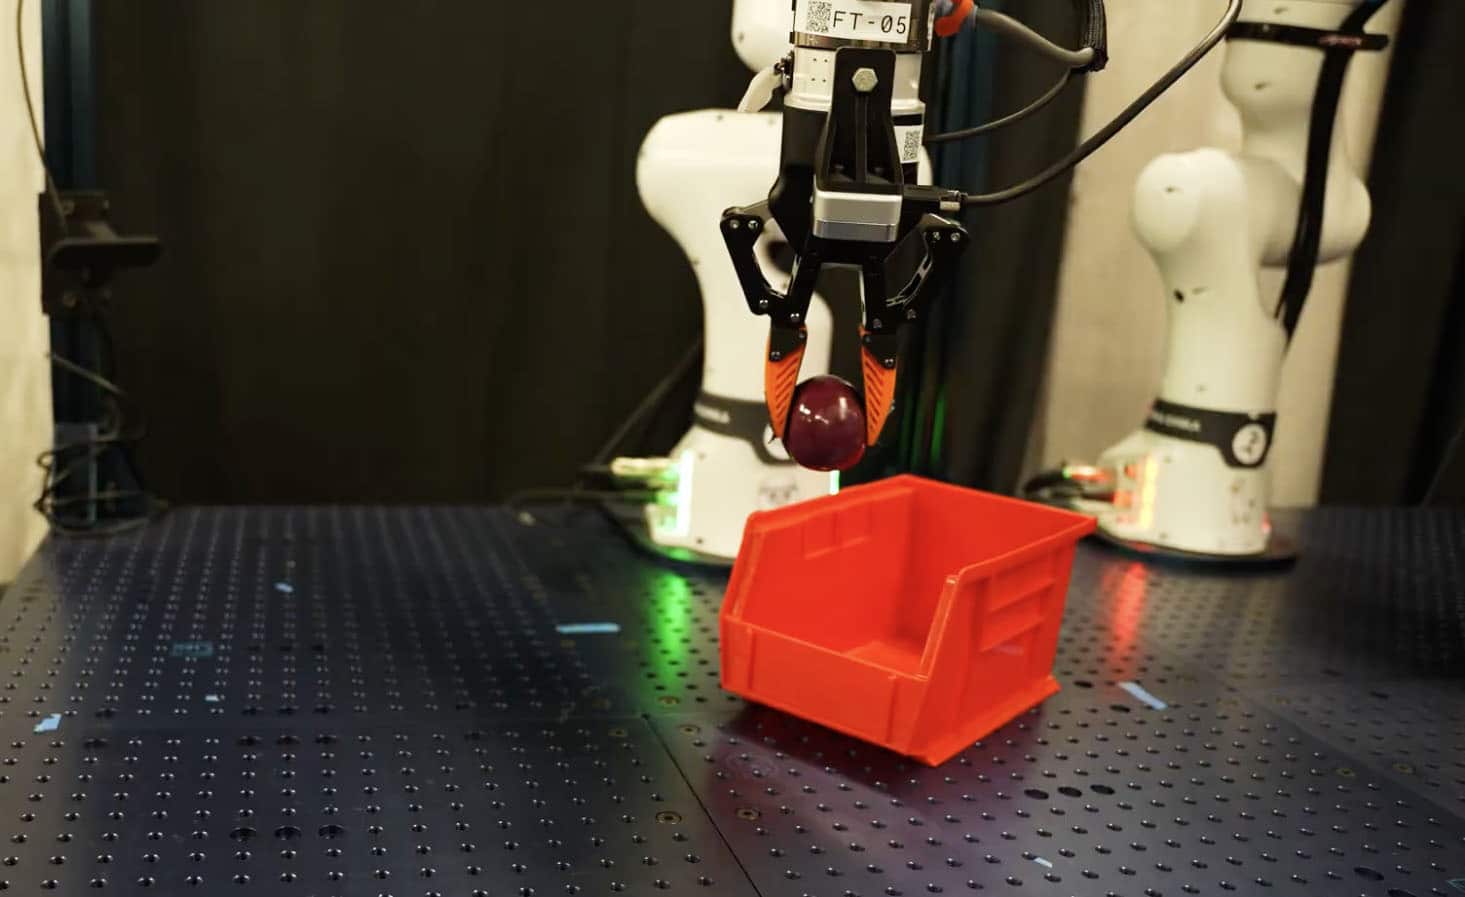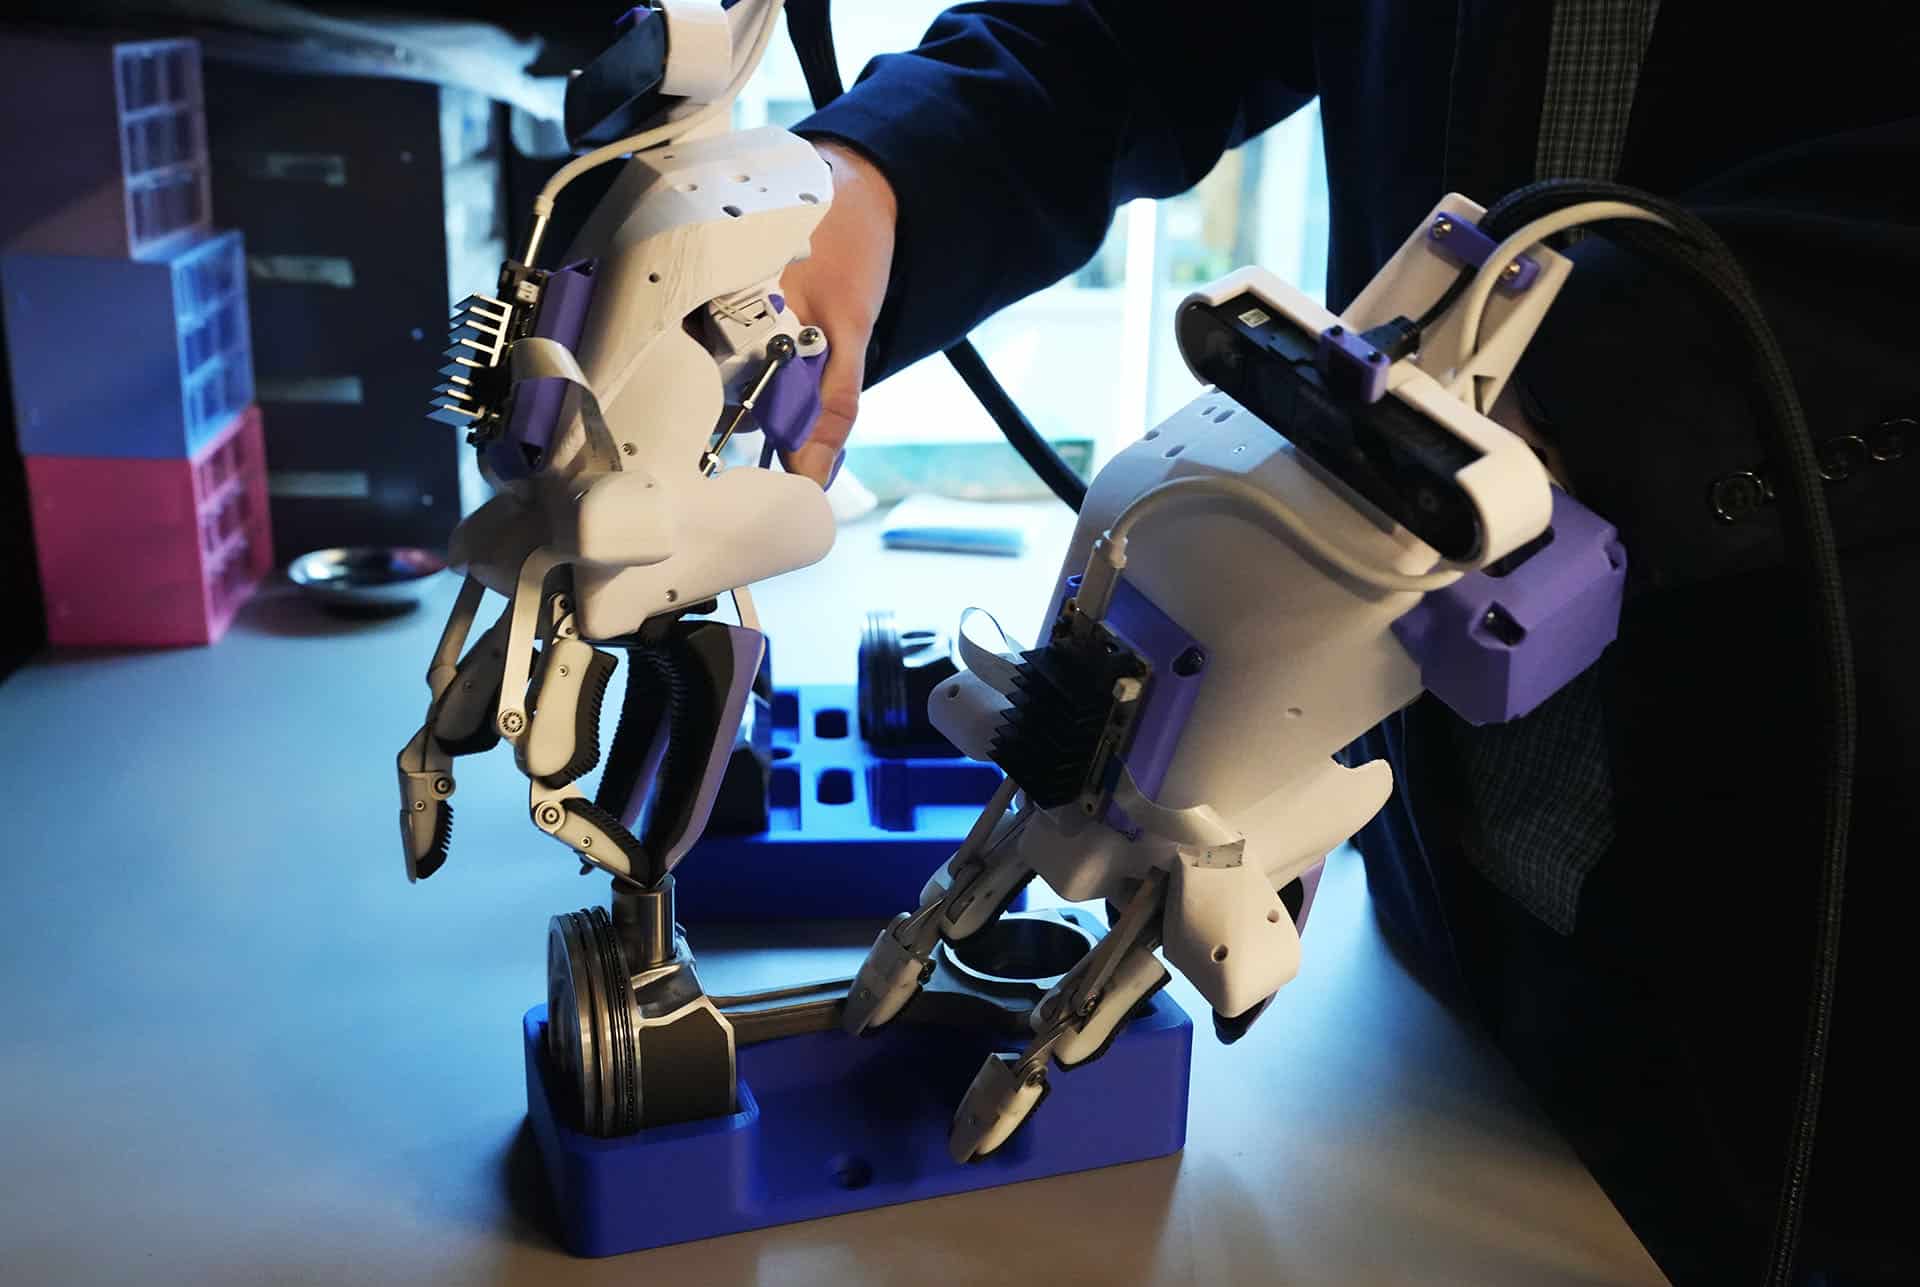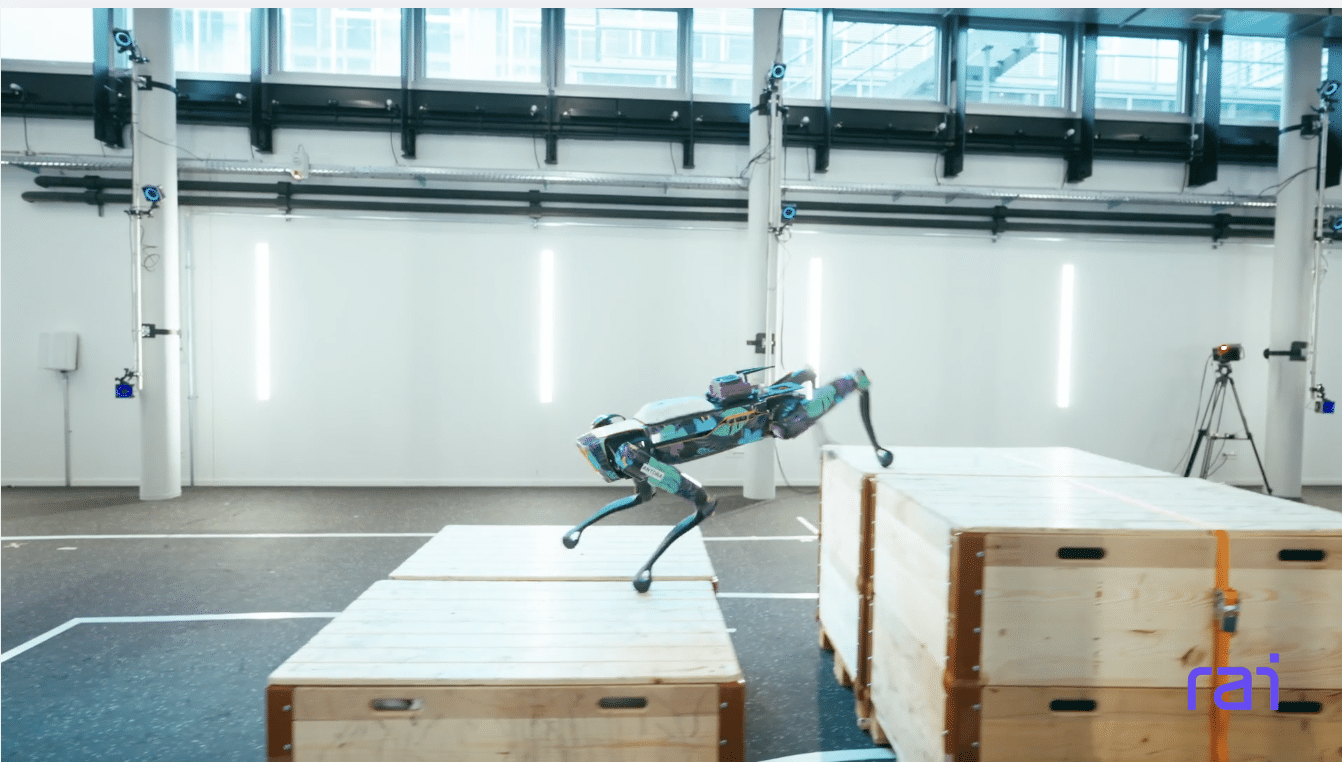

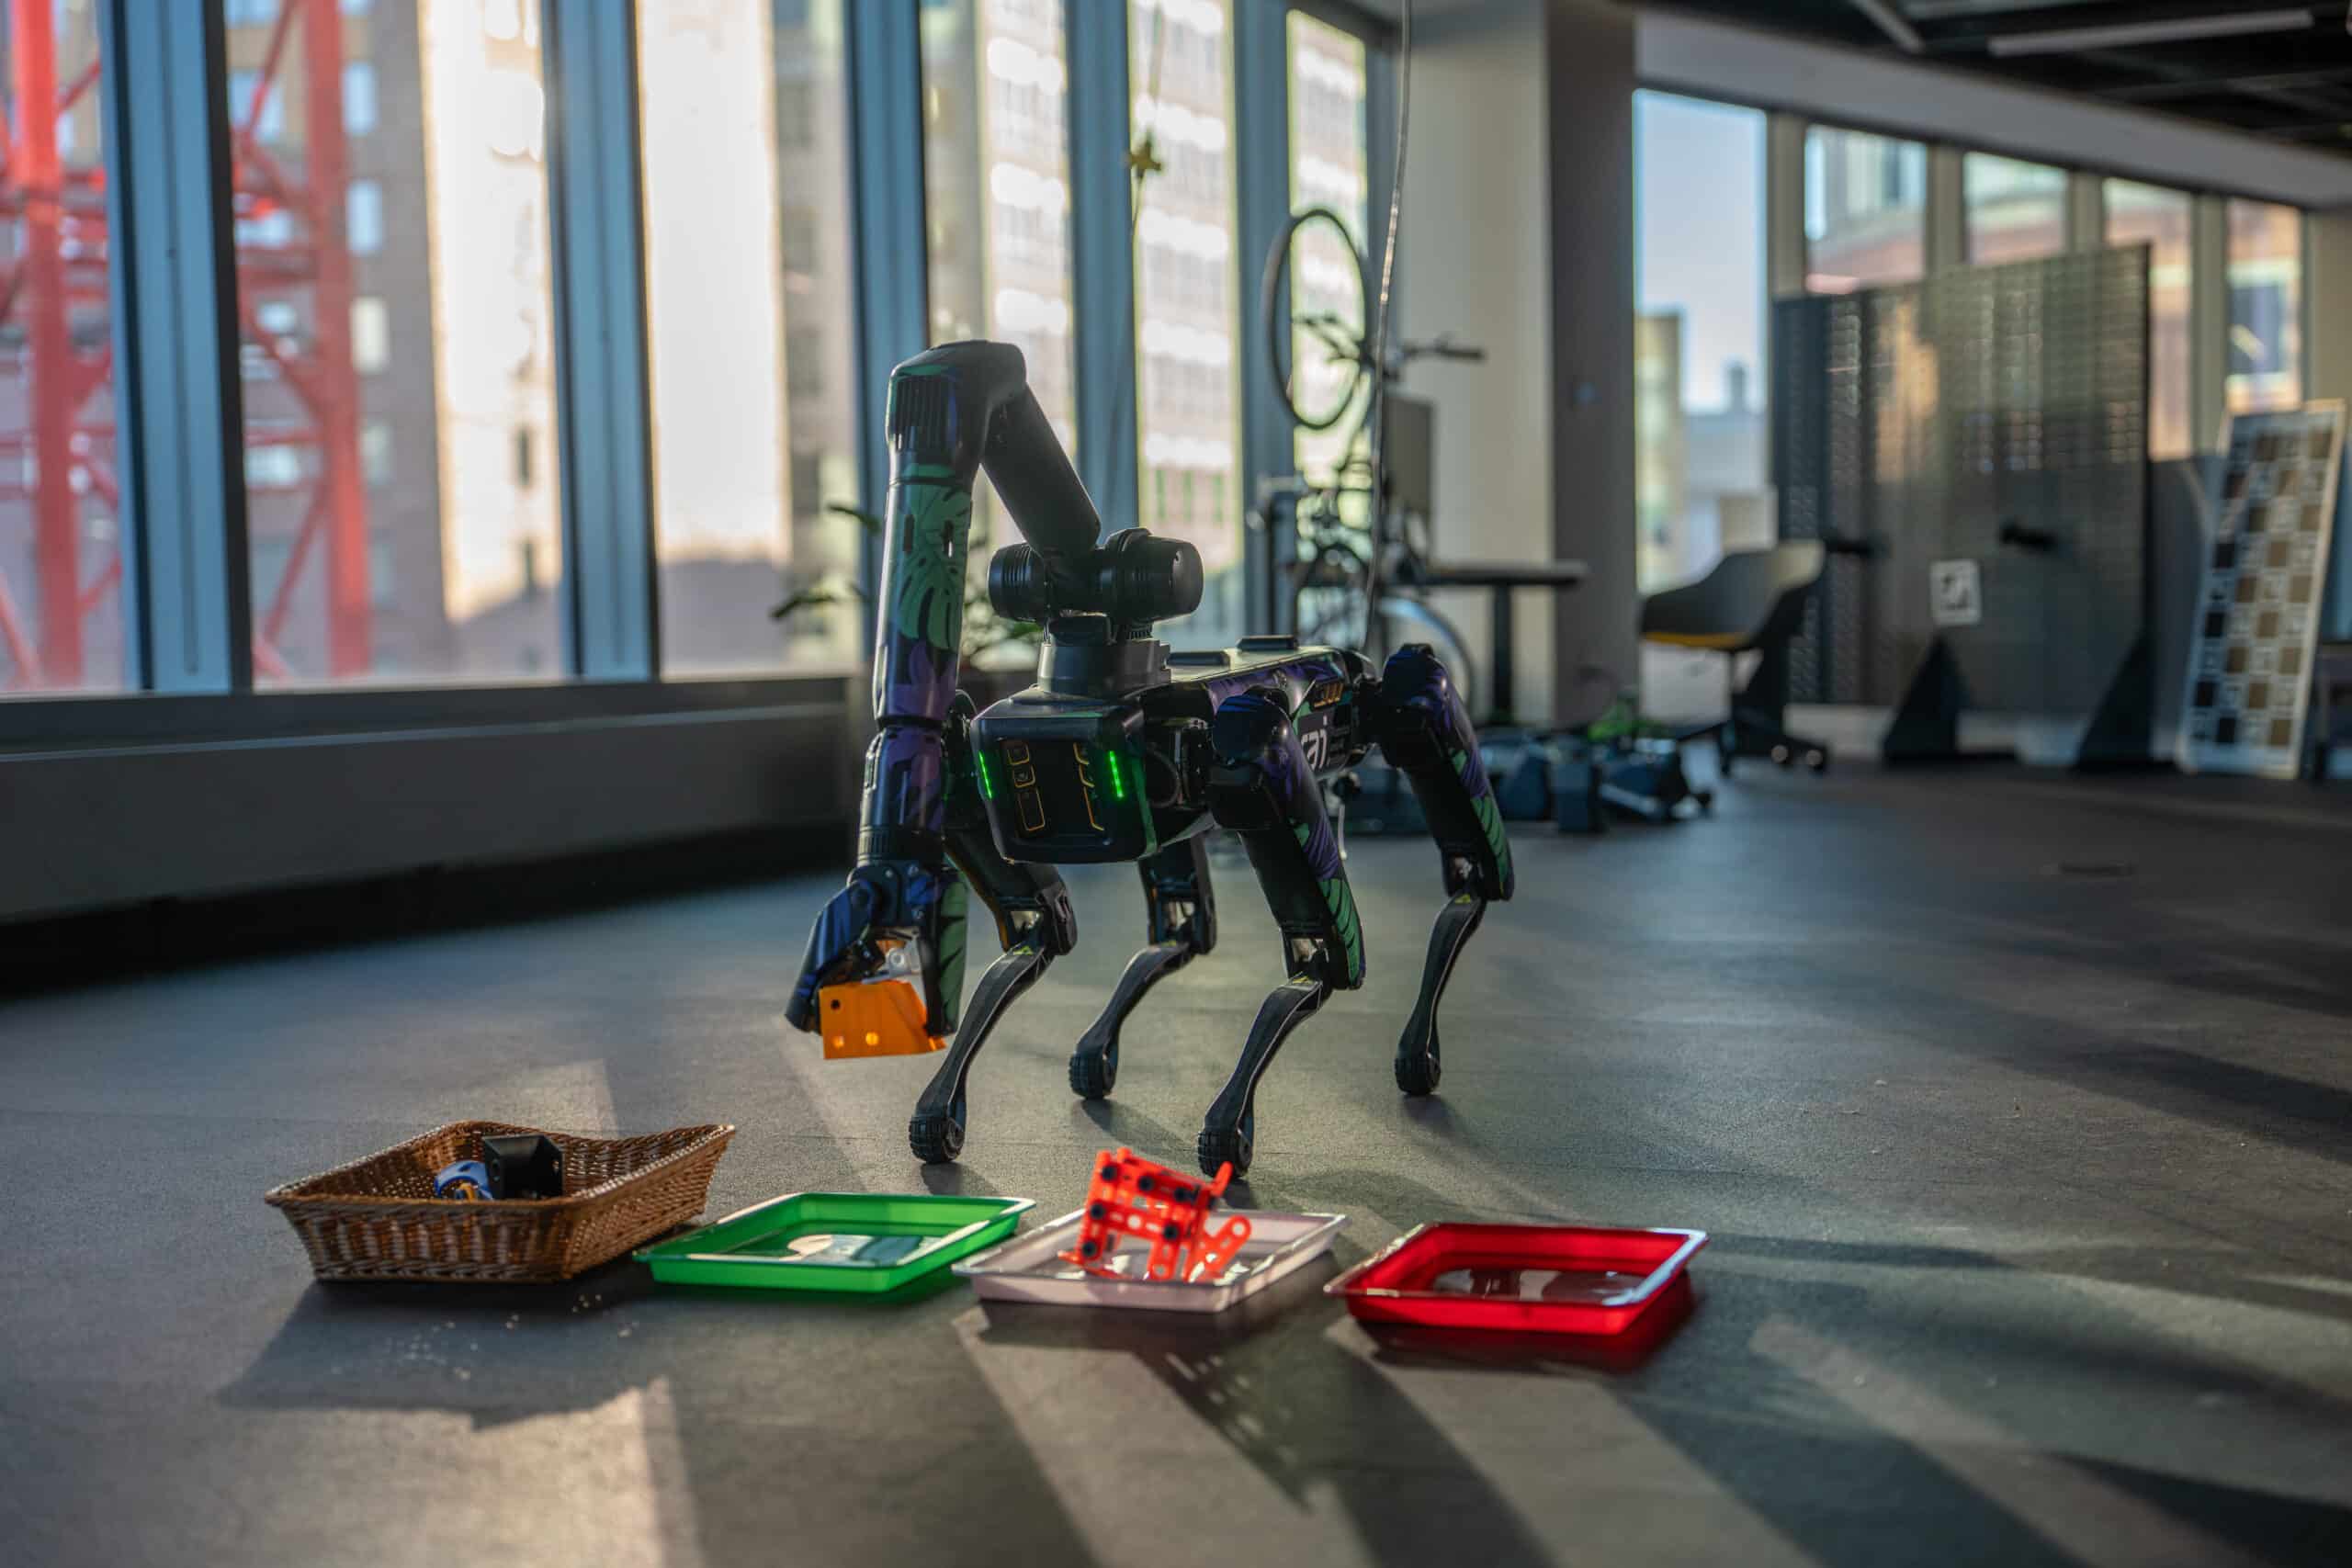
Automatically converting demos into labeled datasets to enable the rapid training of task-specific object detectors that outperform existing state-of-the-art VLMs.
Introducing Exploy: Simplifying RL Policy Deployment in Autonomous Robotics
Exploy, an open-source library that packages environment logic and neural network policies into a single, self-contained computational graph, was created for rapid iteration and deployment...