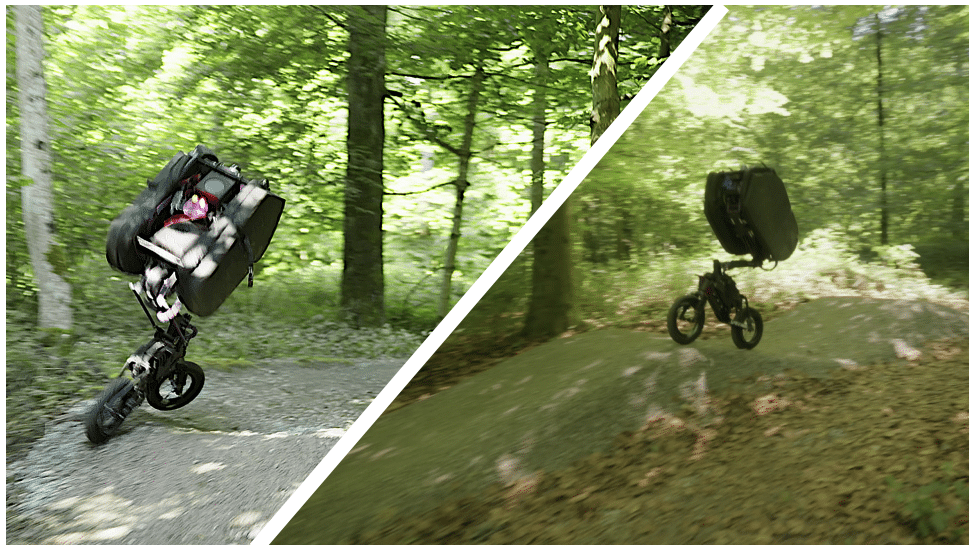
We show that autonomous, high-speed trail navigation can be achieved through a single idea: encoding the trail as a semantic layer of the terrain.
Cognitive Intelligence
We won’t need a fleet of programmers every time a robot needs to do a new task.
The robot will understand what it sees, determine how to navigate the space, and figure out what manipulation tasks are needed.
Morphology

If robots are smart enough, we won’t need a fleet of programmers every time a robot needs to do a new task. The robot will understand what it sees, determine how to navigate the space, and figure out what manipulation tasks are needed to perform to successfully complete the assignment. It will also map the observed process onto hardware — its own morphology and the morphology of other robots — and consider how available infrastructure such as tables, fixtures, and tools can be used.
Benefit/Concept
Although not every human being is an athlete, we all possess high levels of athletic intelligence. In humans, athletic intelligence is what enables balance while walking, running, and climbing, utilizing real-time perception to maneuver through terrain and around obstacles and opponents, grasp and manipulate objects, and manage motion energetics to achieve remarkable endurance and strength. The Institute’s work on athletic intelligence will address capabilities of robots that physically move in the world, including their mobility, navigation, and dexterity.
Benefit/Concept
The ultimate goal of the Institute's work is to solve problems that are relevant to a wide range of machines that work in a wide range of industries. Just as basic education gives people skills and capabilities that allows them to perform well at a wide range of jobs, we hope to give robots and other machines capabilities that make them easier to use, and more effective. Making fundamental progress will take time — we are focused on a 5-8 year horizon for practical results.


Looking for something new?
Our team combines the best features of university research labs with the best features of corporate innovation groups.
Related Resources
CoRL 2026 Publication and Workshop Round Up
Research teams at the RAI Institute had several papers and workshops accepted for CoRL 2026, covering topics such as handheld data collection, loco-manipulation, robot mapping and perception, sim-to-real...
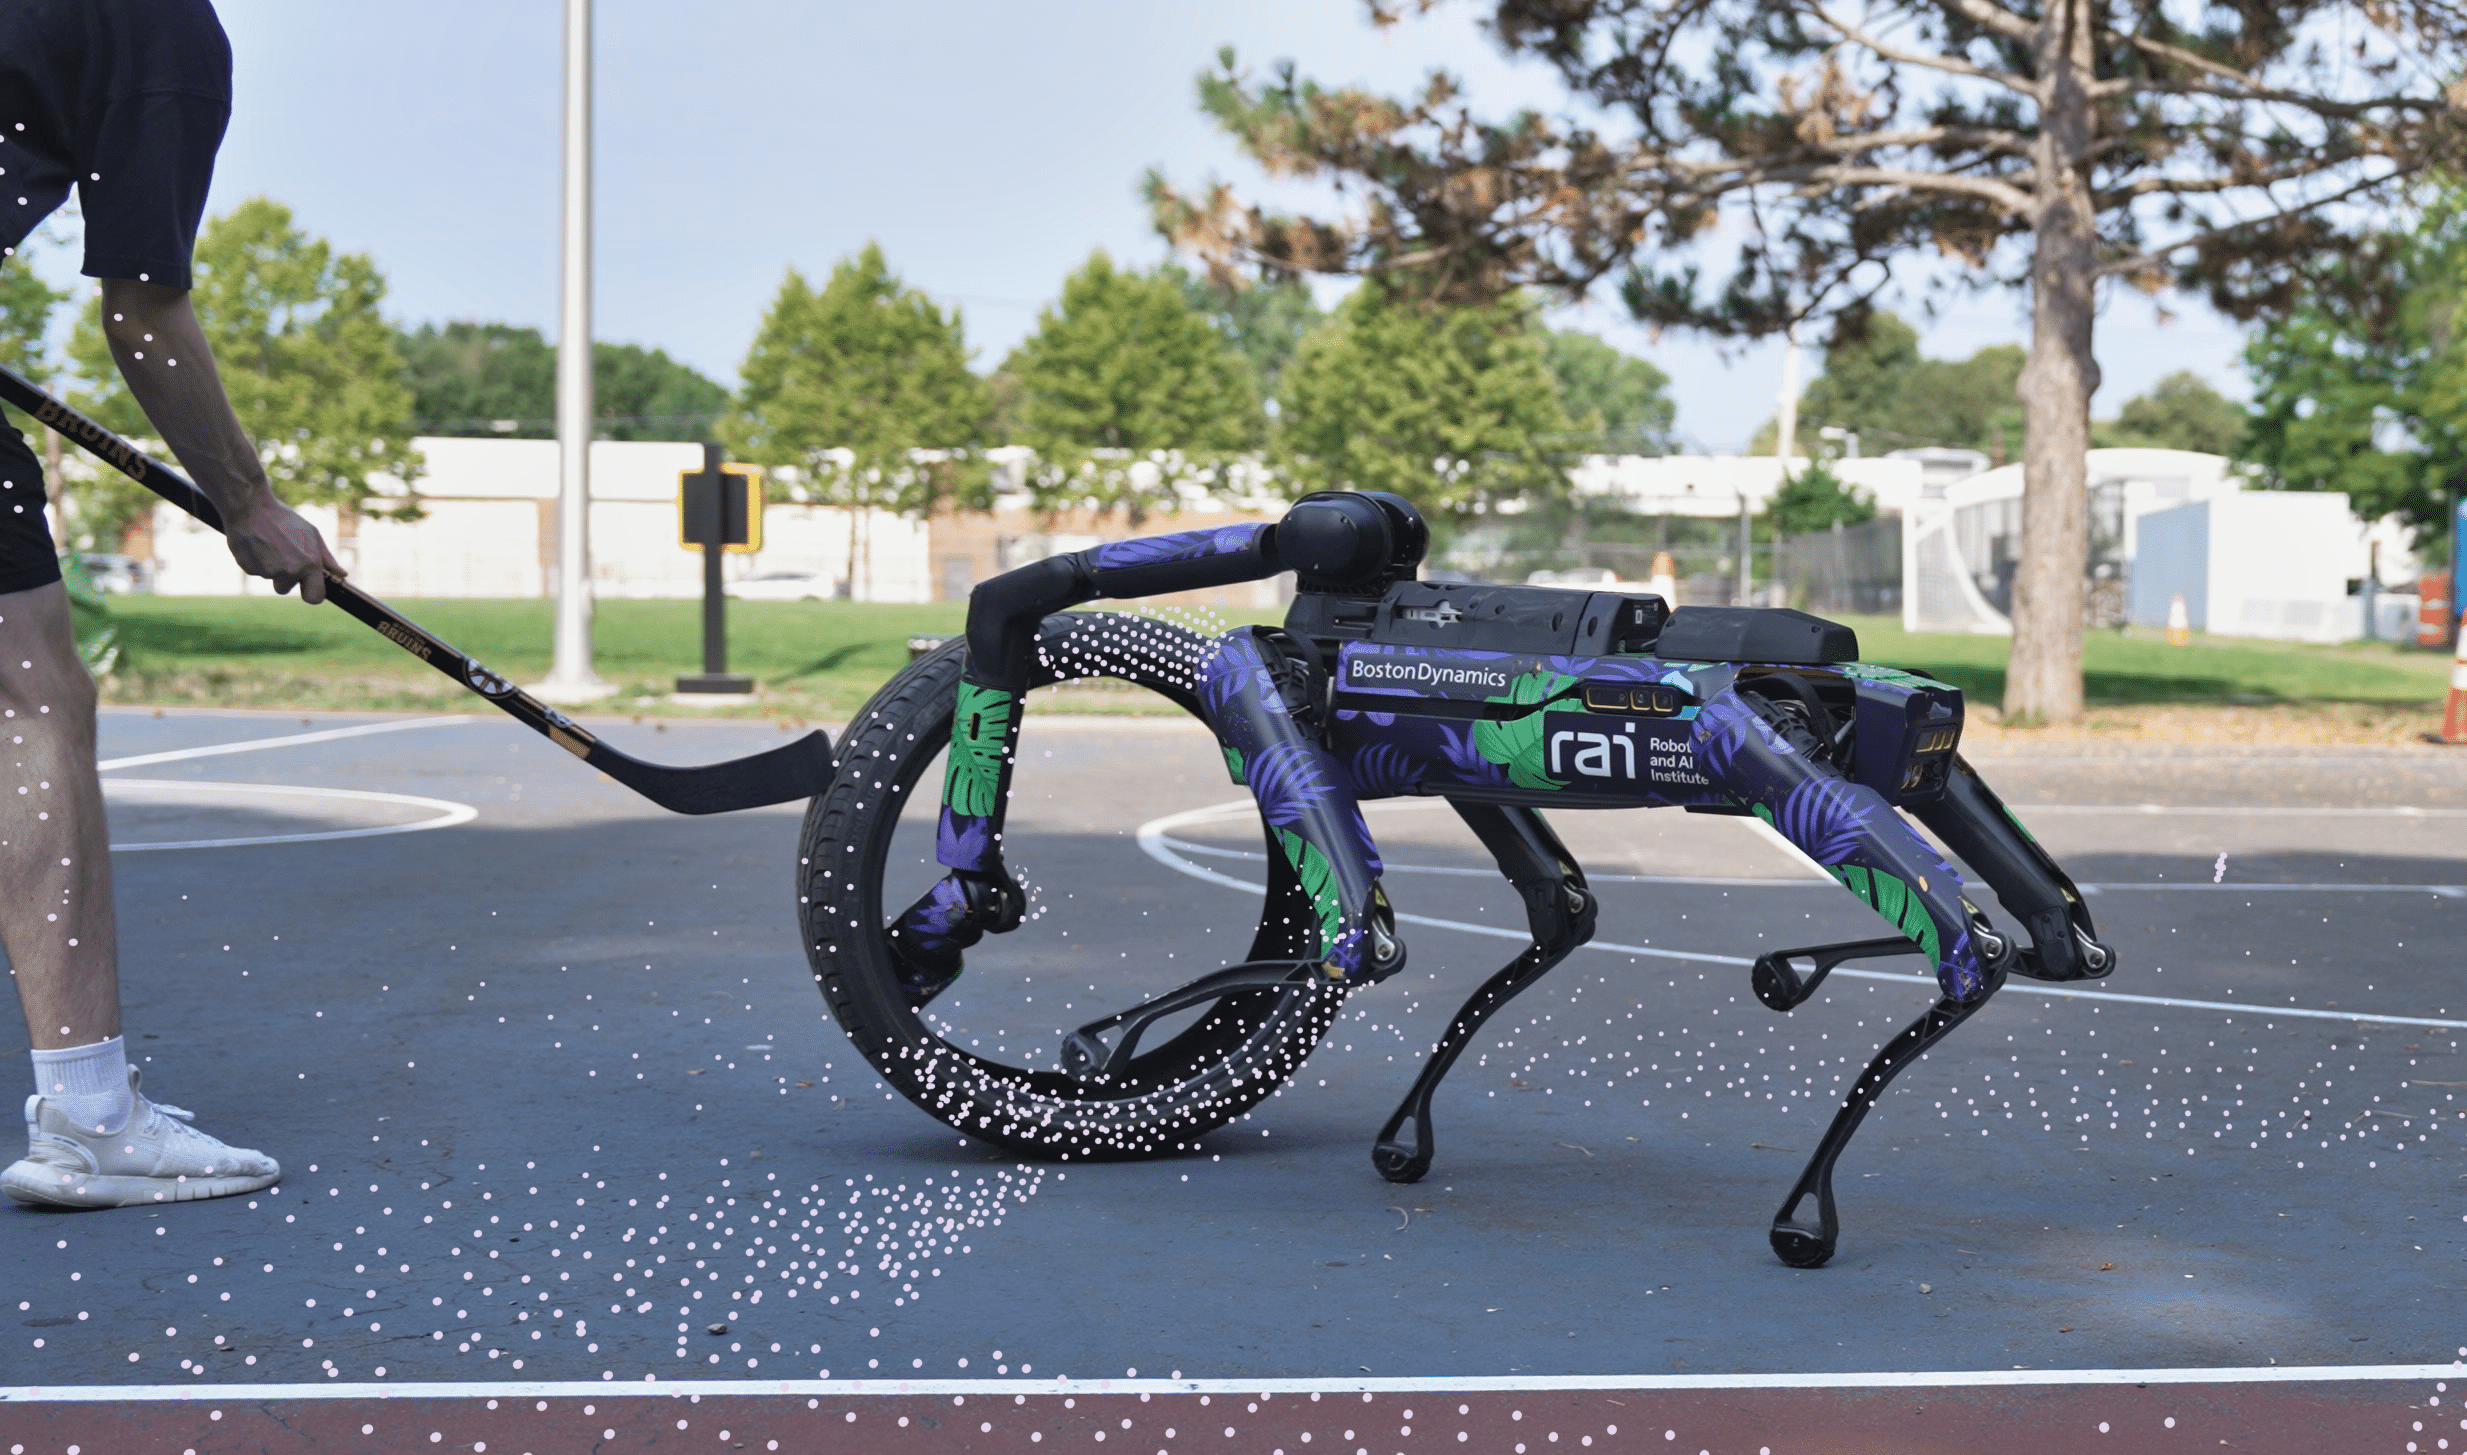
Perceptive Dynamic Manipulation with Spot
By replacing external motion capture with onboard depth-camera perception and local policy evaluation, we can achieved full autonomy and untethered outdoor execution to perceive, locate, and manipulate objects...


Help shape the future of robotics
We’re hiring researchers and engineers at all levels.