Featured Resources

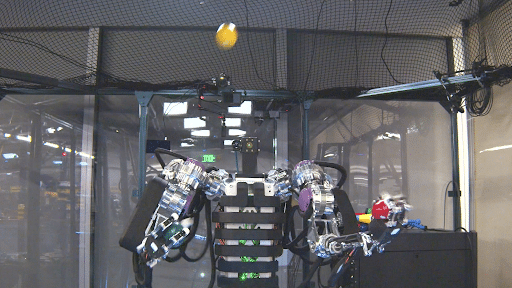
A New Benchmark in Robot Juggling

AthenaZero can juggle barehanded using onboard vision feedback. By using multi-fingered hands, it can transition seamlessly between a wide range of juggling patterns.

Video
Advanced Learning for Control
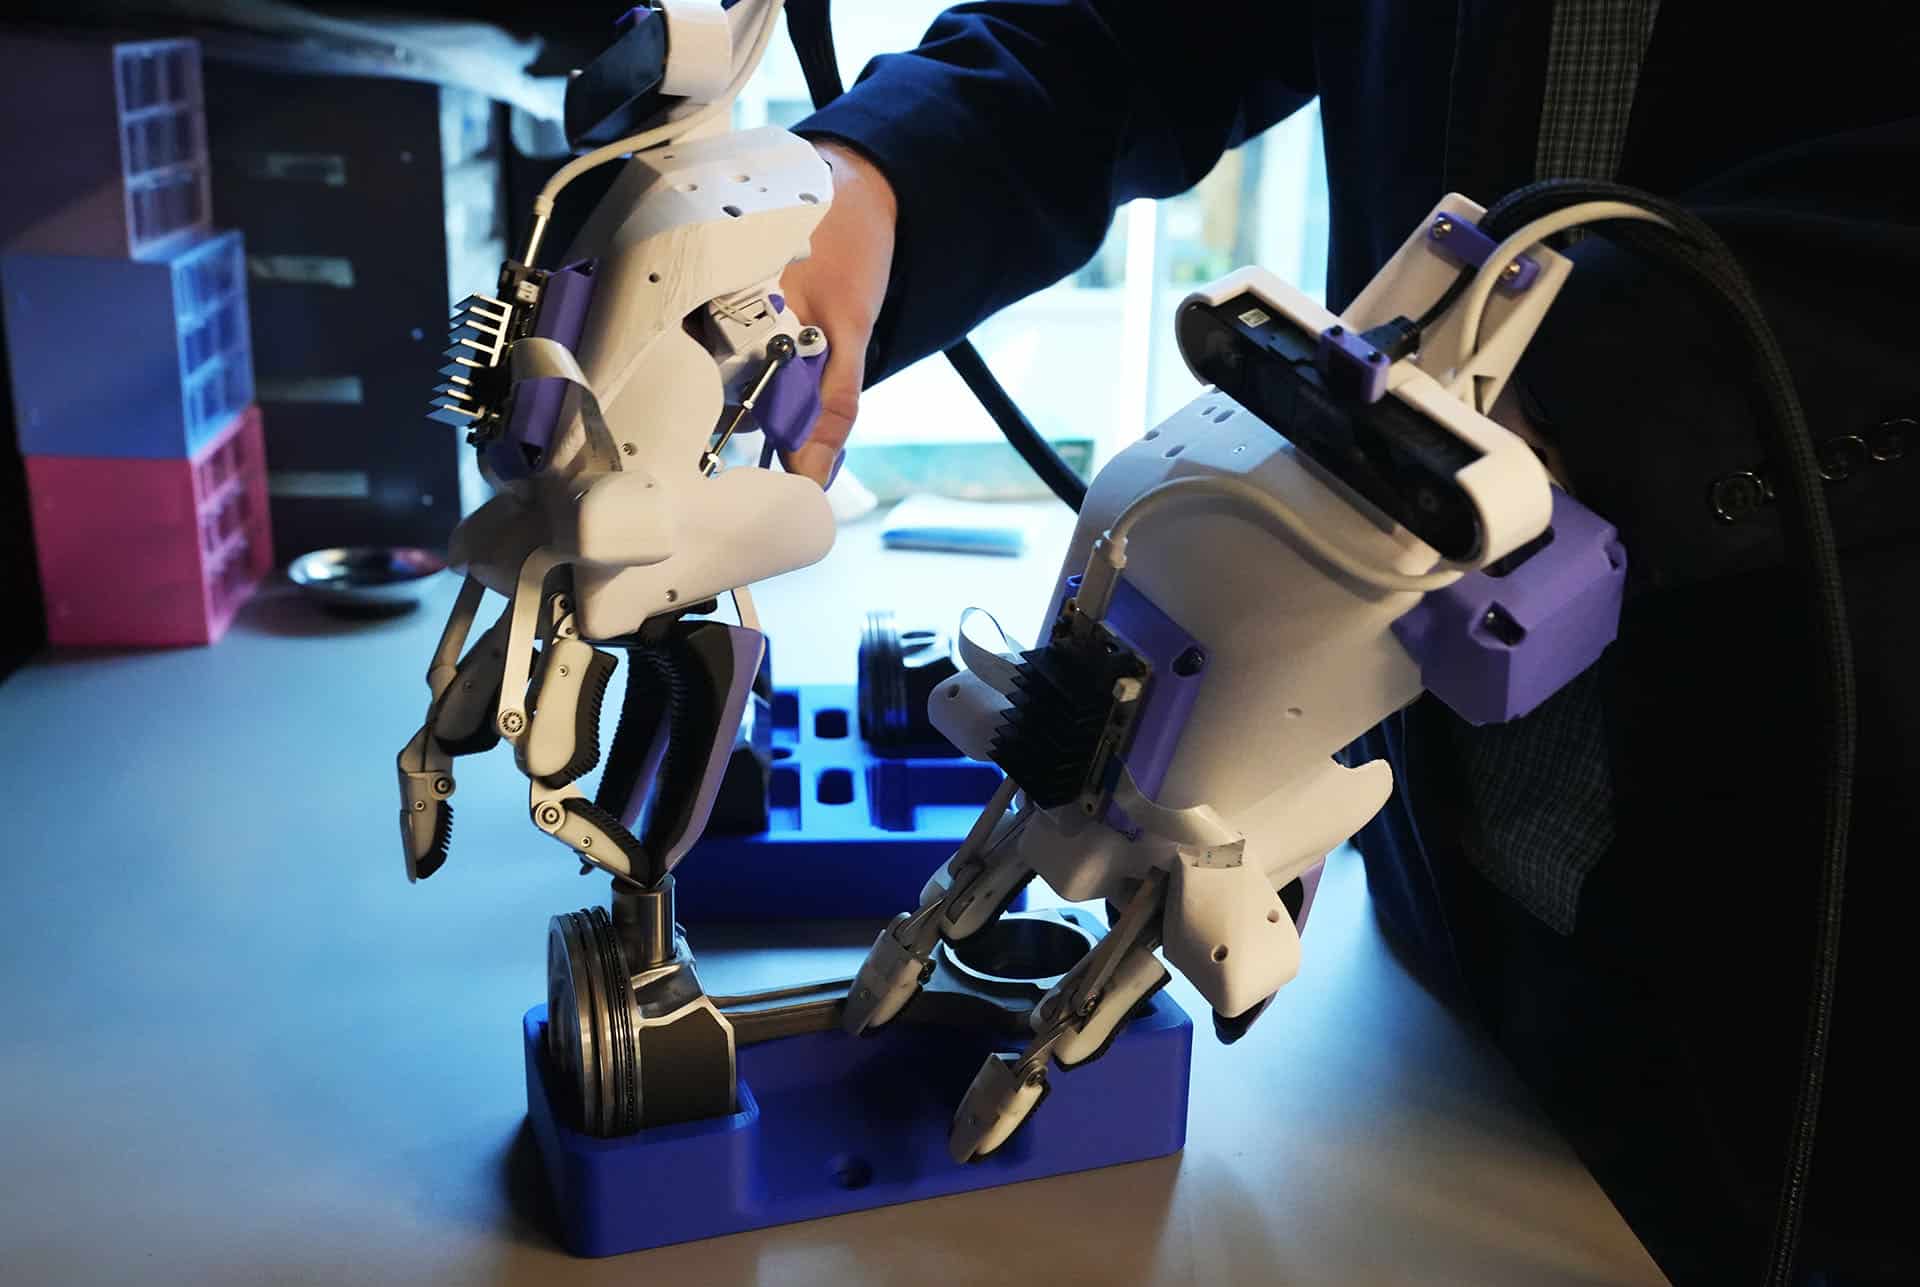
ICRA 2026 Publication Round Up

We’ll be presenting robotic research that includes contact-rich bimanual manipulation and policy learning, an open source package for sample-based Model Predictive Control (MPC), how to...

Blog
Advanced Learning for Control

Blogs

IROS 2026 Publication Round-Up

Research teams at the RAI Institute had several papers accepted to IROS 2026, covering topics from closed- loop visuomotor policies and frameworks for self-supervised learning on outdoor LiDAR...

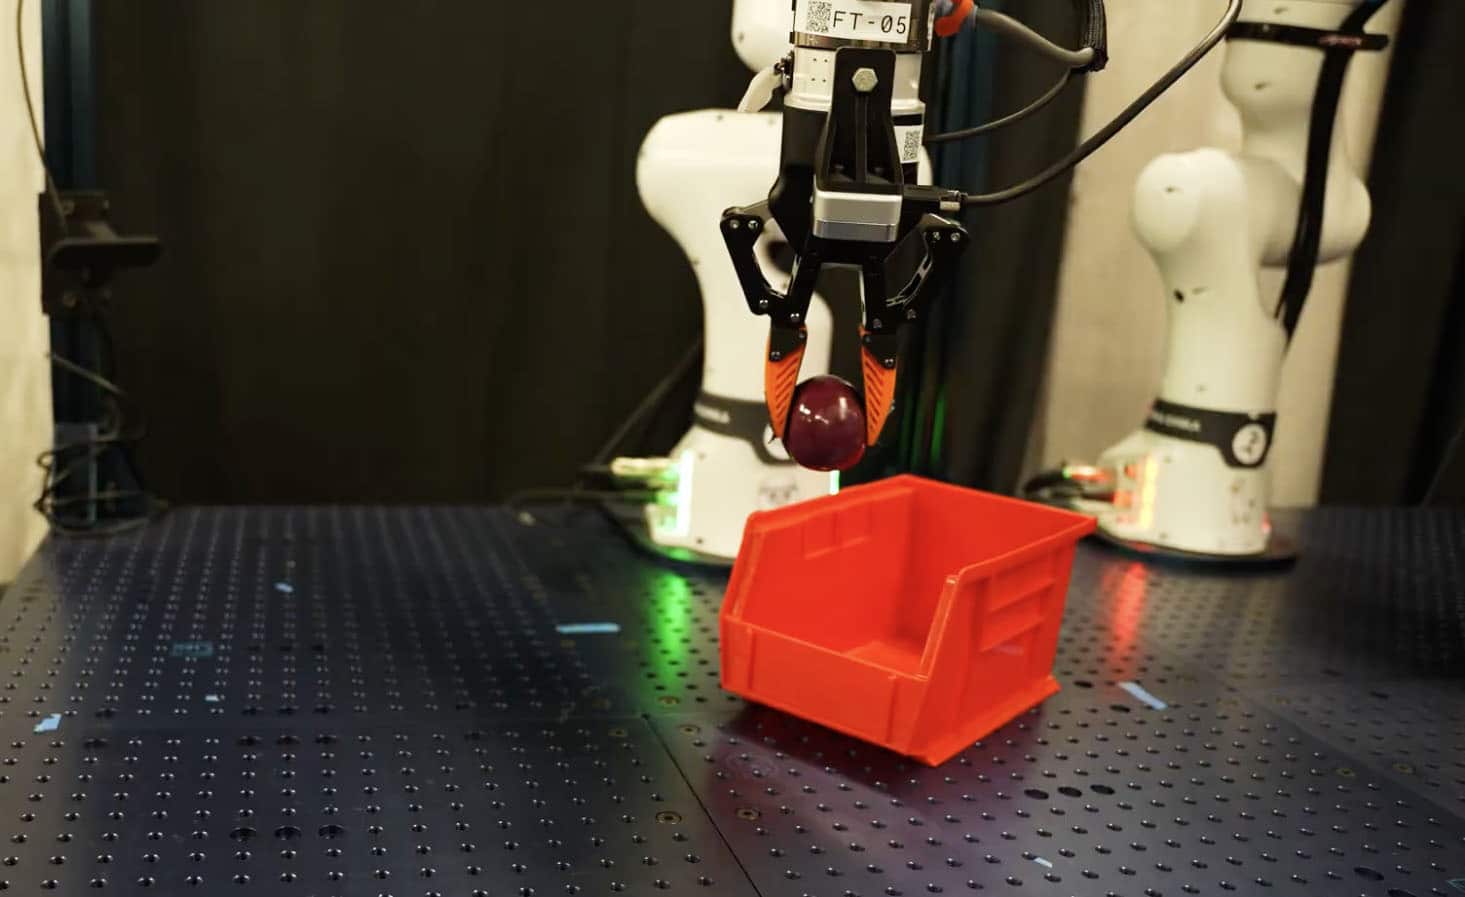
Q2RL: Reinforcement Learning to Improve Beyond Behavior Cloning

Presented at RSS 2026, Q2RL (Q-Estimation and Q-Gating from Behavior Cloning for Reinforcement Learning) is a method that avoids catastrophic forgetting when transitioning from offline behavior cloning to...

Videos

r

A New Benchmark in Robot Juggling

AthenaZero can juggle barehanded using onboard vision feedback. By using multi-fingered hands, it can transition seamlessly between a wide range of juggling patterns.

Papers