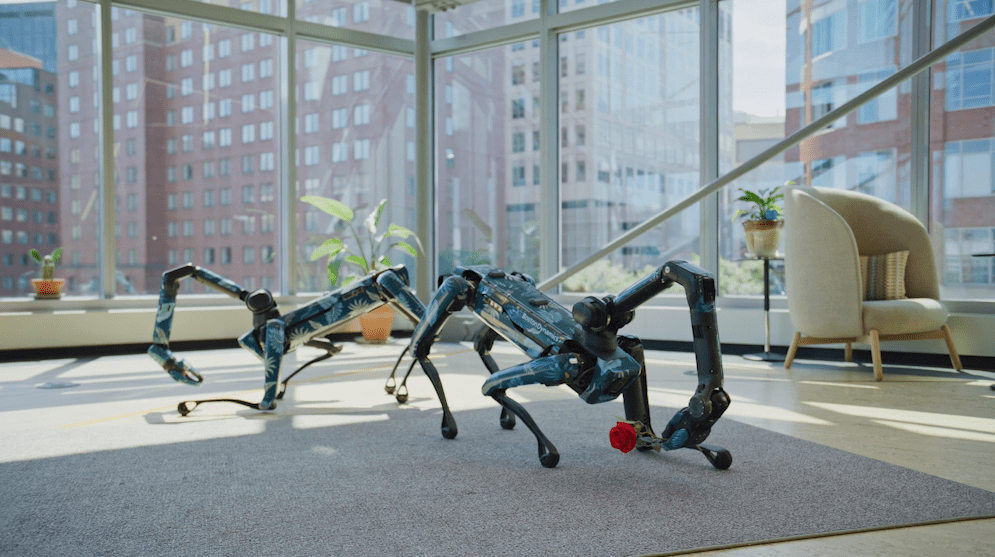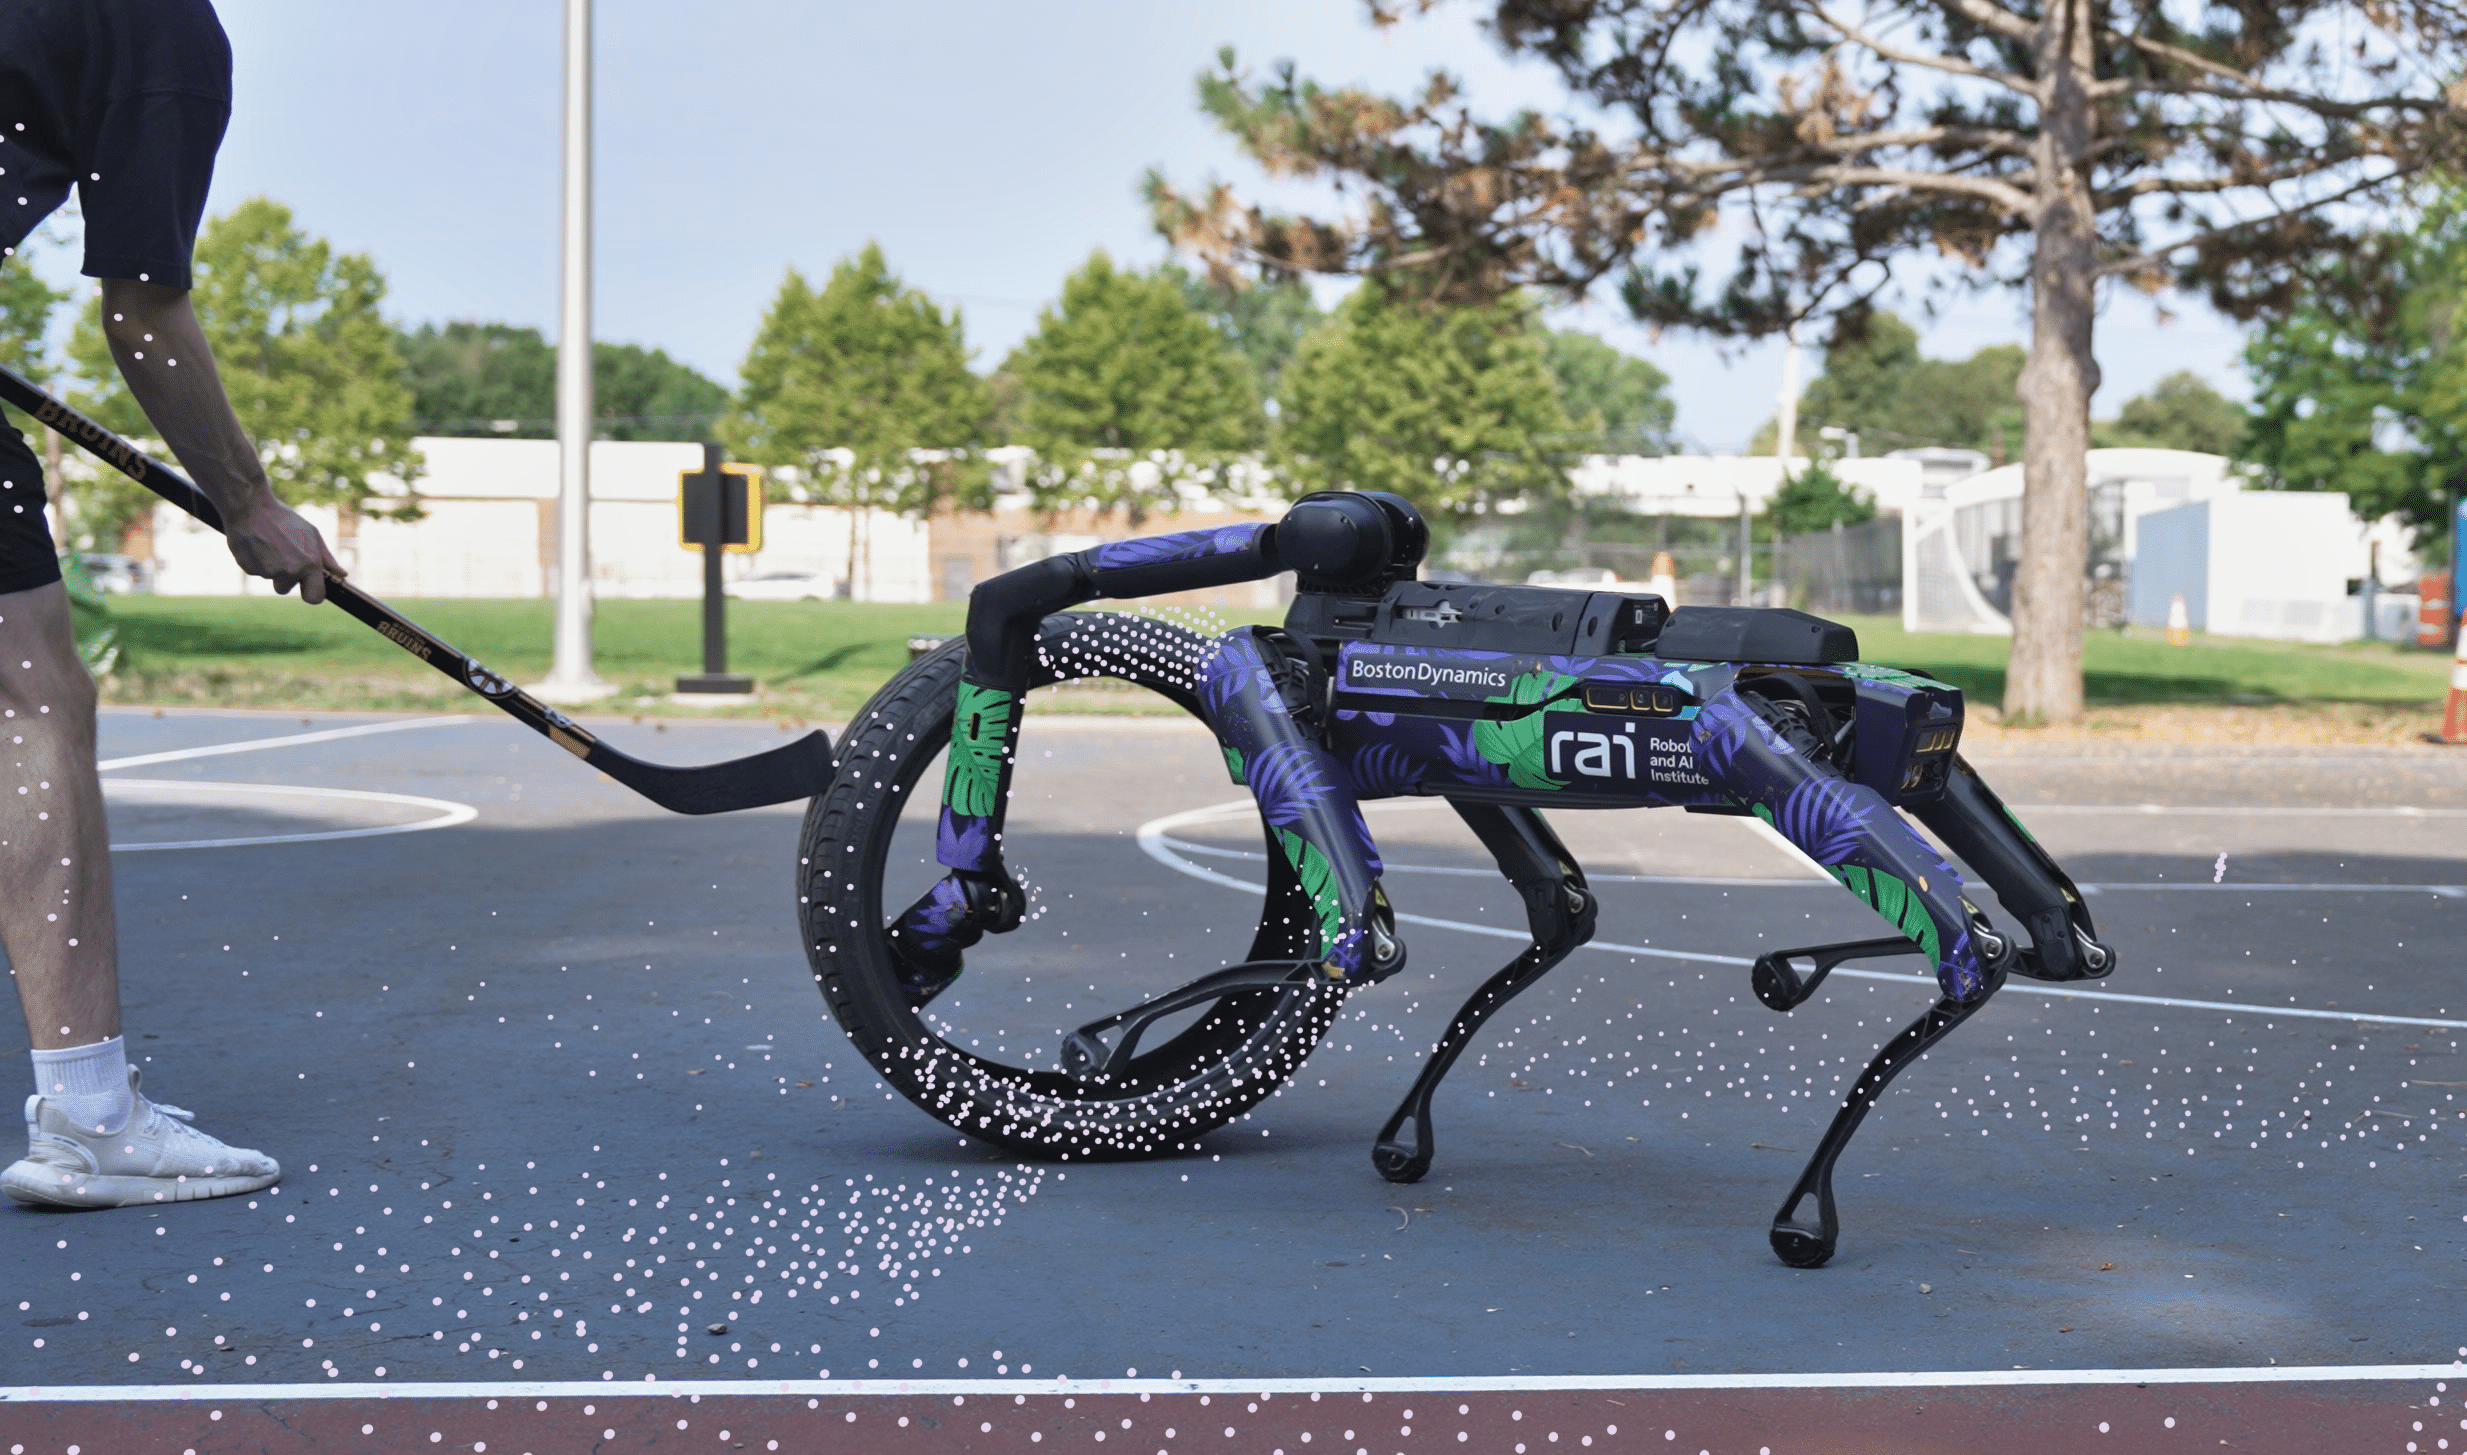
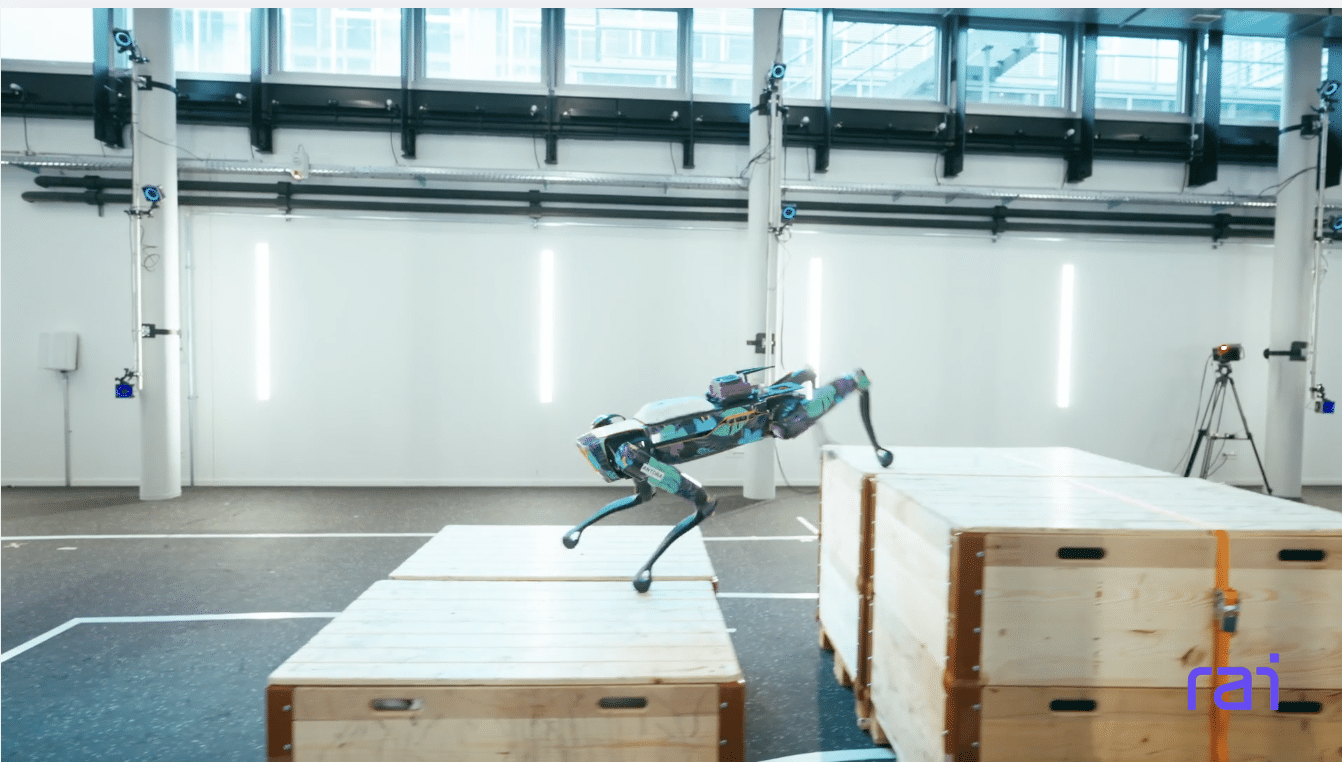
Spot performs dynamic manipulation outside the lab using onboard depth cameras and a computer.
Whole-Body Manipulation Outside the Lab
Spot performs dynamic manipulation outside the lab using onboard depth cameras and a computer.
Exploy, an open-source library that packages environment logic and neural network policies into a single, self-contained computational graph, was created for rapid iteration and deployment...
Research teams at the RAI Institute had several papers accepted to IROS 2026, covering topics from closed- loop visuomotor policies and frameworks for self-supervised learning...
Research teams at the RAI Institute had several papers and workshops accepted for CoRL 2026, covering topics such as handheld data collection, loco-manipulation, robot mapping and perception, sim-to-real...
Spot performs dynamic manipulation outside the lab using onboard depth cameras and a computer.
Exploy, an open-source library that packages environment logic and neural network policies into a single, self-contained computational graph, was created for rapid iteration and deployment onto physical robotic...
By replacing external motion capture with onboard depth-camera perception and local policy evaluation, we can achieved full autonomy and untethered outdoor execution to perceive, locate,...
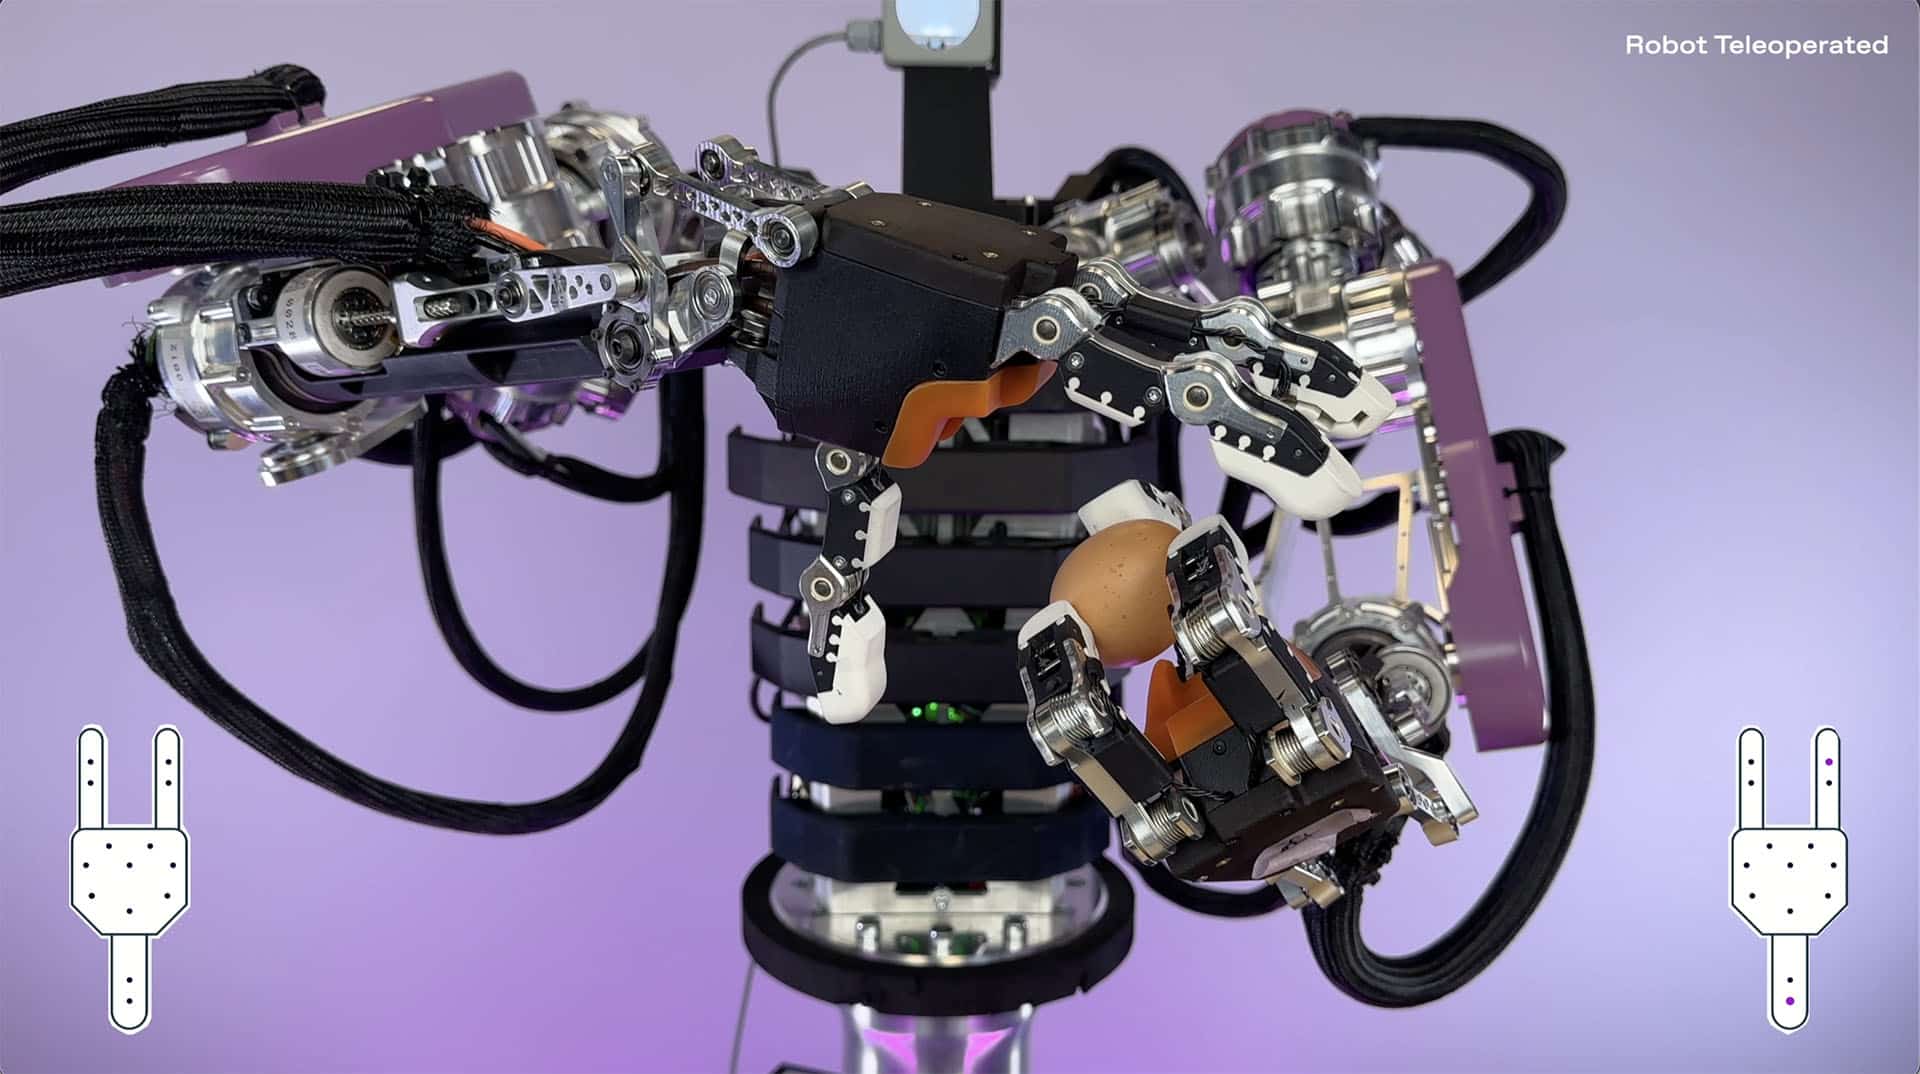
To perform tasks that require forceful manipulation and delicacy with a single robot design requires not only a powerful robot but also smart control. Providing...
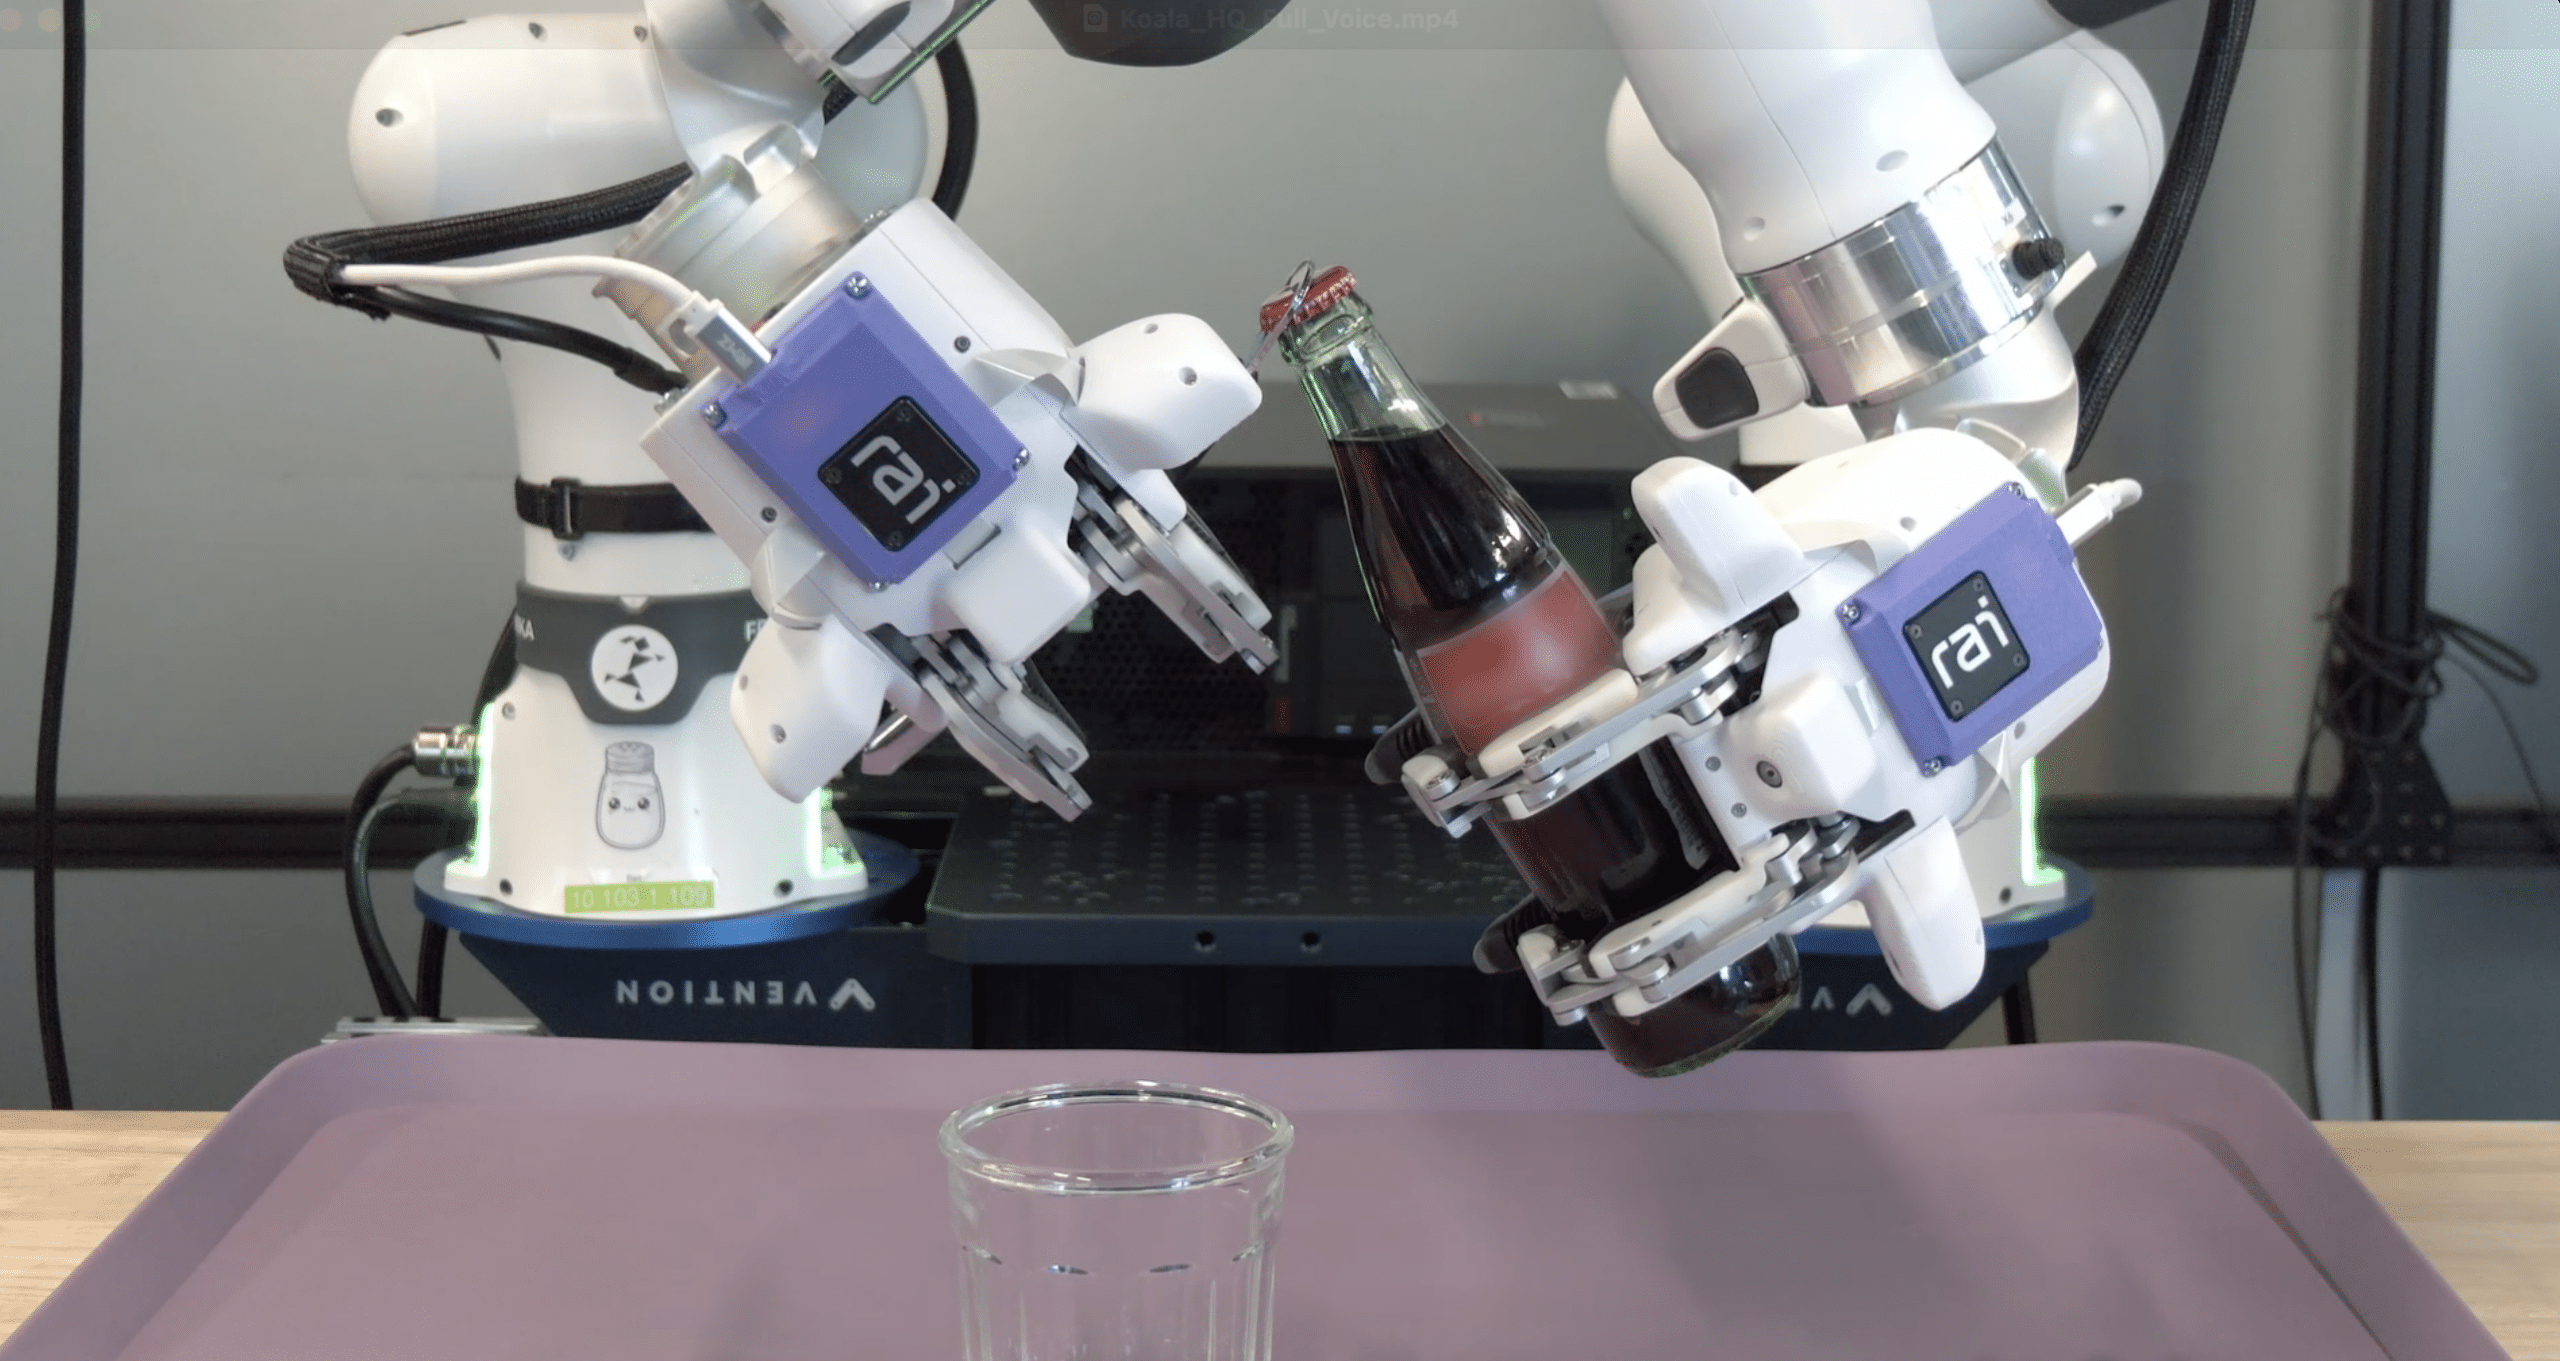
Get a closer look at the Koala gripper! The co-designed system pairs a handheld data collector and a corresponding robotic gripper, allowing a single, unassisted...
We present RoMo-GS, an online 3DGS system. Instead of averaging N discrete sub-frames as in prior motion blur-aware 3DGS, we analytically integrate each projected Gaussian...
Integrating locomotion and manipulation is essential for robot autonomy, but scaling standard Reinforcement Learning (RL) to complex tasks is severely bottlenecked by the slow, manual...
We train the low-level (LL) controller itself as an object-aware motion prior: a single policy trained via motion imitation on retargeted motion-capture (MoCap) references that...
We introduce NovaPlan, a hierarchical framework that enables robust, zero-shot long-horizon manipulation by systematically proposing, verifying, and repairing visual plans.