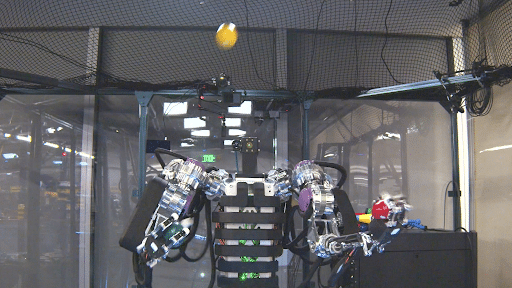
The AthenaZero has two, three-fingered robot hands driven by tendons. This design allows the fingers to interdigitate to hold objects of different sizes, such as an egg or a hammer. Each finger is powered by a motor located in the robot’s torso to keep the hand light, transmitting force through flexible cables. This hand is both fast (closing in about 80 milliseconds) and strong. With the addition of highly accurate barometric pressure sensors, it can also be gentle. The fingertips and palm are made of flexible materials that contain the sensors. Each palm has eight sensors, with an additional three in each fingertip. These can detect light touches and indicate where the contact occurred. Local compute for these sensors is housed in the back of the hand to reduce latency. To learn more about the AthenaZero’s tactile sensing and other dynamic manipulation capabilities, read the paper on Science Robotics: https://www.science.org/doi/10.1126/scirobotics.aee1868
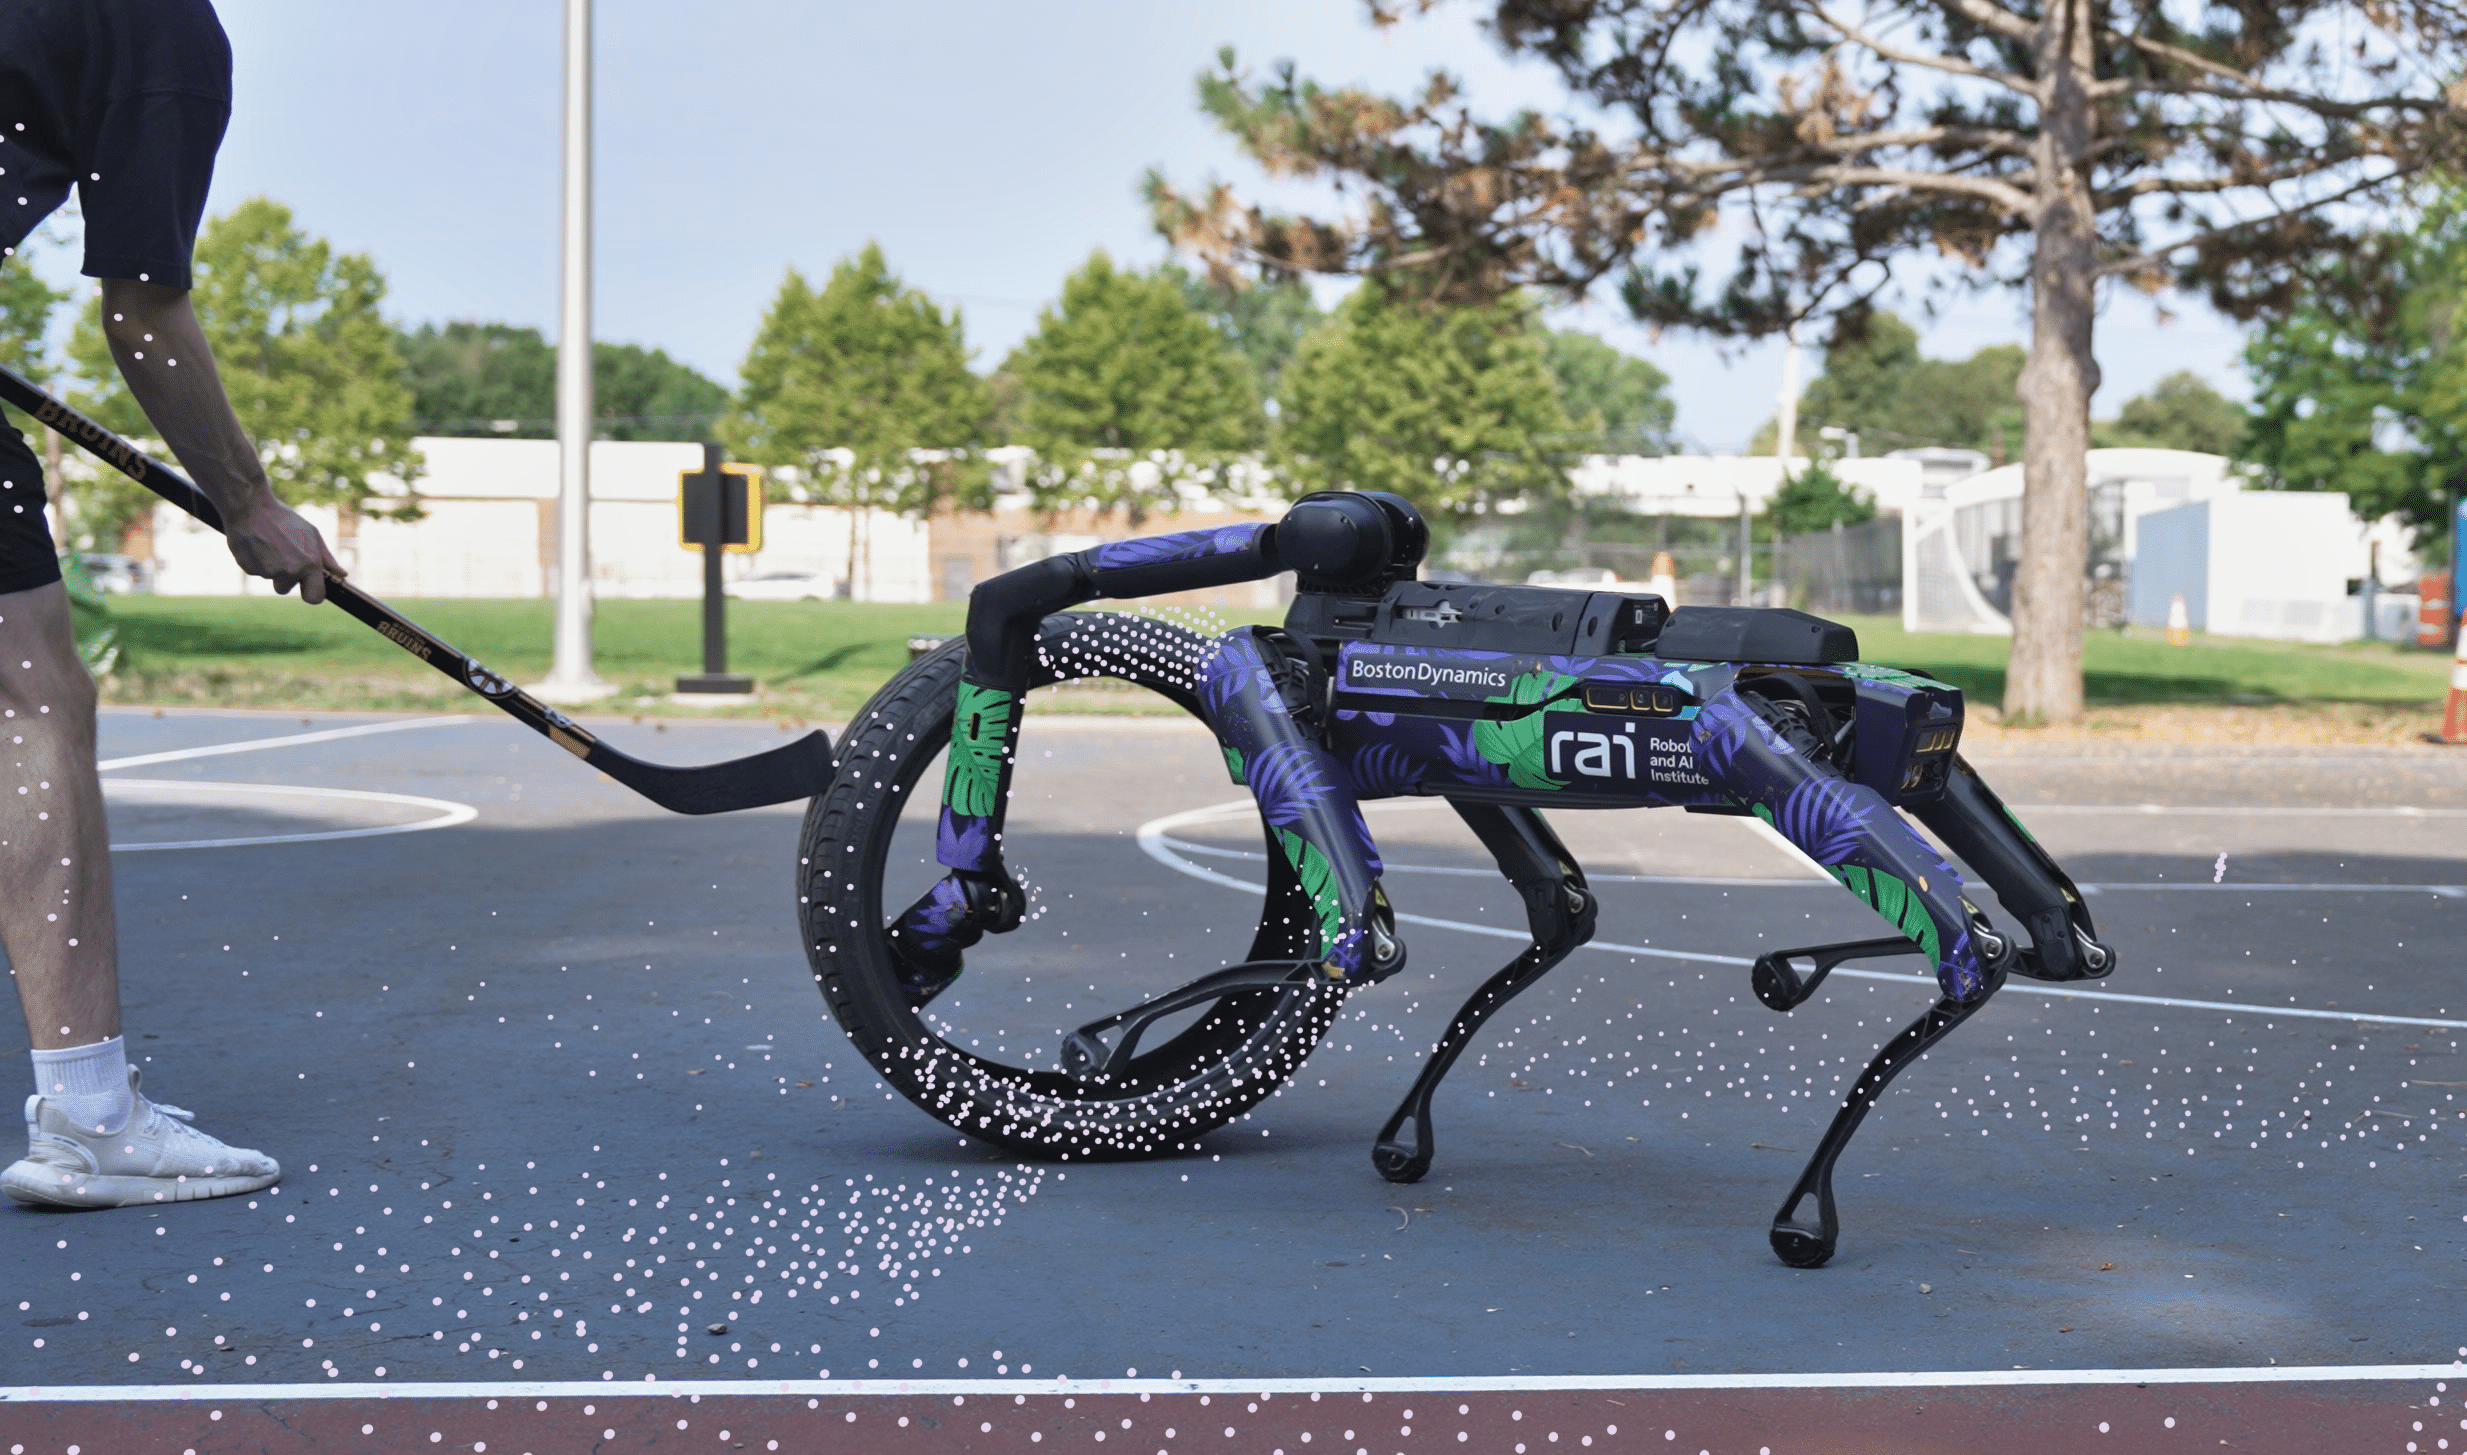
Perceptive Dynamic Manipulation with Spot
By replacing external motion capture with onboard depth-camera perception and local policy evaluation, we can achieved full autonomy and untethered outdoor execution to perceive, locate, and manipulate objects...
Share